On Device Machine Learning For Forest Fire Smoke Visual Density Quantification Via Nano Camera
An end-to-end AI-powered drone system for early forest fire detection and autonomous response
Ho Chi Minh City University of Technology and Engineering (HCMUTE) - Graduation Thesis 2025
Forest fires cause devastating environmental damage, loss of wildlife habitats, and threaten human communities. Traditional fire detection methods rely on:
Challenge : How can we detect forest fires in real-time with precise geolocation and immediate alerts to enable rapid response?
The complete drone system with all components integrated and ready for field testing.
The Web GCS displays real-time detection status with live video feed and telemetry data.
When fire is confirmed (Stage 2), an urgent alert is sent with higher priority notification.
The Web GCS shows fire confirmation with captured snapshots and detection history.
Returns current detection status with smoke/fire confidence, bounding box count, and timestamps.
This project is distributed under the MIT License. See LICENSE file for more information.
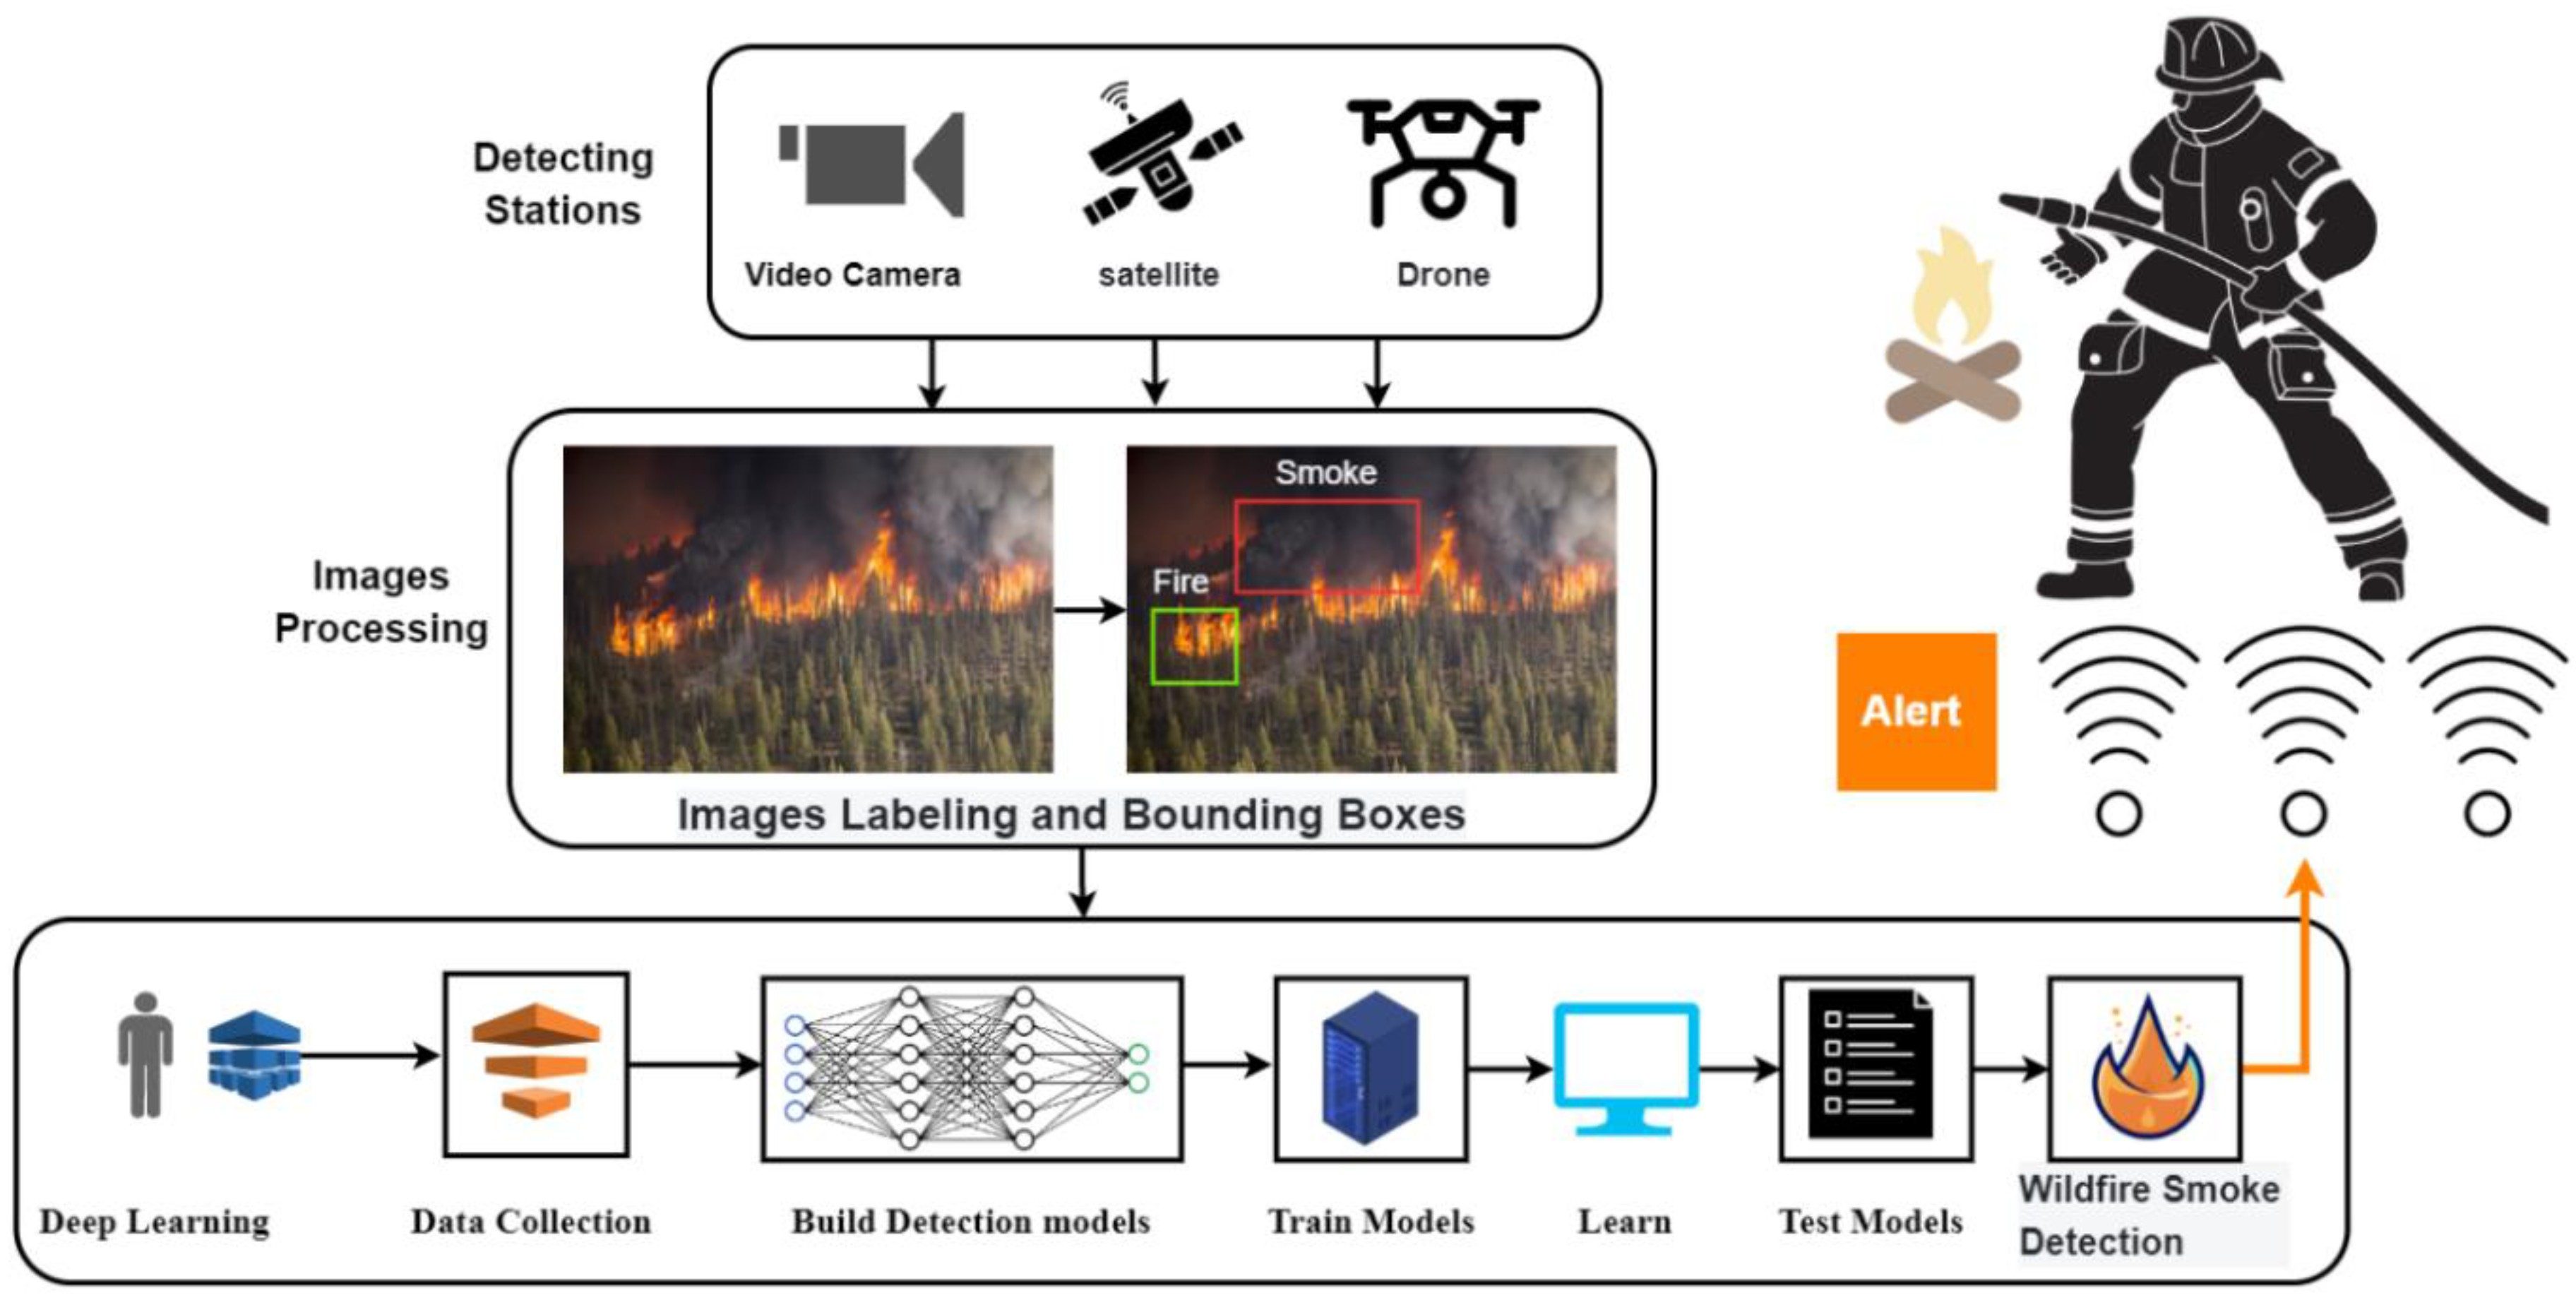
This project develops an automated forest fire surveillance system using UAV drones, combining Artificial Intelligence (AI) with the YOLOv11 model optimized by TensorRT to run on NVIDIA Jetson Nano.
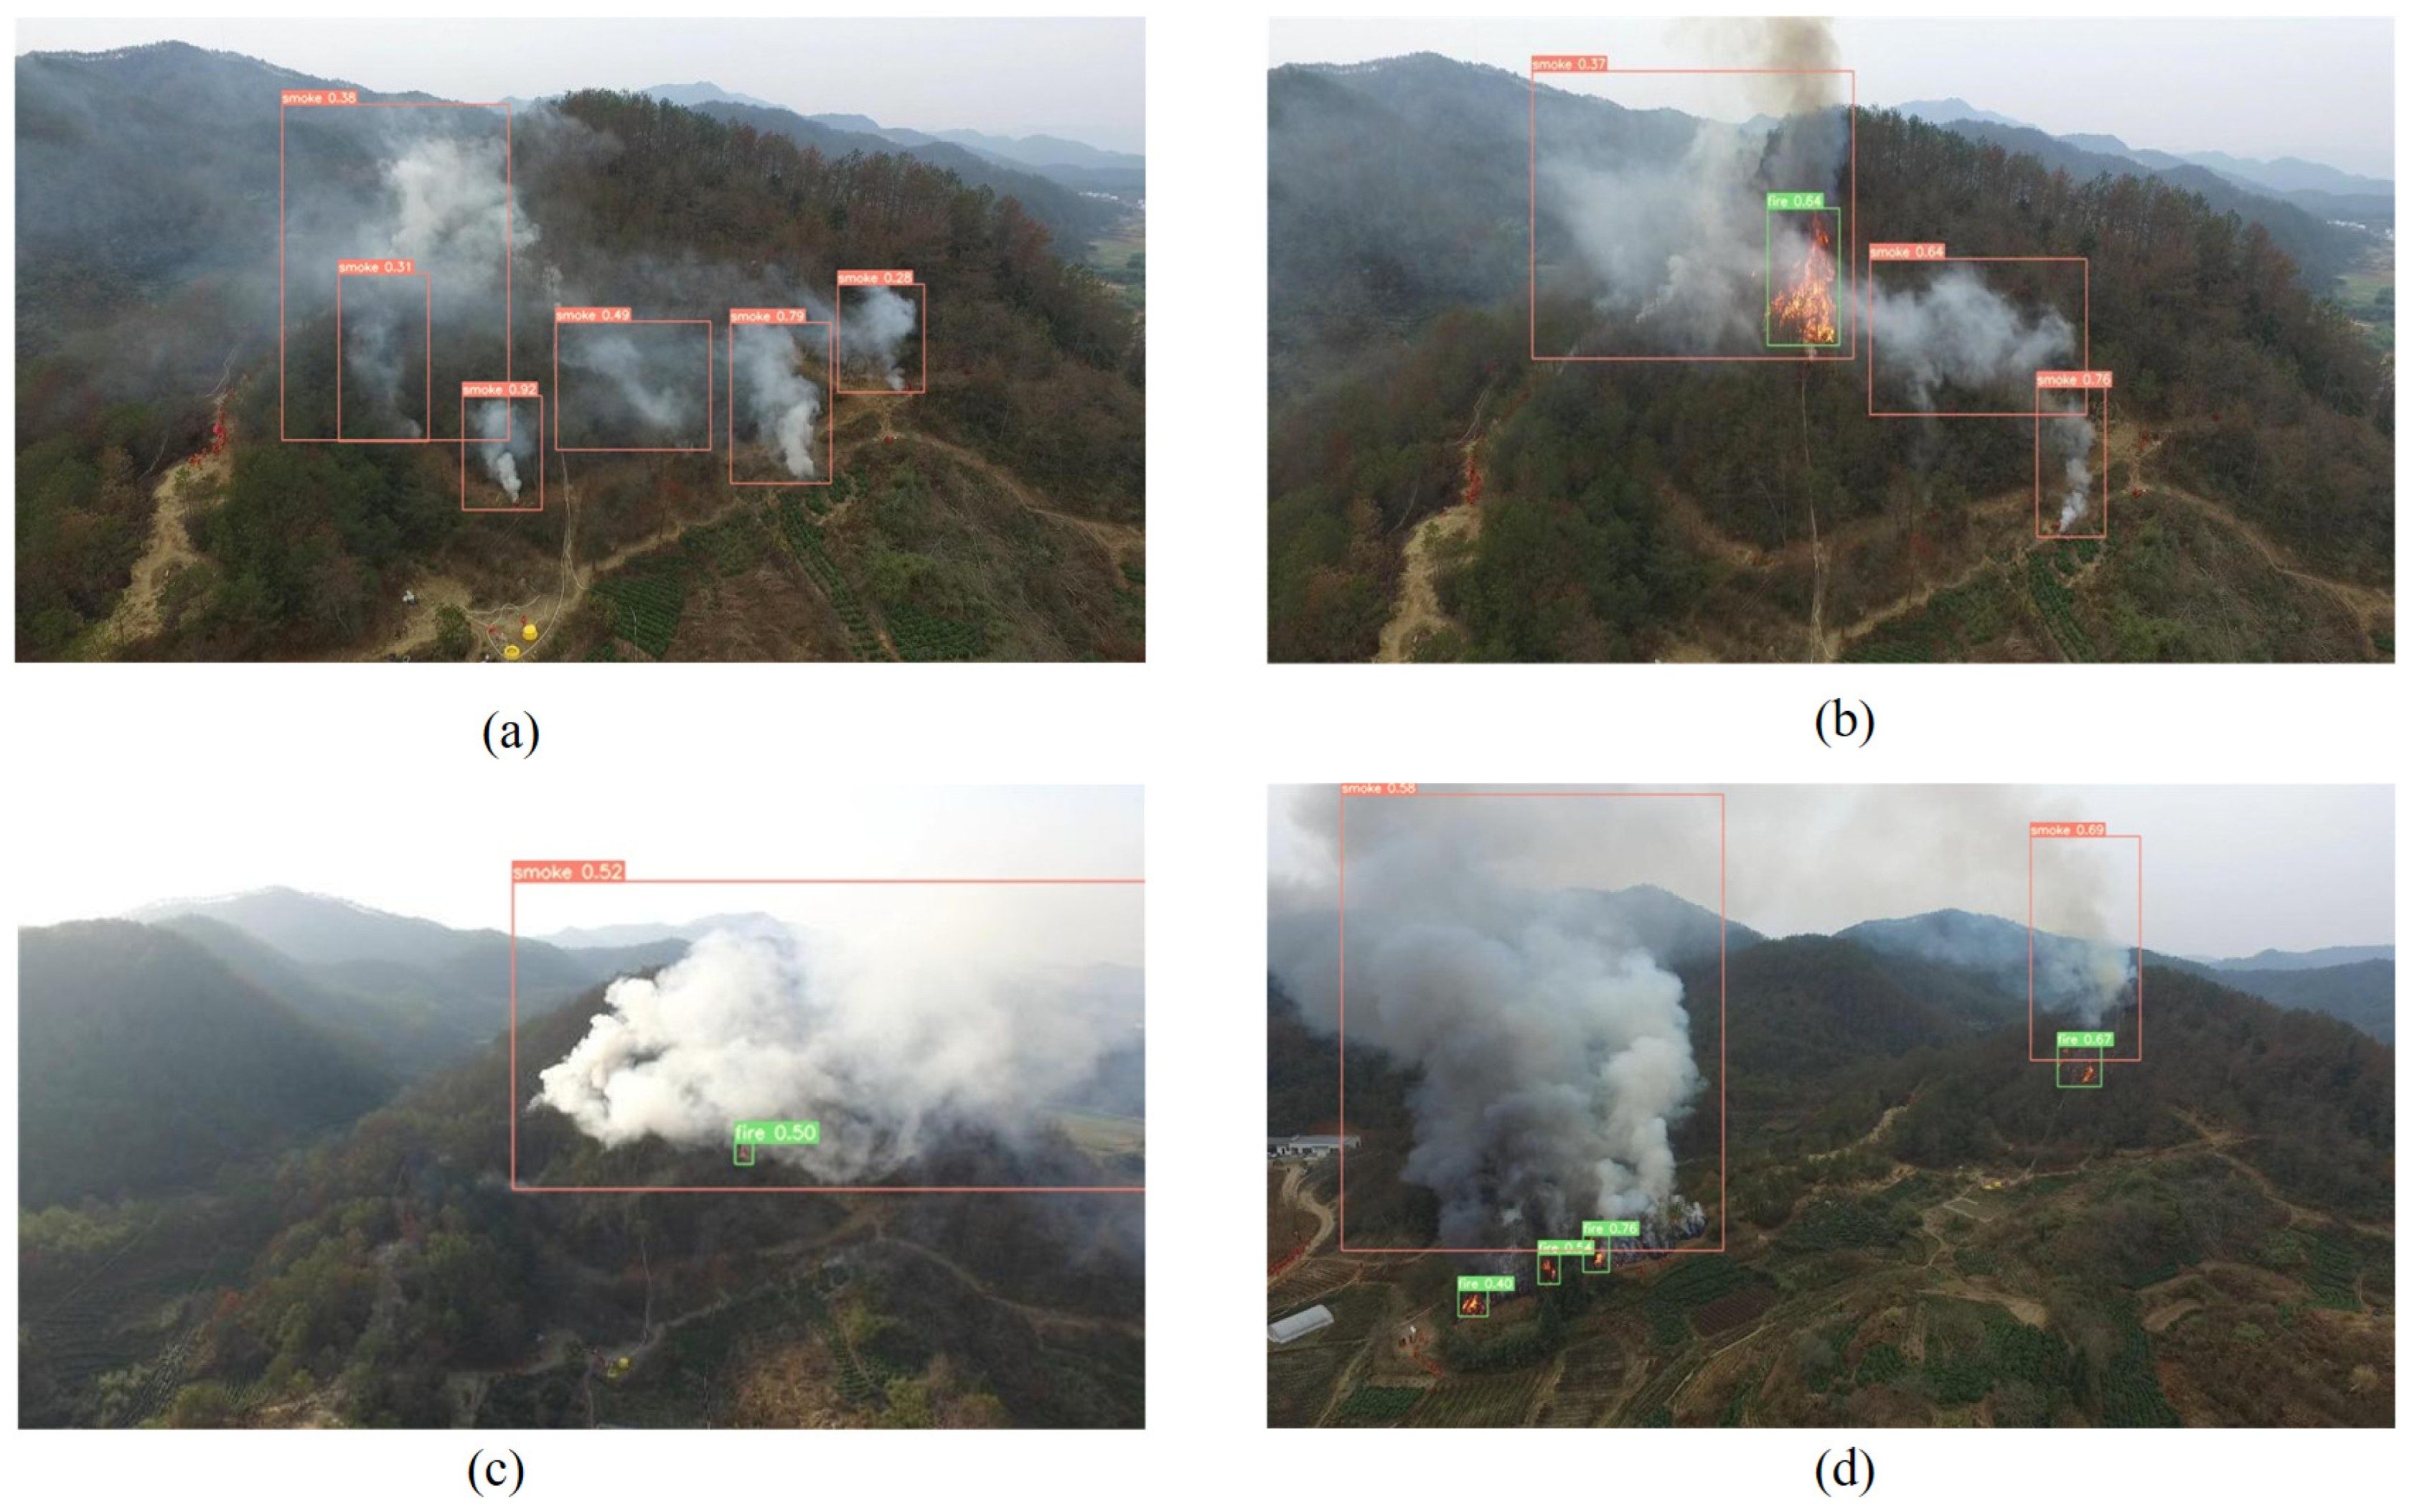
A real-time Fire and Smoke Detection System built using YOLOv8s , OpenCV , and PyTorch . The system detects fire and smoke from a live webcam or CCTV video feed and provides instant visual and voice alerts to improve early fire detection and safety monitoring.
Traditional fire detection systems such as smoke sensors and heat detectors often suffer from delayed detection, false alarms, and limited situational awareness. This project leverages Computer Vision and Deep Learning to perform real-time fire and smoke detection from live video streams.
The model was trained on a Fire and Smoke Detection dataset containing annotated images in YOLO format.
Hardware Schematics & Pinout Diagrams
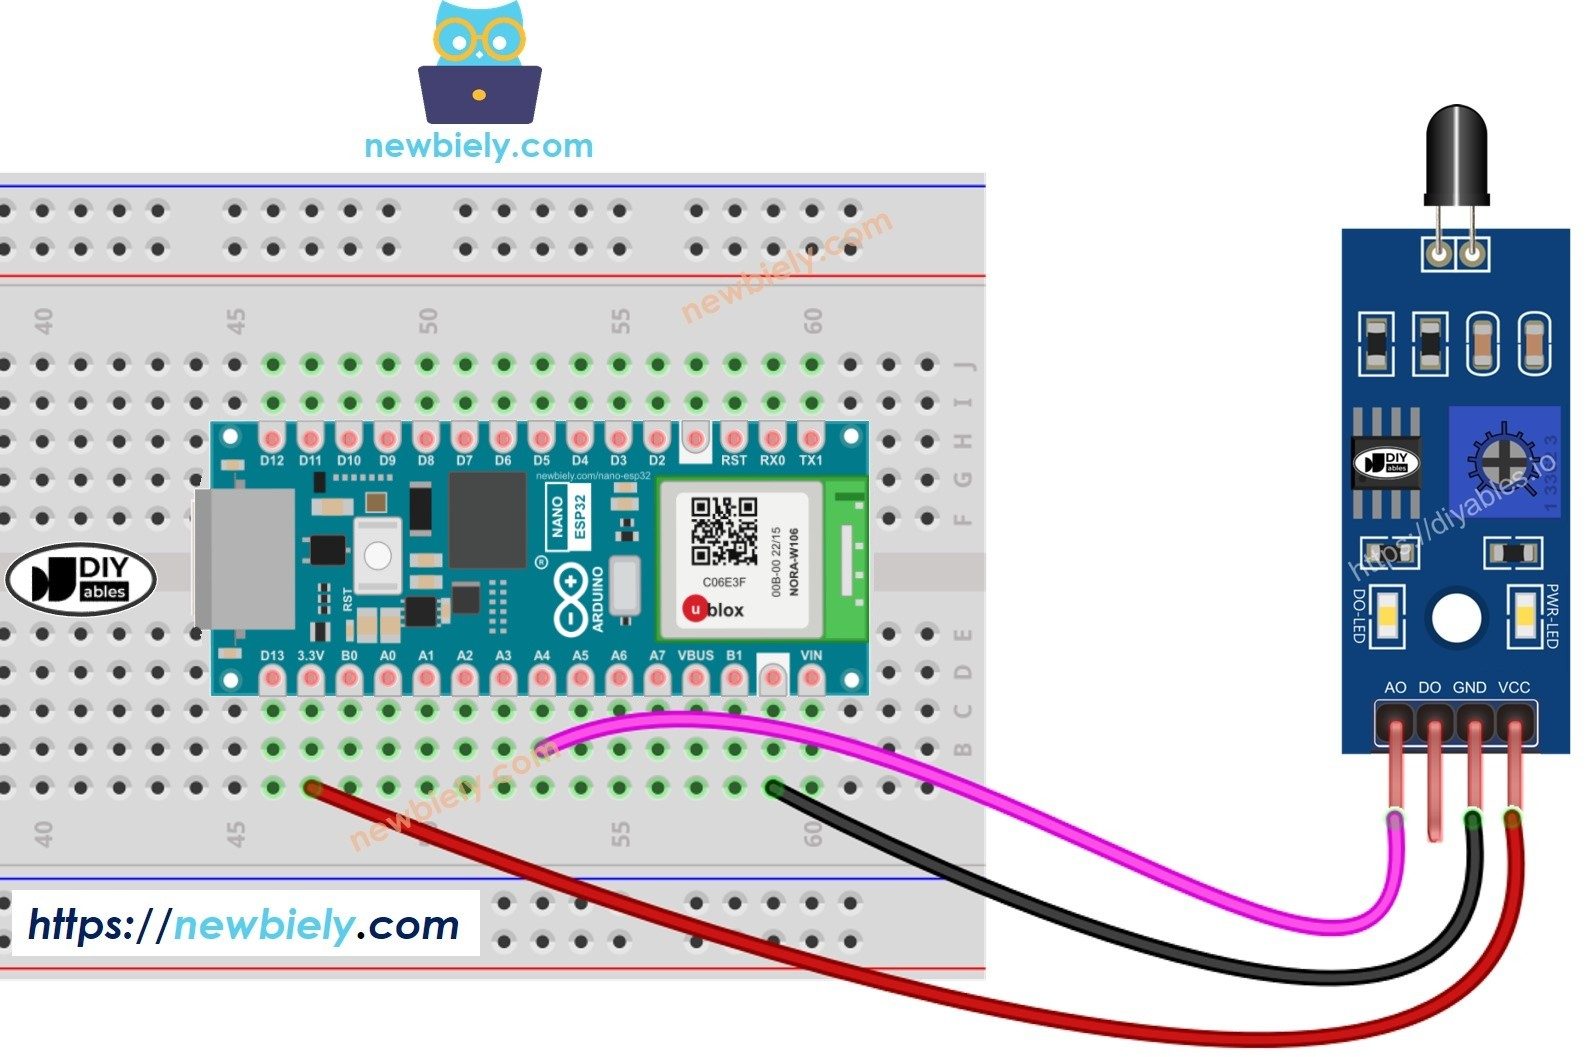
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for On Device Machine Learning For Forest Fire Smoke Visual Density Quantification Via Nano Camera... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |