Multi Axis Cnc Milling Spindle Load Monitor With Automated Feed Rate Throttle Via Arduino
Proper spindle speed control is necessary to get good CNC milling results. If your spindle speed is inconsistent, your speed and feed calculations will be wrong. That will lead to poor finishes and even broken end mills (and ruined parts) in extreme cases. But cheap CNC mills and routers often have insufficient spindle speed controllers. That’s why Joekutz’s Workbench built an improved spindle speed controller for his generic CNC 3040.
This DIY spindle speed controller has two major improvements: more precise adjustment and closed-loop feedback.
The original controller just had an imprecise potentiometer knob and dot markings, making it impossible to set to a specific speed. The new version lets the user set the spindle to a desired speed with a digital readout.
It also has closed-loop feedback, so it can adjust power to the motor as necessary to maintain the set speed under load. Without that, even a light load could slow down the spindle and throw off the speed/feed balance.
Joekutz’s Workbench achieved this using an Arduino UNO Rev3 board. It reads input from a rotary encoder to set the motor speed, then shows that speed on a seven-segment display. It controls the motor speed via PWM through a DIY optical isolator, a transistor, and a MOSFET. At the same time, it receives feedback on the real-world motor speed using an LED and photoresistor. That measures the reflectivity of the spinning spindle, which has a piece of aluminum foil tape in one area to increase reflectivity. That lets the Arduino detect a revolution of the motor and calculate the RPM.
The CNC mill uses an Arduino Mega 2560 with GRBL for controlling the axes’ stepper motors. The Arduino Uno spindle controller can receive g-code speed commands from that, or the user can set the speed using the rotary encoder dial.
Master multi-axis motor control with our complete Arduino stepper driver shield wiring and code guide. Includes CNC Shield V3 pinouts and AccelStepper examples.
Building high-precision desktop CNCs, camera sliders, or multi-axis robotic arms requires precise motor control that a standard microcontroller cannot provide natively. An Arduino stepper driver shield bridges this gap, translating low-voltage logic signals into high-current phase switching for bipolar stepper motors. In 2026, the DIY automation space has largely standardized around two distinct architectures: the high-voltage, microstepping-focused CNC Shield V3 (paired with DRV8825 or A4988 drivers), and the I2C-based Adafruit Motor Shield V2. While both are excellent, they serve fundamentally different use cases.
This comprehensive wiring and code guide focuses primarily on the CNC Shield V3 with DRV8825 drivers , as it remains the undisputed champion for high-torque, high-resolution multi-axis projects. We will cover exact pinouts, critical Vref tuning procedures, and advanced multi-axis code implementation using the AccelStepper library.
Before cutting wires, it is vital to select the correct shield for your project's torque and resolution requirements. Below is a 2026 hardware comparison to help you decide.
Wiring an Arduino stepper driver shield incorrectly is the fastest way to permanently destroy your microcontroller or driver ICs. Follow this exact sequence to ensure hardware safety.
Bipolar stepper motors typically have four wires (e.g., NEMA 17 or NEMA 23). You must pair them correctly into Coil A and Coil B. Do not rely on wire color codes, as manufacturers frequently change them.
Insert Coil A into the 1A and 1B slots on the shield, and Coil B into the 2A and 2B slots. Reversing A and B will simply reverse the motor's logical direction, which can be fixed in software.
Microstepping divides a full step (usually 1.8° or 200 steps/rev) into smaller fractions, resulting in smoother motion and reduced resonance. The CNC Shield V3 uses three jumpers (M0, M1, M2) located directly beneath the DRV8825 socket. According to the Texas Instruments DRV8825 datasheet , the jumper configuration for 1/16th and 1/32nd microstepping is as follows:
Note: "In" means the jumper cap is placed over the two header pins; "Out" means the pins are left bare.
The most common failure mode for beginners is skipping the Vref (Reference Voltage) tuning, leading to overheated drivers and melted stepper coils. The DRV8825 current limit is dictated by the onboard potentiometer.
If you are using a standard NEMA 17 motor rated for 1.5A per phase, your target Vref is 0.75V .
The default Arduino Stepper.h library is blocking, meaning it halts the microcontroller while a motor moves. For an Arduino stepper driver shield controlling multiple axes simultaneously, you must use the AccelStepper library by Mike McCauley. It utilizes non-blocking algorithms, allowing the X and Y axes to accelerate, move, and decelerate concurrently.
Below is the foundational code for independent X and Y axis control using the standard Protoneer CNC Shield V3 pin mappings.
As detailed in the Protoneer CNC Shield documentation , the Enable pin (D8) is active LOW. Forgetting to pull D8 LOW in your setup function will result in the drivers remaining disabled, leaving the motors completely unpowered and unresponsive.
Even with perfect wiring, high-speed stepper applications introduce electrical noise and mechanical resonance. Here is how to solve the most common edge cases encountered in 2026 DIY builds.
Symptom: The motor randomly steps or vibrates when idle, or the Arduino resets unexpectedly during high-speed traversal.
Cause: Electromagnetic Interference (EMI) from unshielded stepper cables acting as antennas, injecting noise into the Arduino's 5V logic lines.
Solution: Keep stepper motor cables under 1.5 meters. Longer runs require shielded cables with the shield grounded at the controller end only. Twist the stepper motor wires (A1 with A2, B1 with B2) tightly to cancel out magnetic fields. Solder a 100nF ceramic capacitor directly between the STEP and DIR pins and Ground on the CNC shield to filter high-frequency logic noise.
Symptom: The motor runs perfectly for 3 minutes, then suddenly stalls or loses steps, resuming only after it cools down.
Cause: The DRV8825's internal thermal shutdown protection is triggering at 150°C. This happens when the Vref is set too high, or the driver lacks adequate convective cooling.
Solution: Re-verify your Vref. If the current limit is correct, you must upgrade the heatsink. The standard peel-and-stick aluminum heatsinks provided in cheap 2026 Amazon kits are insufficient for currents above 1.2A. Upgrade to a 40mm active cooling fan blowing directly across the shield, or switch to external DM542T industrial drivers if your application demands continuous 3A+ operation.
Mastering an Arduino stepper driver shield requires moving beyond basic plug-and-play assumptions. By rigorously identifying coil pairs, mathematically tuning the Vref potentiometer, and leveraging the non-blocking capabilities of the AccelStepper library, you transform a basic microcontroller into a highly reliable industrial motion controller. Whether you are building a pen plotter or a 4-axis robotic arm, these foundational wiring and coding practices will ensure your hardware survives and your motion profiles remain flawlessly smooth.
Build a CNC using Arduino Uno and GRBL. Includes TMC2209 driver VREF tuning, exact pinouts, error code debugging, and a smart Z-probe macro sketch.
The most reliable, cost-effective way to build a hobbyist desktop router or plotter is building a CNC using Arduino hardware paired with the open-source GRBL firmware. While newer 32-bit boards exist, the 8-bit Arduino Uno R3 running GRBL v1.1h remains the undisputed baseline for 3-axis machines due to its deterministic step-pulse timing and massive community support. This guide provides the exact hardware stack, stepper driver tuning math, pin mappings, and a companion macro-sender sketch to get your machine cutting without the usual trial-and-error.
The CNC Shield V3 accepts standard Pololu-style stepper drivers. Your choice dictates machine noise, heat dissipation, and low-speed torque. Use this decision path to select your driver:
Assuming a standard 3018-style or 600x400mm custom aluminum extrusion frame, here is the definitive bill of materials. Prices reflect typical 2026 market rates for genuine or high-quality clone components.
Note: Always run TMC2209 drivers at 24V rather than 12V. Higher voltage pushes current into the motor coils faster, maintaining torque at high traverse speeds (above 2000 mm/min).
The Protoneer V3 shield hardwires specific Arduino pins to the driver sockets. Do not attempt to change these in the firmware without physically rewiring the shield. Reference the Protoneer CNC Shield documentation for physical layout.
When communicating with GRBL via Universal Gcode Sender (UGS) or Candle, you will inevitably hit errors. Here are the exact strings returned over serial, ranked by frequency, and how to clear them.
While the main Arduino Uno runs the GRBL firmware, interacting with it via physical buttons requires a secondary microcontroller to avoid USB ground-loop crashes. The following complete, compilable sketch targets an Arduino Nano v3 (ATmega328P) . It acts as a hardware Z-axis touch-probe macro sender. It connects to the GRBL Uno via Serial, sends the probing G-code, and includes robust error handling to parse GRBL's exact error strings.
If your machine is stuttering, losing steps, or refusing to move, run this diagnostic triage before touching the firmware:
Depending on your workshop needs, this baseline Arduino CNC architecture can be scaled in either direction.
Extend (Upgrading to 32-bit FluidNC): The Arduino Uno's 16MHz ATmega328P maxes out at roughly 30kHz step pulse rates. If you plan to use microstepping above 1/16 or require high-speed laser rastering, the Uno will bottleneck your feedrates. The definitive upgrade path is migrating to an ESP32-based board (like the Makerbase MKS DLC32) running FluidNC . FluidNC maintains the exact same G-code dialect and pin-mapping philosophy as GRBL but leverages the ESP32's 240MHz dual-core processor, native WiFi for wireless G-code streaming, and I2S hardware for flawless step-pulse generation up to 200kHz.
Hardware Schematics & Pinout Diagrams
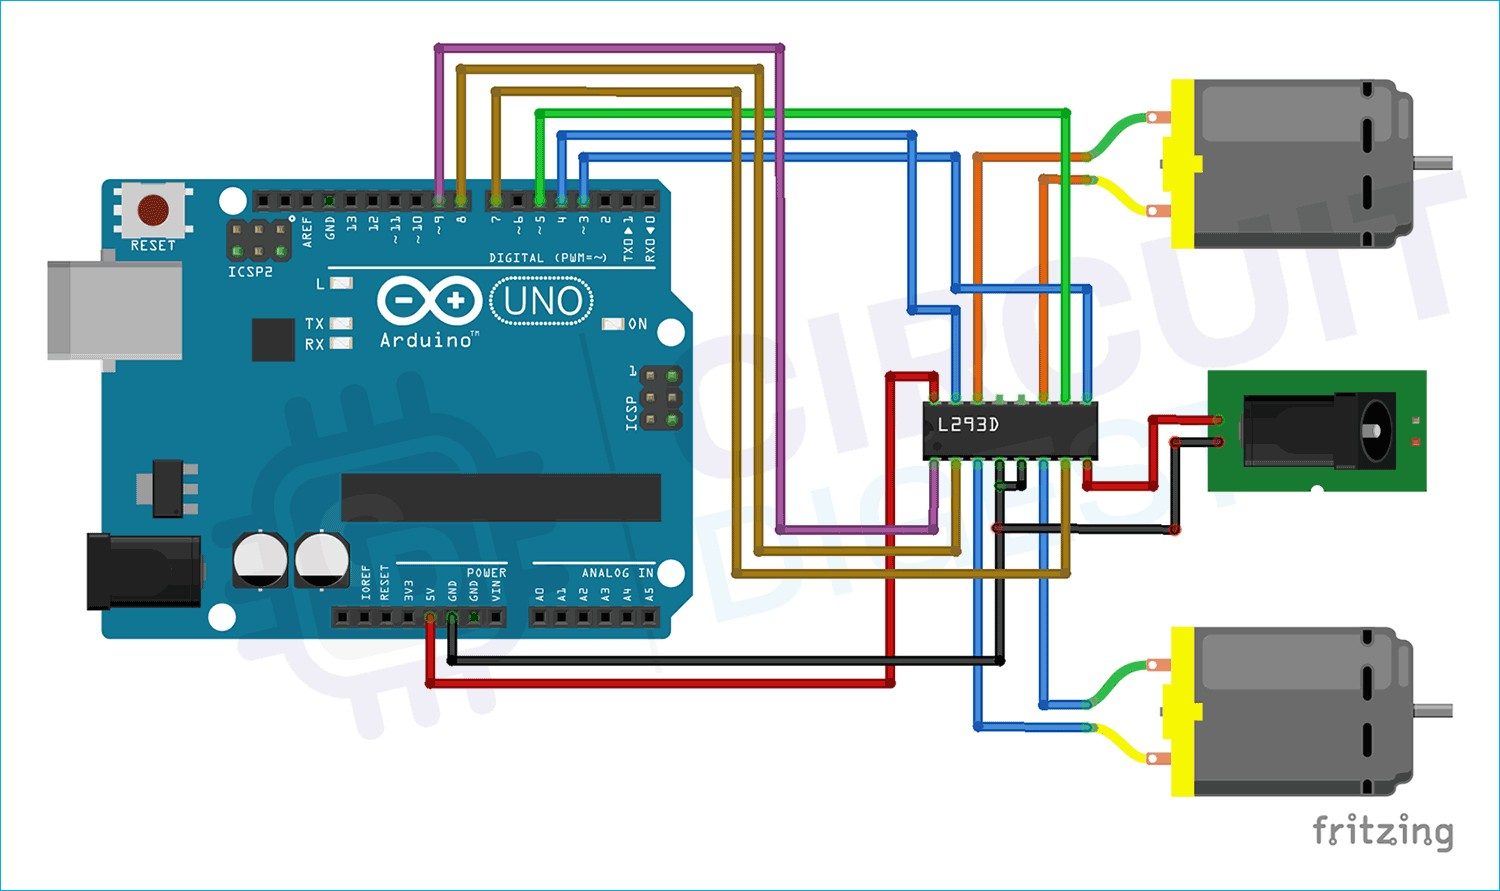
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Multi Axis Cnc Milling Spindle Load Monitor With Automated Feed Rate Throttle Via Arduino... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |