Electric Vehicle Smart Charging Cable With Ground Fault Circuit Interruption Gfci Logic
The high cost of EV (electric vehicle) chargers may lead you to believe that they’re complex systems. But with the exception of Tesla’s Supercharger, that isn’t true. They’re actually quite simple — basically just glorified switches. All of the nitty gritty charging details are the responsibility of the car’s onboard circuitry. With that in mind, EV owners may want to follow Pedro Neves’ guide on building an affordable Arduino-based charging station.
Because the car deals with all of the particulars of charging, the only purpose of the “charger” is to provide a connection to the electrical grid. “Charger” isn’t even the right word, as this is more accurately EVSE (electric vehicle supply equipment). For safety reasons, the car and the EVSE communicate with each other. The car can tell the EVSE when it is safe to provide power and the EVSE will then connect a switch between the charging plug and the electrical grid. It really isn’t any more complex than a $15 smart outlet and most of the cost of an EVSE is the heavy-gauge wiring.
Here, Neves proves that with a DIY EVSE designed around an Arduino UNO Rev3 board. It has a custom shield with relays for switching power and to power the Arduino itself with mains voltage. A few LEDs act as status indicators. EVSE protocols are standardized, so Neves was able to program the Arduino to communicate with any connected car. Once the Arduino receives permission from the car, it switches the relays to provide mains voltage. A heavy-duty 3D-printed enclosure contains those components, with a breaker switch and weatherproofing.
Ground Fault Circuit Interrupter (GFCI) protection is a mandatory electrical safety requirement that applies to most EV charging installations across the United States. This page covers the specific code requirements, protection types, installation scenarios, and compliance boundaries that govern GFCI use in both residential and commercial EV charging contexts. The National Electrical Code (NEC) sets the foundational rules, enforced through local permitting and inspection processes that vary by jurisdiction.
A Ground Fault Circuit Interrupter detects imbalances between outgoing and returning current on a circuit â imbalances as small as 4 to 6 milliamps trigger the device to interrupt power within as little as 1/40th of a second ( UL 943, Standard for Ground-Fault Circuit-Interrupters ). In EV charging applications, this protection is critical because charging equipment operates in environments where moisture, physical damage, and extended energization periods create elevated shock and fault risk.
NEC Article 625 , which governs Electric Vehicle Power Transfer Systems, mandates GFCI protection for EV charging equipment in specific installation contexts. The 2023 edition of the NEC further refined and expanded these requirements compared to earlier code cycles, including the 2020 edition. The scope of GFCI requirements depends on charger level (Level 1, Level 2, or DC fast charging), installation location (indoor, outdoor, garage, commercial parking), and the type of GFCI device deployed.
Understanding EV charger grounding and bonding requirements is prerequisite knowledge before addressing GFCI layering, since the two systems operate in concert â grounding provides a fault current path, while GFCI detects when current departs that path.
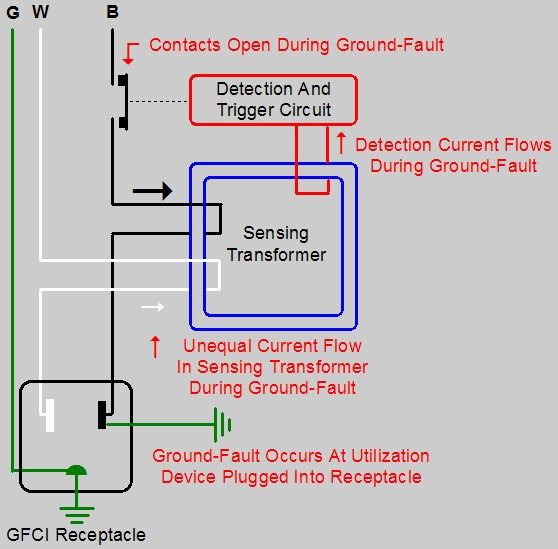
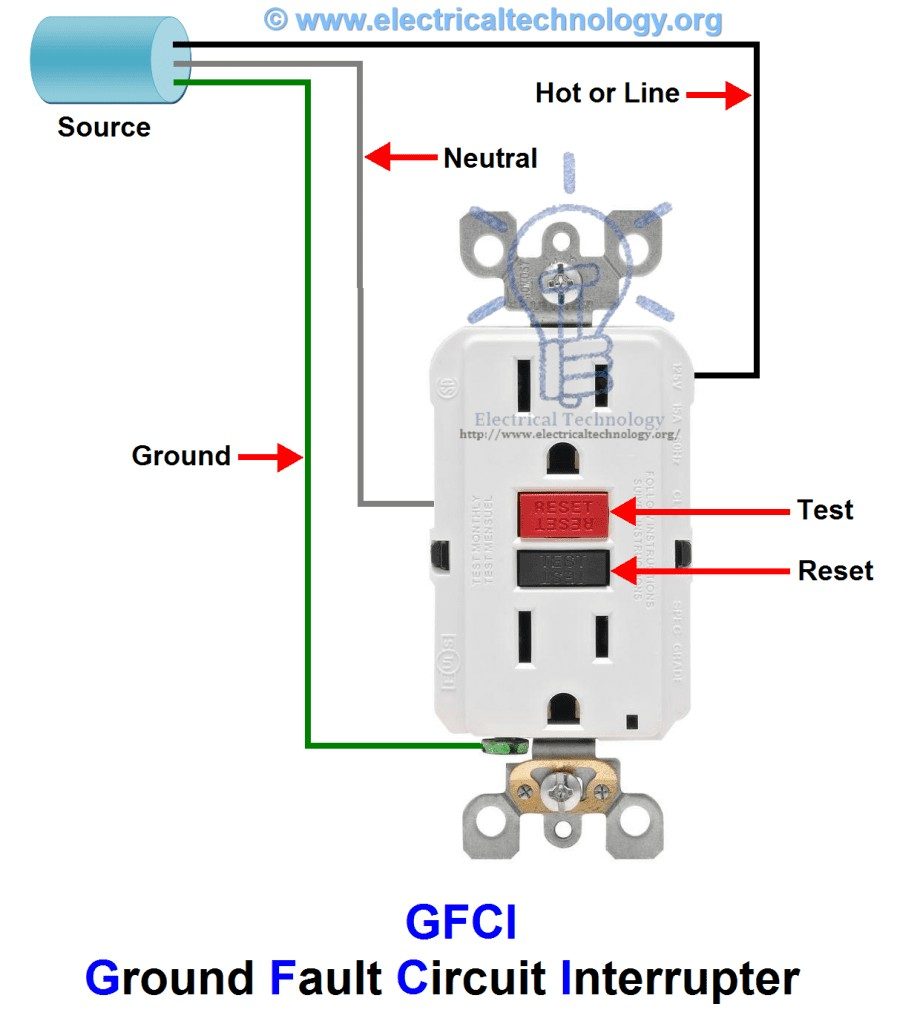
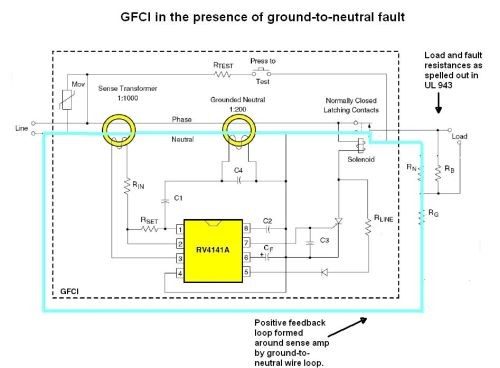
GFCI devices monitor differential current between the hot conductor and the neutral conductor. Under normal operation, current flowing out equals current returning. When a fault occurs â such as current leaking through a person, a damaged cord, or pooled water â the differential exceeds the trip threshold and the device opens the circuit.
The distinction between Class A and Class B GFCI is codified in UL 943. Class A devices trip at 6 milliamps or less and are the standard for personnel protection â required in virtually all residential and commercial EV charging contexts. Class B devices trip at 20 milliamps and are permitted only for specific underwater applications; Class B is not compliant for EV charger installation under NEC Article 625.
Residential garage (Level 1): A 120V outlet used for Level 1 charging in a garage requires GFCI protection under NEC 210.8 (garage receptacles). A GFCI breaker or GFCI receptacle at the point of use both satisfy this requirement.
Residential garage (Level 2): A 240V, 50-amp dedicated circuit feeding a hardwired Level 2 EVSE requires GFCI protection per NEC 625.54. Under the 2023 NEC, this requirement is explicitly reinforced, and a double-pole GFCI breaker in the panel, or an EVSE with integrated verified GFCI, satisfies this requirement. Level 2 charging electrical specs detail the circuit parameters involved.
Outdoor residential installation: Any outdoor 120V or 240V receptacle or EVSE is subject to GFCI requirements under NEC 210.8(A)(3) (outdoor locations) and NEC 625.54 concurrently. Both provisions apply simultaneously.
Commercial parking facility: Commercial installations, including multifamily EV charging electrical systems and workplace charging, are subject to NEC 625.54 and may also fall under NEC 210.8(B) for commercial garages. EVSE verified under UL 2594 with integrated GFCI is the most common compliance path in commercial deployments.
DC fast charging (DCFC): NEC 625.54 applies to all EVSE, including DC fast chargers. In practice, DC fast charging equipment verified under UL 2202 typically incorporates internal isolation and ground fault detection that satisfies the protective intent of the code, though inspection authorities have discretion in how they apply the requirement to high-power DC systems.
A Class A GFCI breaker at the panel is the broadest protection strategy â it covers the full branch circuit regardless of EVSE provider status and is accepted by all AHJs under adopted NEC editions that include NEC 625.54.
The charge current interrupting device (CCID) is a safety feature that is implemented in electric vehicle (EV) charging stations ( EVSE ) to prevent shock, electrical fires, and damage to personnel and vehicles during charging. The CCID is designed to interrupt the flow of current in the charging cable if it detects abnormal conditions such as a ground fault or leakage current. The CCID is analogous to the ground fault circuit interrupter (GFCI) used for electrical shock protection in residential and industrial applications. In a way, the functions are almost identical, but the mere nomenclature was changed to reflect an application related to charging.
A CCID is essentially a smart switch that monitors the flow of current in the charging cable. When the CCID detects a fault, it interrupts the flow of current in the charging cable, thus preventing any further damage. The CCID is typically installed as a part of the charging station's interior controls.
EV AC charging stations typically use two types, or levels, of power: Type 1 and Type 2. Type 1 usually refers to the small onboard emergency plug in cable that typically has very low power levels, around 1KWh. Level 2 are usually rated higher and represent wallboxes that can be mounted in a garage, up to more commercial versions that might be found in front of a hotel. In both cases, the CCID is integrated into the controller to ensure the safety of the charging process.
When a vehicle is plugged into a charging station, the controller first checks for the presence of the vehicle and verifies that it is compatible with the charging station. Once the charging process begins, the CCID continuously monitors the flow of current in the cable. If the CCID detects any abnormalities such as a ground fault, it immediately interrupts the flow of current to prevent any further damage.
The CCID is an essential safety feature in EV charging stations that helps to prevent electrical fires and damage to vehicles. It is important to note that the CCID is not a substitute for proper maintenance and installation of an EV charging station. It is essential that EV charging stations are installed and maintained by qualified professionals to ensure the safety of the charging process.
CCIDs are a vital safety feature in EV charging stations. These devices prevent electrical fires and damage to vehicles during charging, as well as prevent personnel from hazardous electrical situations. As mentioned, the CCID can be described as a smart switch that monitors the flow of current in the charging cable and interrupts the flow of current if it detects any abnormalities.
It is important to note that a CCID, it’s design, performance and functionality are governed by Underwriters Laboratories (UL), which is a nationally recognized testing laboratory (NRTL). The standard governing CCIDs is UL 2231.
Bender has been involved in the manufacturing of CCIDs for electric vehicle safety equipment (EVSE) for the last decade. To adhere to the UL standards is a must for these devices, but this costs serious time and effort to go through the lengthy testing cycles that UL requires.
They help prevent electrical fires and damage to vehicles, all while keeping users of all ages safe.
UL 2231 is a safety standard developed by UL for charge controllers and CCID devices used in EV charging stations. The standard was first introduced in 2014 to address safety concerns associated with charging electric vehicles.
The UL 2231 standard outlines specific safety requirements for CCID devices, including testing and performance criteria. The standard is intended to ensure that CCID devices used in EV charging stations are safe and reliable. UL 2231 is particularly relevant to CCID devices used in EV charging stations. CCID devices are a critical safety feature in EV charging stations, and the UL 2231 standard helps to ensure that these devices meet specific safety requirements.
Hardware Schematics & Pinout Diagrams
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Electric Vehicle Smart Charging Cable With Ground Fault Circuit Interruption Gfci Logic... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |