Development Of An All Terrain Stair Climbing Rocker Bogie Rover With Active Articulation Via Arduino
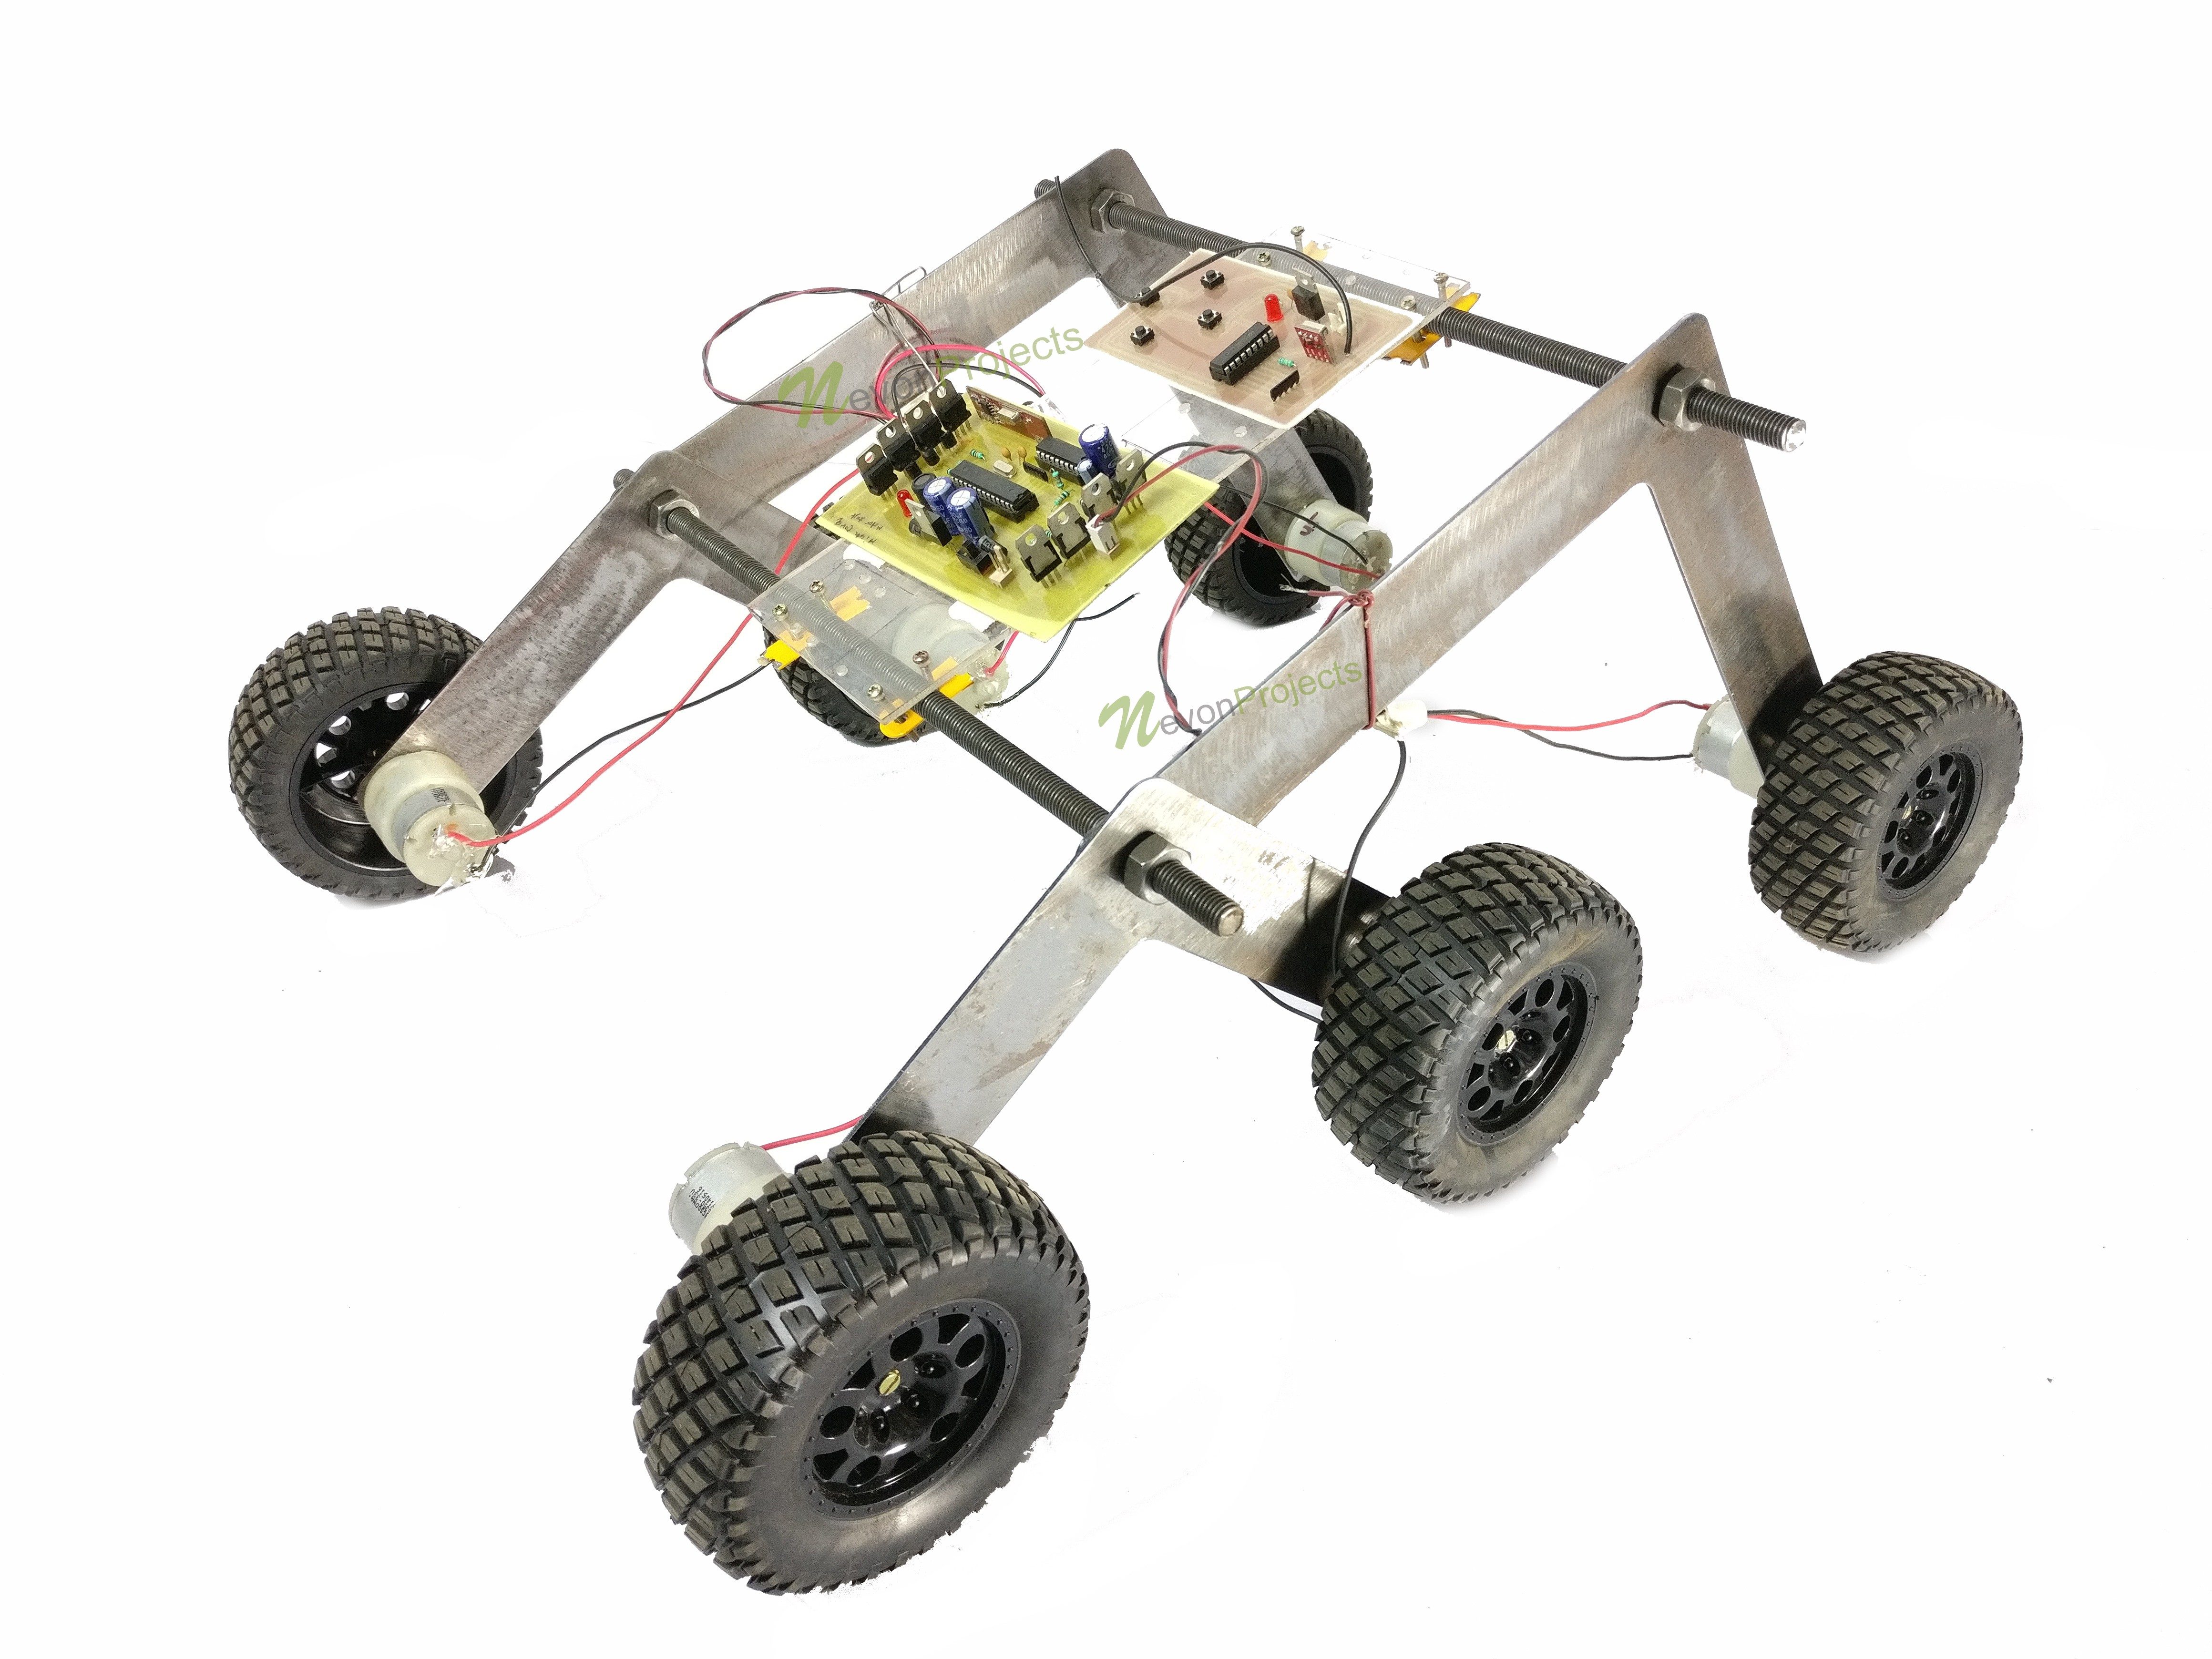
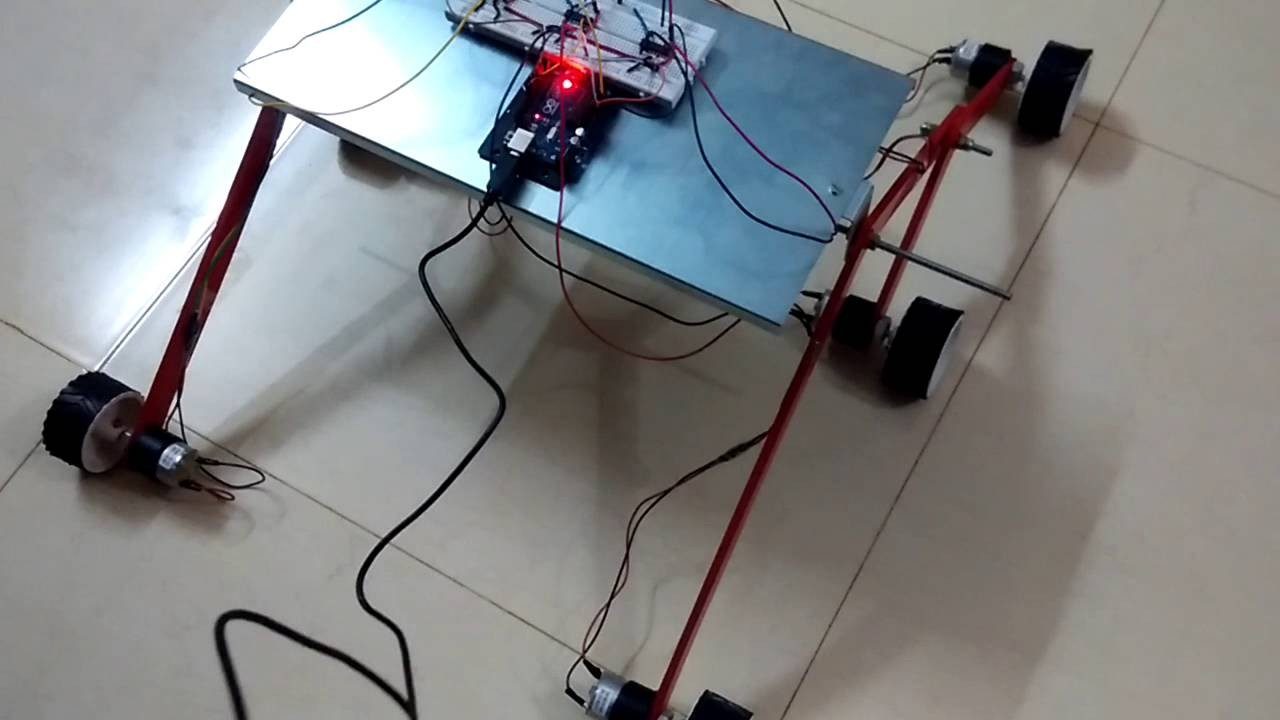
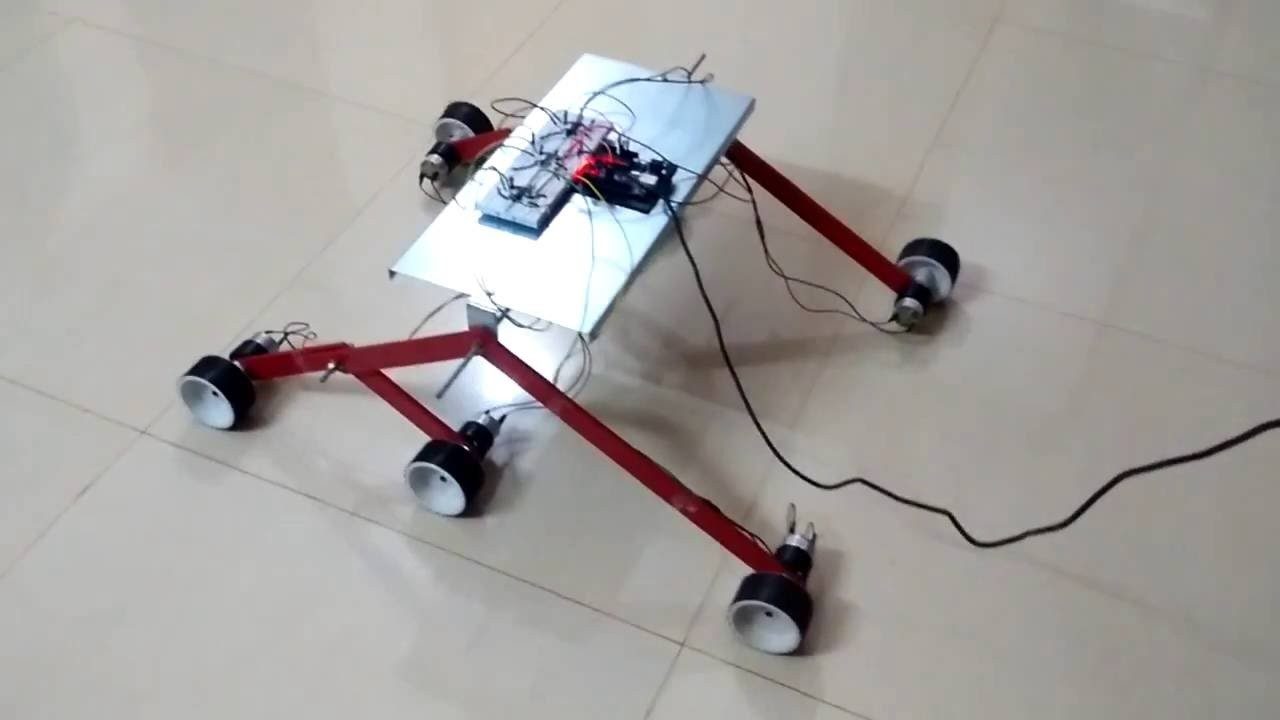
This repository contains the design and implementation details for a Remote-Controlled Stair-Climbing Device. The device employs a Rocker-Bogie Suspension Mechanism inspired by NASA's Mars Rovers, enabling it to climb stairs and traverse rugged terrains effectively. It is controlled via Bluetooth and built using economical and readily available components.
The Rocker Bogie Suspension Vehicle is a type of rover widely used in planetary exploration, such as on NASA’s Mars rovers. The vehicle’s suspension system allows it to traverse rough terrain, and it is commonly used in robotics competitions and learning projects.
This repository contains the design and implementation details for a Remote-Controlled Stair-Climbing Robot . The robot employs a Rocker-Bogie Suspension Mechanism inspired by NASA's Mars Rovers, enabling it to climb stairs and traverse rugged terrains effectively.
The robot climbs stairs by leveraging the Rocker-Bogie suspension system , where:
Special thanks to Easwari Engineering College and all team members for contributing to this project.
Hardware Schematics & Pinout Diagrams
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Development Of An All Terrain Stair Climbing Rocker Bogie Rover With Active Articulation Via Arduino... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |