Autonomous Wind Turbine Blade Vibration Telemetry Node For Structural Integrity Auditing
An industrial-grade Embedded Systems and IoT solution developed for automated monitoring, actuation, and wireless data telemetry.
Founder & Electronics Engineer — DIY CIRCUITS 📍 Location: Nagpur, Maharashtra, India 📧 Email: info@diycircuits.in 📞 Phone: +91 84461 73429 🏢 Address: 373 Panchpaoli Rd, Balabhaupeth, Nagpur, Maharashtra – 440017, India
For project inquiries, custom electronics development, commercial licensing, or technical collaboration:
This repository contains the code and simulation files for the paper titled "Visual Tracking Nonlinear Model Predictive Control Method for Autonomous Wind Turbine Inspection". Link to paper
For this purpose, a time optimal path planner and a Visual tracking MPC is developed.
We provide a general inspection framework, that takes the dimensions of the wind turbine as input, and provides the optimal attitude rate and thrust command to the drone to acheive optimal coverage.
The approach is modular, where the global plan for inspecting is provided through a time optimal graph based path planner. The output of the path planner is sequentially input to a NMPC with visual tracking costs, that allows the drone to acheive optimal pose relative to the surface for best heading, incidence angle and distance from the surface. More details on the method can be found soon through the paper submitted for publication.
Download the PX4 folder from here and place it inside the Wind-Turbine-Inspection folder.
The optimal sequence of points and surface normals are created in txt file format, which the NMPC uses to generate optimal control actions. The planner is run for a default wind turbine model.
If you use this framework in your work, please cite the following paper: Link to paper
This repository contains the code and simulation files for the submitted paper titled "Autonomous Wind Turbine Inspection Framework Enabled by Visual Tracking Nonlinear Model Predictive Control (VT-NMPC)".
Hardware Schematics & Pinout Diagrams
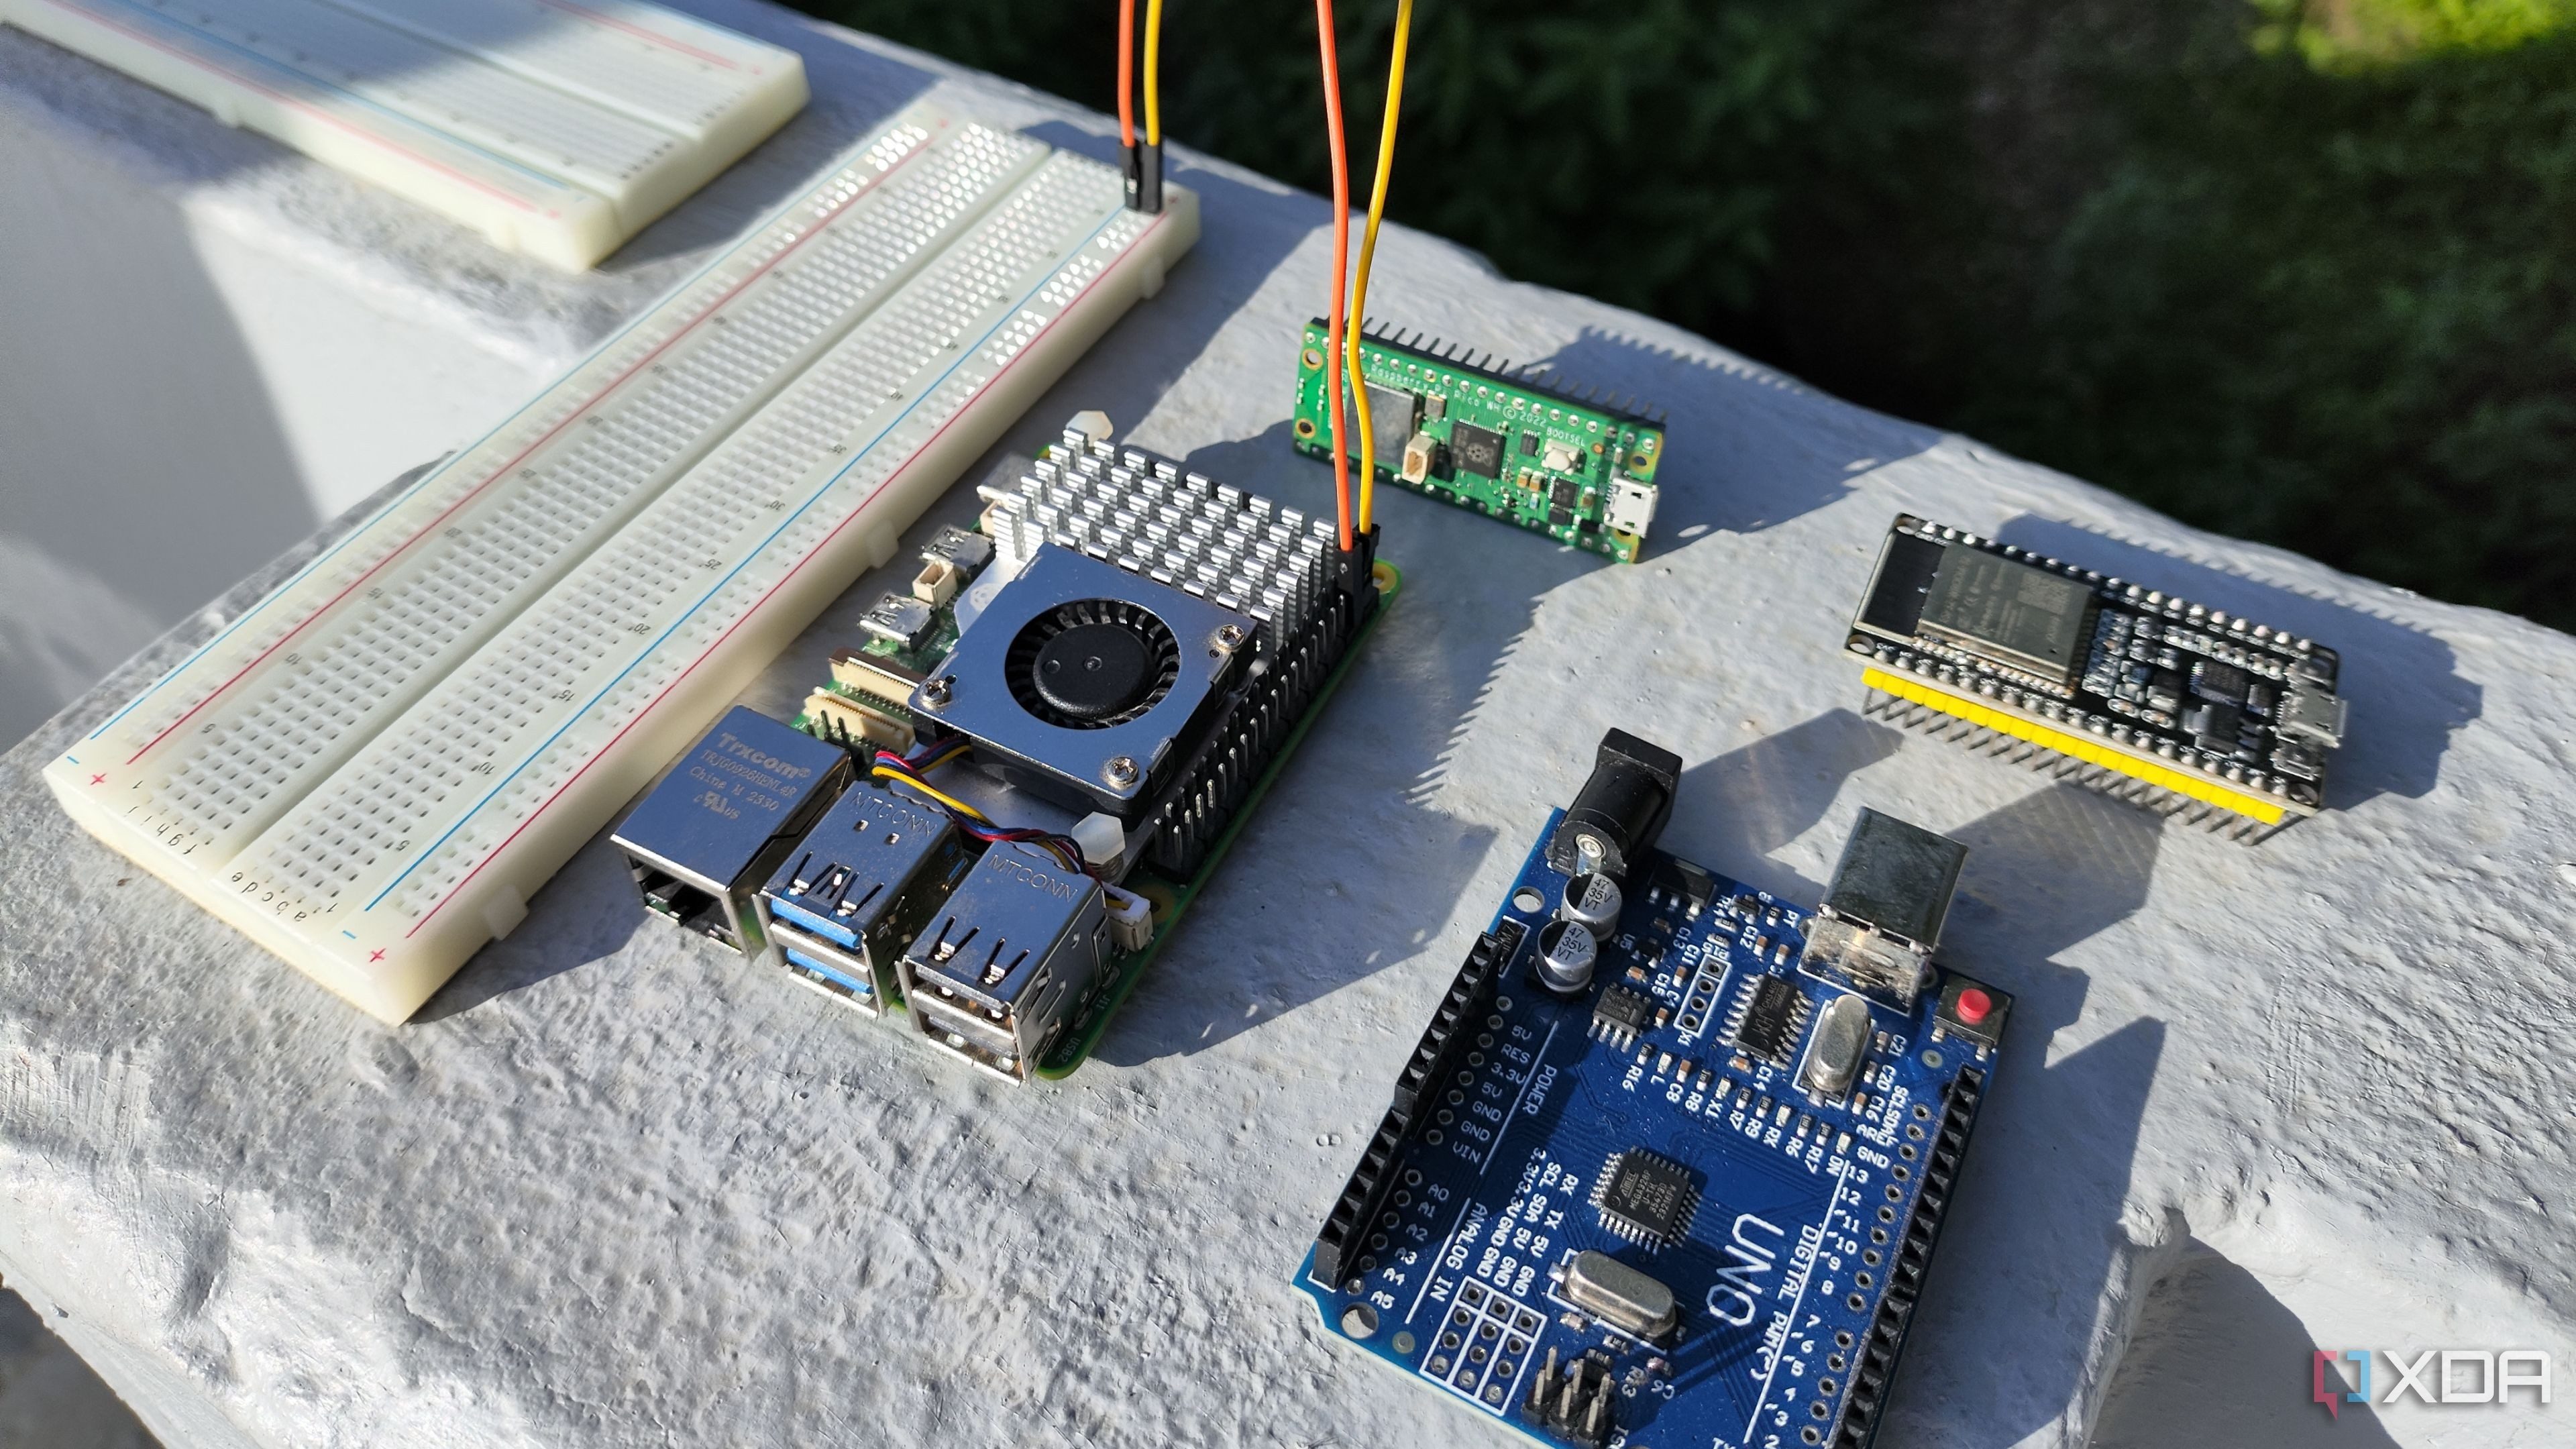
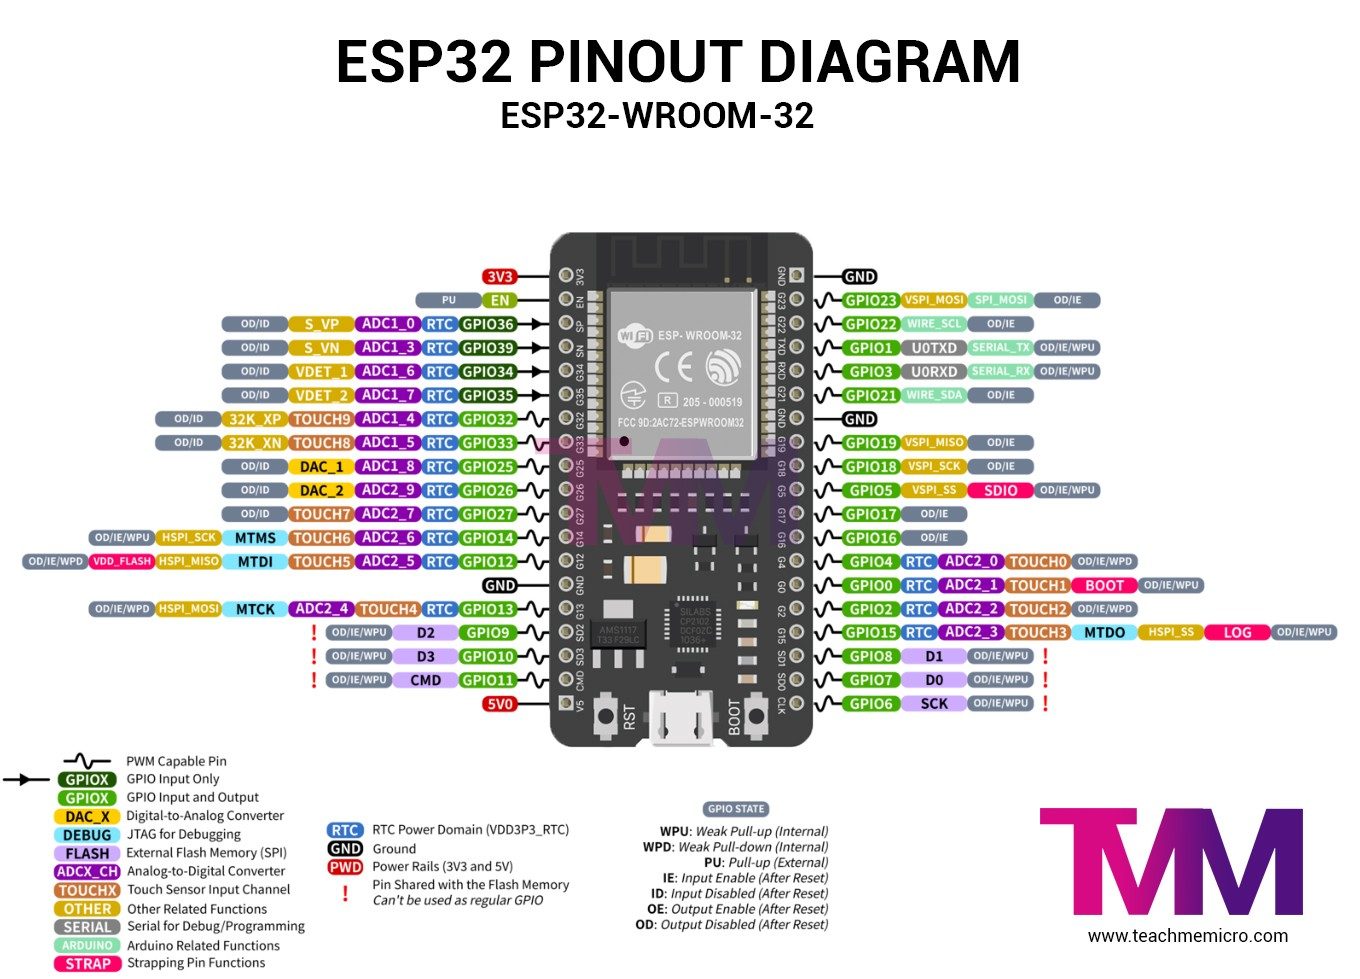
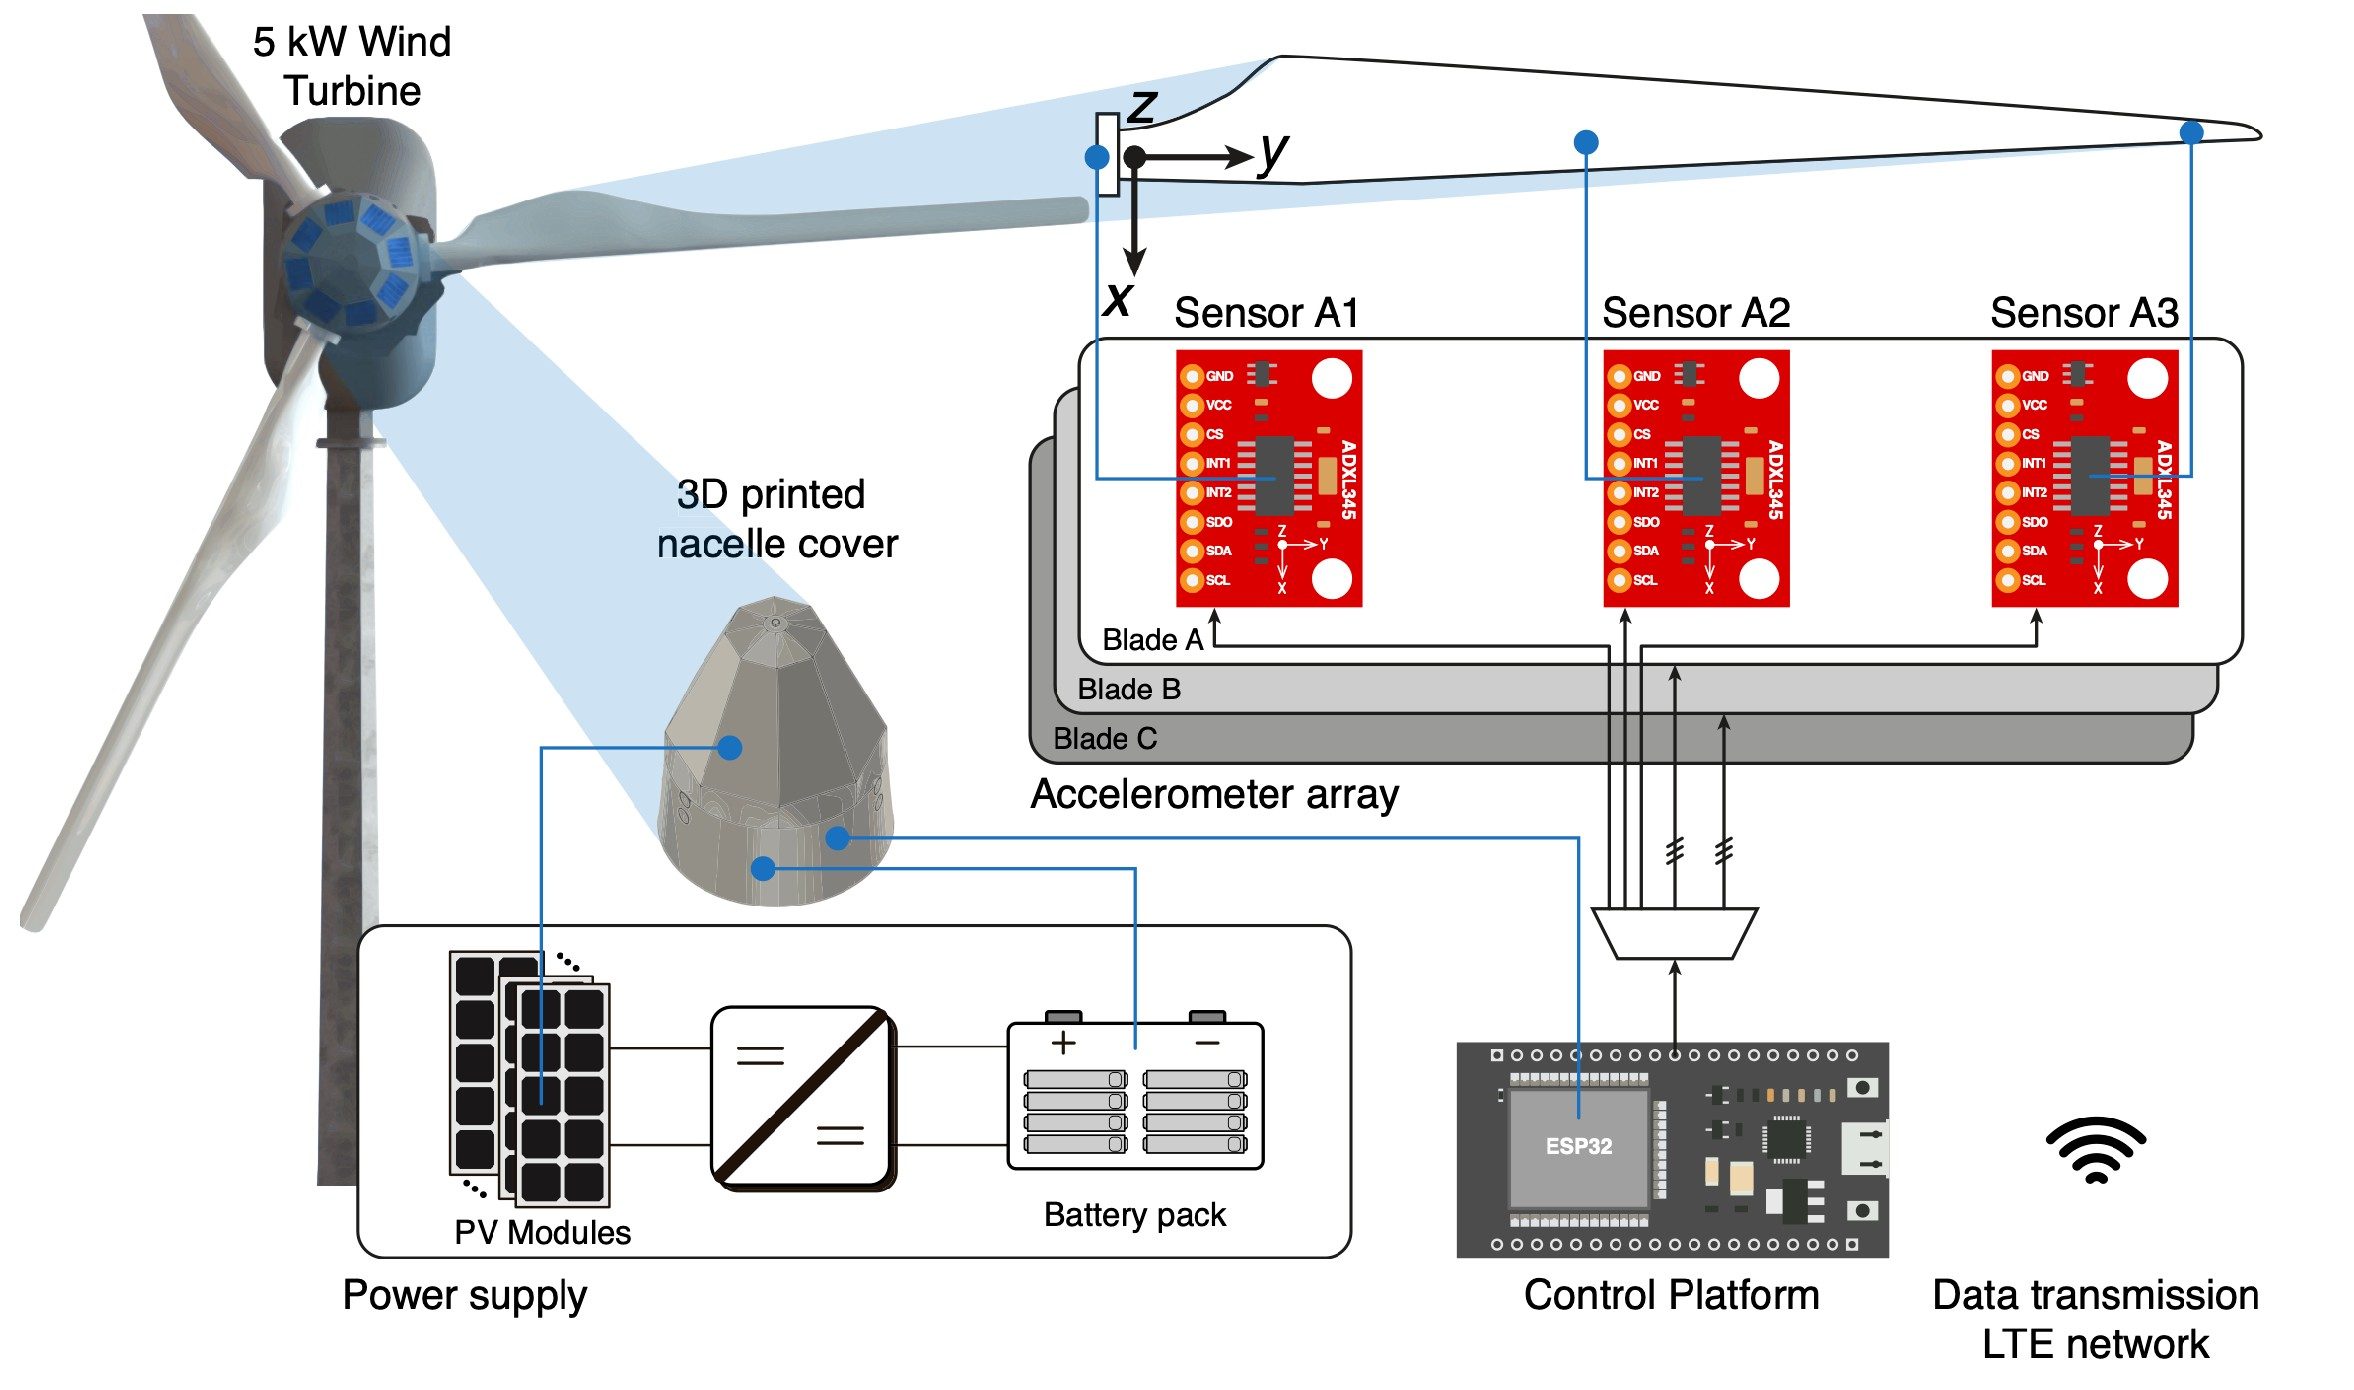
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Autonomous Wind Turbine Blade Vibration Telemetry Node For Structural Integrity Auditing... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |