Autonomous Solar Assisted Golf Cart With Automatic Ultrasonic Obstacle Avoidance
"""It is recommended to read the PDF for full technical details: Autonomous_Cart.pdf"""
Autonomous Arduino cart that navigates toward IR signals while avoiding obstacles using ultrasonic sensors.
A working prototype of a self-navigating robotic car that detects obstacles in its path and automatically adjusts movement based on programmed logic. Built using Arduino Uno, ultrasonic sensor, motor driver shield — designed for modular behaviour customisation and robust performance in varied environments.
This project demonstrates how to build an autonomous obstacle-avoidance vehicle using the Arduino platform. It uses ultrasonic distance sensing to detect nearby objects, and dynamically alters direction to avoid collisions. The car’s movement logic (forward, left, right, stop) is defined in Arduino code and can be customised. Sensor placement and motor control have been fine-tuned across varied surfaces and lighting conditions to achieve smooth and reliable navigation.
This project is open-source and available for educational and personal use. Licensed under the MIT License – see LICENSE for details.
Autonomous Arduino-based obstacle-avoidance car prototype. Uses ultrasonic sensing and motor driver shield for dynamic navigation. Includes code, circuit diagram and build assets.
Hardware Schematics & Pinout Diagrams
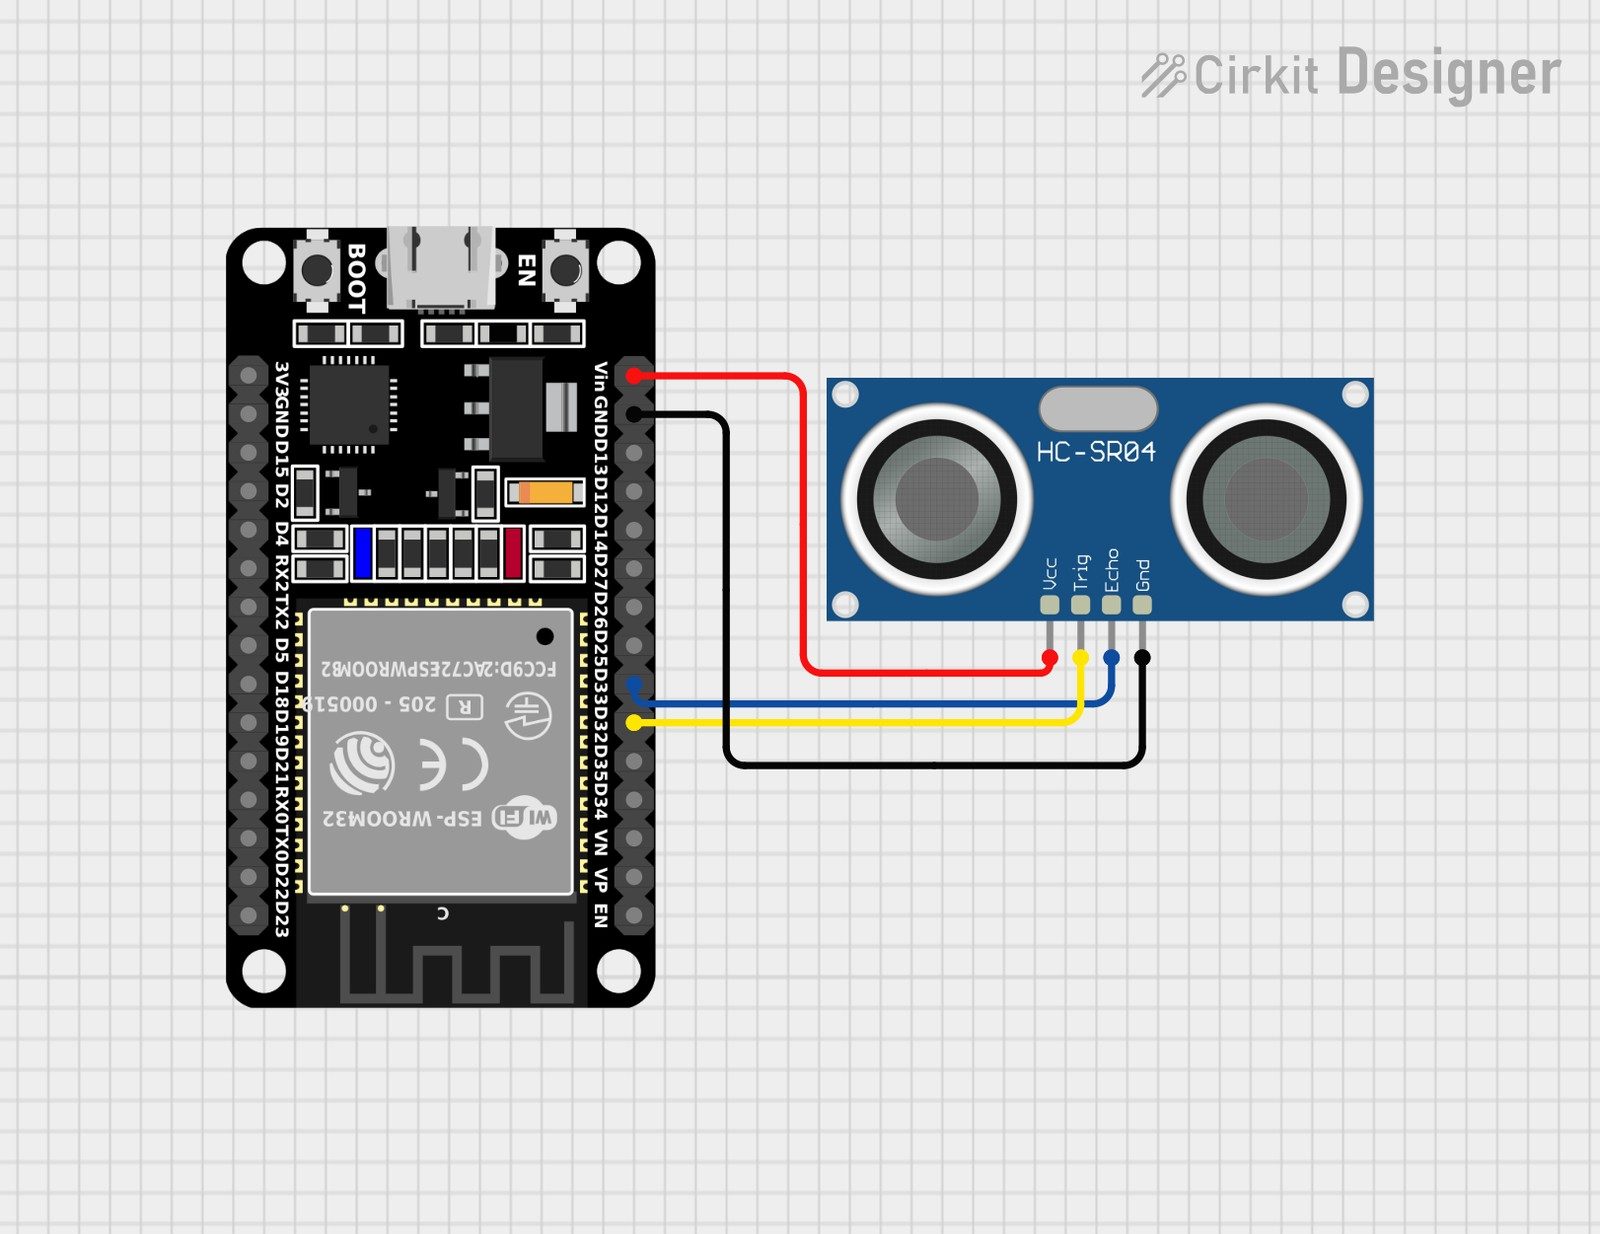
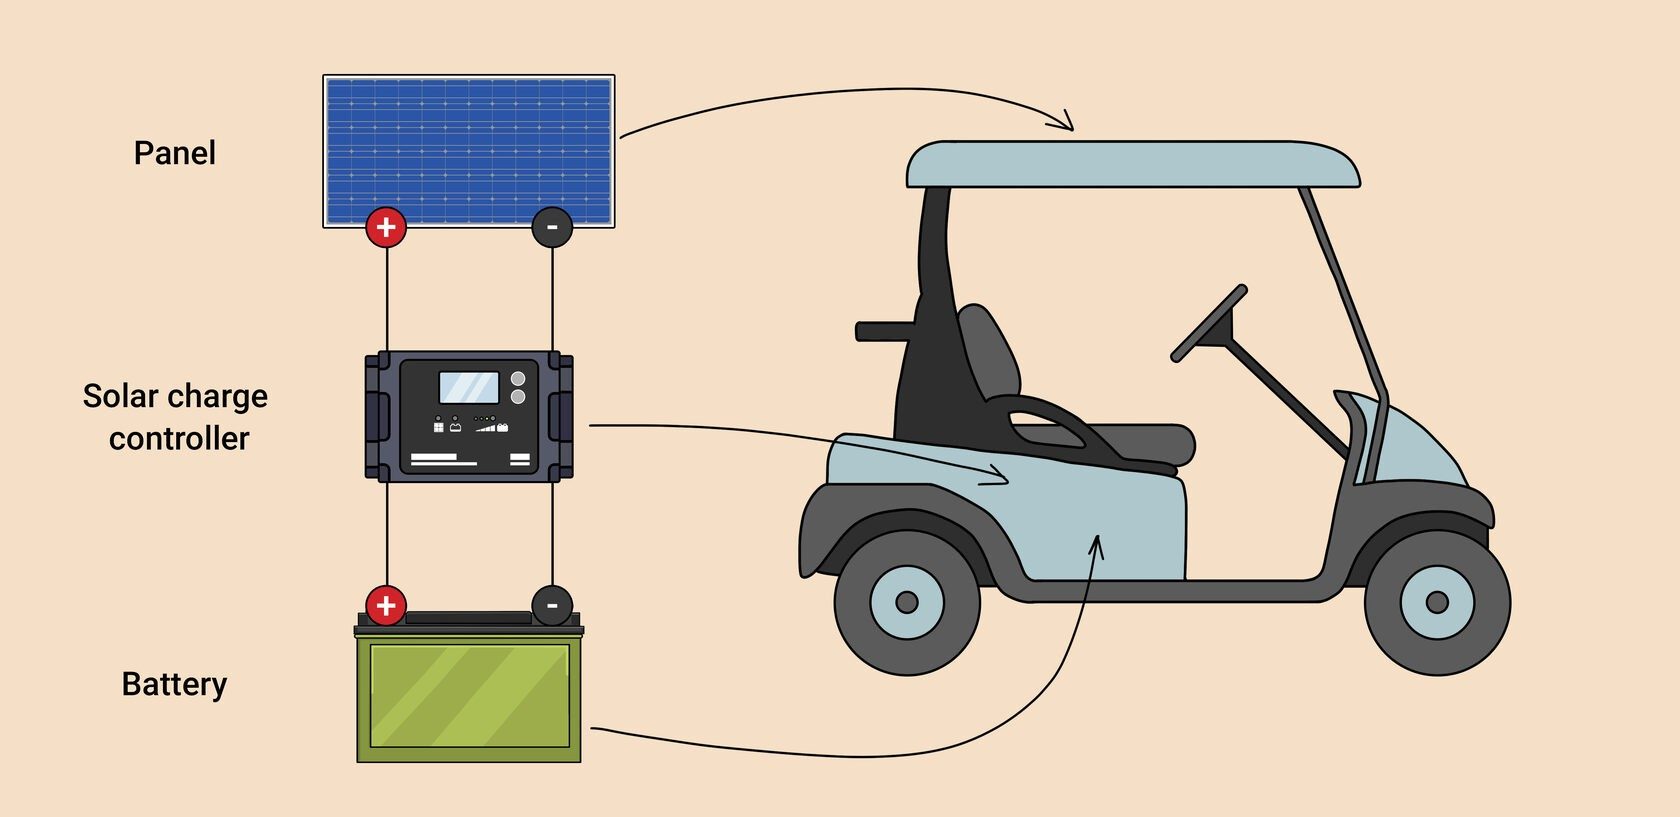
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Autonomous Solar Assisted Golf Cart With Automatic Ultrasonic Obstacle Avoidance... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |