Autonomous Greenhouse Pollination Drone With Hover Hold Precision Controlled By Arduino
this program will show simple led on and off operation using Arduino Uno and Bluetooth
The DHT11 measures relative humidity. Relative humidity is the amount of water vapor in air vs. the saturation point of water vapor in air. At the saturation point, water vapor starts to condense and accumulate on surfaces forming dew.The DHT11 uses just one signal wire to transmit data to the Arduino interface diagram is shown in above fig. Using DHTLib library. It has all the functions needed to get the humidity and temperature readings from the sensor which is shown below program.
here we use a Bluetooth module (HC-05) for bidirectional communication purpose, for turn ON the drone and to receive the sensor data's. two resistors are used as a voltage divider to step down the 5 volts to 3.3 volts so that Bluetooth can receive the data from the Arduino Uno. The circuit is so simple and small , there is only few connection to be made Arduino Pins Bluetooth Pins RX (Pin 0) ———-> TX TX (Pin 1) ———-> RX 5V ———-> VCC GND ———-> GND
The flight controller (Cc3d) will provides 5 input control pins which gives the 4 movement actions to the drone they are throttle, roll, yaw, and pitch. These pins need a PWM signal to work, so we will generate the PWM signal using Arduino Uno. By proper planning and sketch of a particular are we can program the Arduino by calling function with delay.
Autonomous drones merge robotics, sensor fusion, and intelligent programming Your First Hands-On Arduino Project Embark on your Arduino journey with our step-by-step guide. to create machines capable of independent decision-making. This guide combines hardware assembly, software integration, and advanced algorithms to help you build a drone from scratch using Arduino. Designed for makers with intermediate electronics and coding skills , this project bridges hobbyist experimentation and professional-grade robotics Bluetooth Remote Control with Arduino and HC-05 Unlock seamless Bluetooth control with Arduino! Discover HC-05 wiring, AT commands, and coding techniques for robust IoT & robotics projects. .
2. Connect ESCs to Arduino PWM pins (3, 5, 6, 9 for quadcopter configuration Setting up the Arduino Environment Unlock your Arduino journey with our step-by-step guide. Install, configure, and troubleshoot the IDE on Windows, macOS, and Linux for prototyping. ).
3. Mount IMU, GPS, and ultrasonic sensors Ultimate Guide to Ultrasonic Sensors (HC-SR04) Dive into HC-SR04 ultrasonic sensor mastery with expert coverage of sensor physics, wiring techniques, code optimization, and industrial applications. via I2C/UART.
4. Secure the power distribution board and battery with XT60 connectors Understanding Arduino Components Explore every Arduino board component and learn expert integration tips to boost your design and troubleshooting skills in our comprehensive guide. .
1. Bench Testing Your First Hands-On Arduino Project Embark on your Arduino journey with our step-by-step guide. :
4. Data Logging Automated Irrigation System with Sensors and Relays Discover how to design and implement an automated irrigation system using sensors and relays to efficiently manage water and enhance plant care. :
Building an autonomous drone with Arduino demands meticulous integration of hardware, software, and algorithms. By mastering sensor fusion, PID control, and state-machine logic, you can create a drone capable of intelligent navigation and decision-making. Iterative testing, safety protocols, and creative enhancements Your First Hands-On Arduino Project Embark on your Arduino journey with our step-by-step guide. will elevate your project from a simple RC craft to a robust aerial robot. Embrace the challenges, document your progress, and let each iteration bring you closer to autonomous flight mastery. Happy building!
Autonomous Pollination for Polyhouse Agriculture is a smart, AI-guided system designed to automate the pollination process in controlled and indoor farming environments. The project aims to improve crop productivity while reducing human effort and dependency on traditional farming methods.
Limited space, time constraints, and lack of agricultural expertise prevent many individuals from practicing efficient farming, especially in urban and controlled environments. Manual pollination methods are time-consuming and inefficient, creating a need for an automated, intelligent solution.
This video demonstrates the working of the Autonomous Pollination system developed during the hackathon.
Autonomous Pollination for Polyhouse Agriculture is an AI-guided automated system designed for controlled and indoor farming. It addresses challenges like limited space, time, and lack of expertise by enabling efficient pollination with minimal human intervention, promoting sustainable and smart agriculture.
Hardware Schematics & Pinout Diagrams
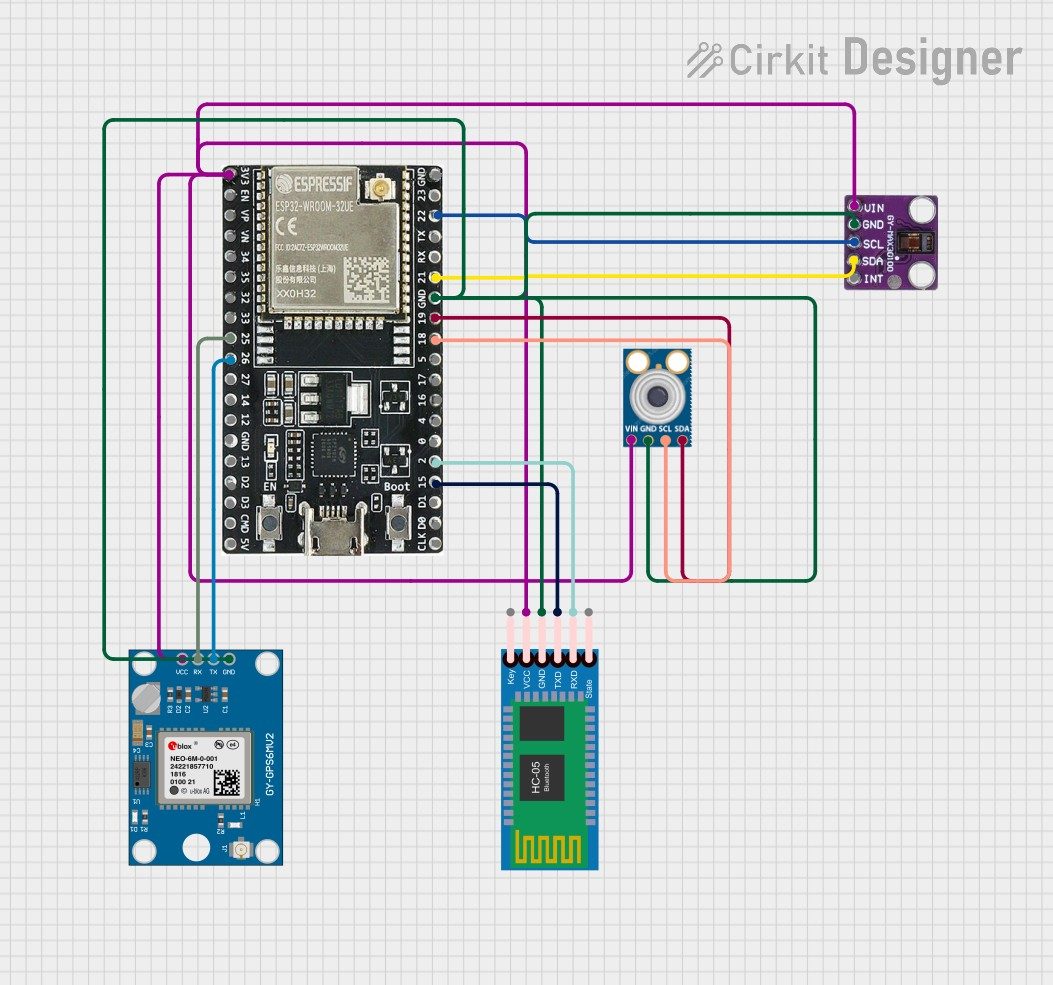
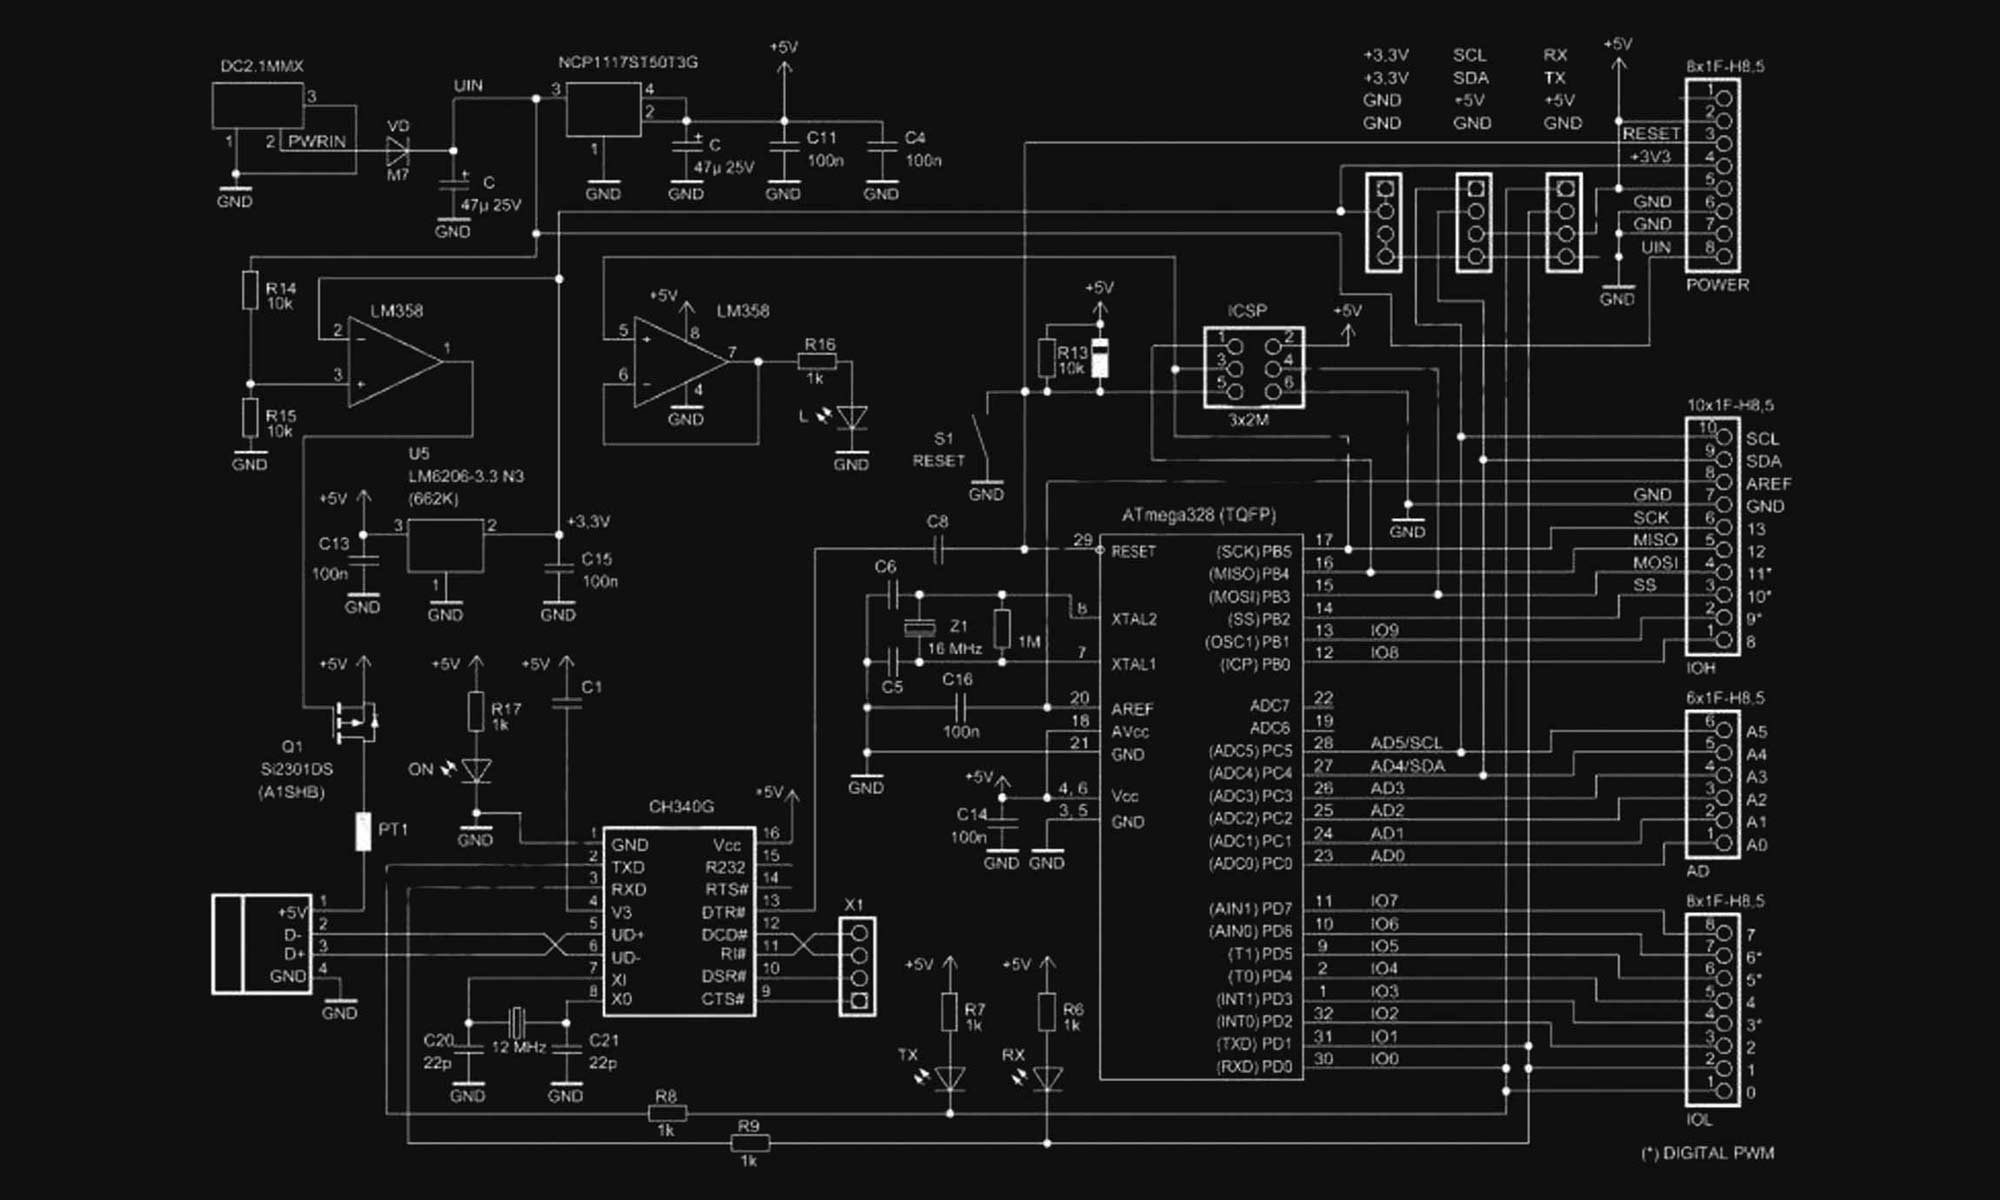
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Autonomous Greenhouse Pollination Drone With Hover Hold Precision Controlled By Arduino... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |