Autonomous Charging Rover For Stored Evs In Underground Warehouses Controlled By Arduino
This shared drive contains all the essential documentation for the Autonomous EV Charger Project conducted during our second year as part of the Praxis III course. The project aimed to create a system capable of autonomously detecting a charging port on an electric vehicle and connecting the charger within a set environment.
Each folder in this drive is organized to reflect the various aspects of the design process:
The documentation provided in this drive serves as an archive of our work and is intended for educational purposes. It offers insight into the practical application of interdisciplinary engineering skills to solve real-world challenges.
As the project was unfortunately cut before Milestone 3 due to unforeseen circumstances, the final design is not provided. However, the available materials still offer a comprehensive view of the project's development stages.
Thank you for exploring our project. We hope these documents inspire and guide future endeavors in autonomous systems and mechatronics.
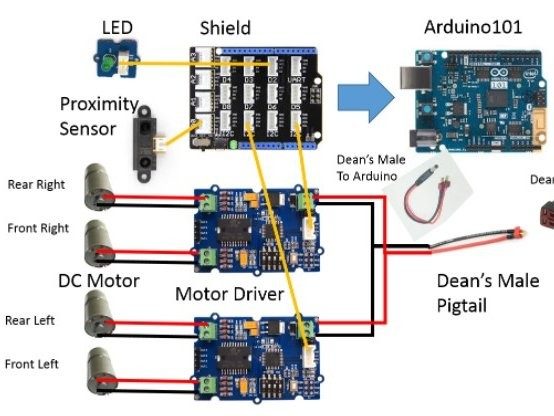
This code drives an Arduino101 microcontroller board using built-in Bluetooth Low Energy (BLE) functionality, 4 sets of motor on the SEEDstudio Skeleton Bot chassis driven by 2 grove I2C motor control drivers. Additional components included from SEEDstudio include: Grove LED Socket, Green LED, Grove 80cm proximity sensor.
Master advanced Arduino code projects for robotics. Learn non-blocking state machines, sensor fusion, and PID control for autonomous rover builds.
When engineers and makers transition from basic desktop prototypes to real-world autonomous rovers, they quickly discover that standard tutorials fall short. In 2026, building a reliable autonomous robot requires moving past simple delay loops and basic threshold logic. To create truly responsive machines, we must architect robust, non-blocking systems capable of processing multiple sensor streams simultaneously. This is where advanced arduino code projects separate themselves from hobbyist toys, leveraging finite state machines, sensor fusion, and precise power management to navigate unpredictable environments.
In this guide, we will break down the exact hardware, software architecture, and edge-case troubleshooting required to build a sensor-fused autonomous navigation rover using the Arduino ecosystem.
Many legacy arduino code projects rely on the ATmega328P (Uno) or ATmega2560 (Mega). While excellent for learning, their limited SRAM and clock speeds become severe bottlenecks when running high-frequency PID loops, UART-based LiDAR parsing, and I2C multiplexing simultaneously. For a modern autonomous build, stepping up to a 32-bit ARM Cortex-M7 board is virtually mandatory.
For this build, we are utilizing the Arduino GIGA R1 WiFi . Its dual-core architecture allows us to offload high-speed sensor polling (like I2C Time-of-Flight arrays) to the M4 core, while the M7 core handles the primary navigation state machine and wireless telemetry. You can review the full hardware capabilities on the official GIGA R1 documentation page .
The most common failure mode in intermediate robotics builds is the blocking control loop. If your robot stops to scan the environment using a servo-mounted ultrasonic sensor, a blocking delay function halts all motor updates, encoder polling, and telemetry. This results in a robot that is blind and deaf to its own momentum while scanning.
To solve this, we implement a Finite State Machine. Instead of linear code, the robot transitions between discrete states based on environmental triggers. Our primary states include:
By relying on the Arduino millis function for time-tracking, we can execute the servo sweep incrementally. The code checks if a specific millisecond interval has passed, moves the servo one degree, updates the sensor reading, and immediately returns to the main loop to poll wheel encoders. This guarantees that motor PID updates occur every 10 milliseconds, regardless of the scanning state.
Ultrasonic sensors (like the HC-SR04) suffer from acoustic scattering and wide beam angles, making them unreliable for precise gap detection in cluttered environments. Modern robotics builds utilize a hybrid approach:
The VL53L1X sensors all share the same default I2C address (0x29). To use multiple sensors on the same bus, you have two options: sequentially change their addresses using the XSHUT pins during boot, or use an I2C multiplexer like the TCA9548A. For rapid development and robust isolation, the TCA9548A is preferred. It prevents SDA/SCL line capacitance issues from locking up the bus—a notorious edge case in robotics where long wiring runs introduce parasitic capacitance, causing I2C ACK failures and hard-locking the microcontroller.
A critical aspect often ignored in software-focused arduino code projects is power topology. A 4WD rover utilizing four 12V DC gearmotors can draw upwards of 8 Amps under stall conditions. If the logic circuit and the motor drivers share the same voltage regulator, the moment the motors engage, a massive voltage sag (brownout) will reset the Arduino GIGA, corrupting the I2C bus and wiping the SLAM memory.
We utilize a 3S LiPo battery (11.1V nominal, 12.6V fully charged) as the primary energy source. The power is split at the main distribution board:
Even with perfect code, hardware edge cases will disrupt autonomous navigation. Below is a diagnostic matrix for the most common failures encountered during field testing.
Building an autonomous rover requires a holistic approach that bridges mechanical design, electrical engineering, and advanced software architecture. By upgrading to a dual-core board like the GIGA R1 WiFi, implementing non-blocking finite state machines, and isolating your power rails, you elevate your build from a fragile prototype to a robust, field-ready machine. As you expand your arduino code projects portfolio, consider integrating micro-ROS (Robot Operating System) over WiFi to enable real-time SLAM (Simultaneous Localization and Mapping) visualization on a remote dashboard, pushing the boundaries of what is possible within the Arduino ecosystem.
Master advanced Arduino electronics projects with this step-by-step 4WD autonomous rover build. Includes wiring, sensor fusion, and PID tuning.
When evaluating advanced arduino electronics projects , the leap from simple line-followers to sensor-fused autonomous rovers requires a rigorous approach to power management, sensor fusion, and closed-loop control. In 2026, the availability of low-cost solid-state LiDAR and high-efficiency brushless motor drivers has completely transformed the hobbyist robotics landscape. However, the fundamental physics of power distribution and signal noise remain unchanged. This guide details the exact architecture, component selection, and failure-mode mitigation required to build a robust 4WD autonomous rover using the Arduino Mega 2560.
Selecting the right components is critical. Under-specifying your motor drivers or relying on the Arduino's onboard voltage regulator for logic power are the most common points of failure in intermediate arduino electronics projects . Below is the verified BOM for a high-torque, sensor-rich platform.
The most frequent cause of spontaneous resets in robotics builds is improper power routing. When four TT gearmotors start simultaneously, they can draw up to 1.2A each, creating a momentary 4.8A current spike. If you power the Arduino Mega via the VIN pin or the barrel jack using the main battery, this spike will cause the onboard linear regulator to overheat and drop the logic voltage below 4.5V, triggering a brownout reset.
Ultrasonic sensors (like the HC-SR04) are notorious for multipath errors and acoustic blindness outdoors. For a reliable 2026 rover, we use the TF-Luna LiDAR for forward obstacle detection and the MPU-6050 for dead-reckoning orientation.
Software serial is too slow and interrupt-heavy for 115200 baud LiDAR streams. Wire the TF-Luna TX to the Mega's RX1 (Pin 19) and RX to TX1 (Pin 18). Power the LiDAR from the Mega's 5V pin (it draws only 70mA).
The MPU-6050 communicates via I2C. In arduino electronics projects involving motors, the PWM signals and brushed motor EMI (Electromagnetic Interference) frequently corrupt I2C data lines, resulting in NACK errors and frozen code.
Open-loop PWM control is insufficient for autonomous navigation; battery voltage drop and terrain friction will cause the rover to drift. You must implement a PID (Proportional-Integral-Derivative) controller using encoder feedback.
While Texas Instruments' motor control literature heavily emphasizes digital signal processors for industrial PID, the Arduino Mega can comfortably handle a 50Hz PID loop for hobbyist rovers using the ArduinoPID library.
Even with perfect wiring, edge cases will emerge during field testing. Use this diagnostic matrix to resolve common anomalies found in complex arduino electronics projects .
Before deploying the rover outdoors, conduct a "tethered test." Elevate the chassis on blocks, connect the Arduino to your PC via USB (for serial debugging), and power the motors via the LiPo. Verify that the LiDAR distance readings stabilize within ±2cm and that the PID controller corrects wheel speed discrepancies within 200 milliseconds of a manual load disturbance.
By treating power distribution as a primary engineering constraint rather than an afterthought, you elevate your builds from fragile prototypes to robust, field-ready machines. For deeper insights into microcontroller pinout configurations and hardware serial limits, always consult the official Arduino Mega 2560 documentation before finalizing your PCB or perfboard layout.
Hardware Schematics & Pinout Diagrams
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Autonomous Charging Rover For Stored Evs In Underground Warehouses Controlled By Arduino... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |