Automated Pcb Solder Paste Thickness Laser Profiling Stage Driven By Arduino Stepper Motors
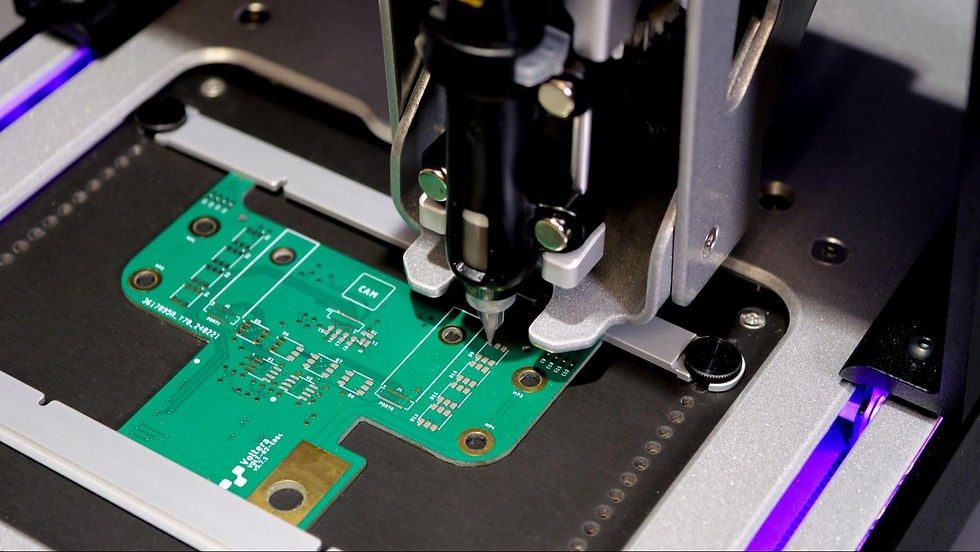
An automated SMD soldering system for precise solder paste dispensing and component placement on PCBs, developed as a Final Year Project.
The SMD Soldering System is an automated CNC-based setup that combines Arduino control, stepper motors, and computer vision to perform precise solder paste dispensing and SMD component placement on PCBs.
This system was developed for automated assembly of simple two-pad SMT components (resistors, capacitors) and is designed for development, prototyping, and educational purposes.
Note : This is an academic project developed for educational purposes. For commercial applications, please ensure compliance with safety standards and manufacturing regulations.
The SMD Soldering System is an automated setup developed as a Final Year Project (FYP) for precise solder paste dispensing and SMD component placement on PCBs.
This is home-made solder paste dispenser. Construction is printed on the 3D printer. The PCB is based on the basic connection of arduino nano with ULN2003 for stepper motor, and any button. The buttons are for controlling the direction of rotation of the stepper motor, and for changing the speed of rotation of the motor Mechanical material 3D printed PCB Stepper motor Schematic All project data with source code is on the my github repository.
The buttons are for controlling the direction of rotation of the stepper motor, and for changing the speed of rotation of the motor
Learn how to wire an Arduino with stepper motor driver modules like A4988 and DRV8825. Includes microstepping tables, Vref math, and AccelStepper code.
Integrating an Arduino with stepper motor driver modules is the foundational skill for building CNC routers, 3D printers, and automated camera sliders. Unlike standard DC motors, stepper motors move in discrete increments, allowing for sub-millimeter positional accuracy. However, an Arduino's GPIO pins cannot supply the current or voltage required to drive these motors directly. This is where dedicated chopper drivers like the A4988 and DRV8825 come into play.
In this comprehensive 2026 wiring and code guide, we will cover the exact hardware specifications, the critical Vref current-limiting calibration, microstepping configurations, and non-blocking code implementation using the AccelStepper library.
Before wiring, you must select the right components. While clone boards flood the market, understanding the difference between genuine and cloned silicon is vital for thermal reliability.
Both drivers share the exact same pinout and form factor, but their internal silicon differs. According to the Texas Instruments DRV8825 Datasheet , the DRV8825 supports finer microstepping and slightly higher current limits, but it is more susceptible to voltage spikes.
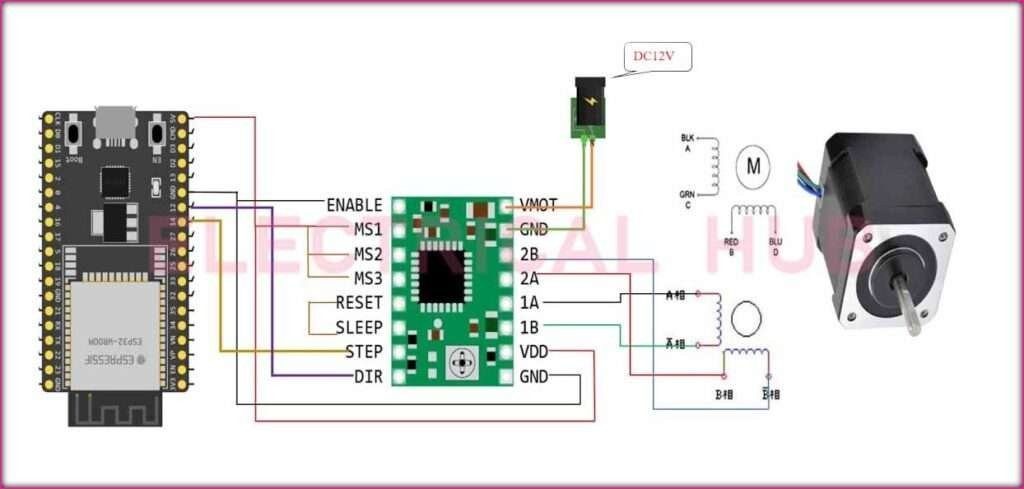
Wiring an Arduino with stepper motor driver modules requires separating the logic voltage (VDD) from the motor voltage (VMOT). The A4988/DRV8825 breakout boards have two distinct ground planes that are tied together on the PCB, but you must route power correctly.
NEMA 17 motors have two coils (A and B), resulting in 4 wires. You must pair them correctly. If you wire Coil A to 1A and Coil B to 2A, the motor will vibrate violently without rotating. Use a multimeter in continuity mode: wires that show low resistance (typically 1.5Ω to 3.0Ω) belong to the same coil. Connect Coil A to 1A and 1B, and Coil B to 2A and 2B. Polarity within the same coil does not matter for basic operation; swapping 1A and 1B simply reverses the motor's direction.
The most common failure mode for beginners is skipping the Vref calibration, resulting in melted driver chips or skipped steps. You must adjust the small brass potentiometer on the driver board to limit the current to your motor's rated maximum.
Warning: Never adjust the potentiometer while the logic power (VDD) is disconnected. The chip needs 5V logic to read the reference voltage accurately.
The formula depends on the driver IC and the sense resistor (Rs) value printed on the board.
Example for a 1.5A NEMA 17 motor using a DRV8825 with a 0.1Ω sense resistor: Vref = 1.5A × 5 × 0.1Ω = 0.75V .
Connect your multimeter's black probe to the Arduino GND and the red probe to the metal shaft of the potentiometer. Use a ceramic screwdriver to turn the pot clockwise to increase voltage, and counter-clockwise to decrease it. Set it exactly to your calculated Vref.
Microstepping divides a full step (usually 1.8°, or 200 steps/rev) into smaller fractions, resulting in smoother motion and less low-speed resonance. You configure this by pulling the MS1, MS2, and MS3 pins HIGH (connected to VDD) or LOW (connected to GND).
Pro-Tip: For 3D printers and CNCs, 1/16 microstepping is the industry standard. It provides the best balance between torque consistency and MCU step-pulse limitations.
While the default Arduino Stepper.h library works for basic tests, it uses blocking delay functions that freeze your entire sketch. For real-world applications, we use the AccelStepper Library , which handles acceleration profiles and non-blocking step generation.
Install 'AccelStepper' by Mike McCauley via the Arduino Library Manager. Below is the optimized code for a 1/16 microstepped NEMA 17 motor.
In the code above, setMaxSpeed(1600) limits the motor to 1600 steps per second. Because we are using 1/16 microstepping (3200 steps per revolution), the motor will max out at exactly 0.5 Revolutions Per Second (30 RPM). The setAcceleration(800) value dictates how many steps per second, per second, the motor gains. This prevents the rotor from stalling due to inertia during startup.
Even with perfect wiring, environmental and electrical factors can cause erratic behavior. Here is how to diagnose the most common issues:
By meticulously calculating your Vref, utilizing low-ESR decoupling capacitors, and leveraging non-blocking acceleration libraries, your Arduino with stepper motor driver setup will achieve the reliability required for professional-grade automation and robotics.
🚀 Automating Soldering: My Custom PCB Soldering Machine Project As an electronics hardware design engineer, I often find repetitive tasks like manual soldering to be time-consuming and prone to inconsistency. To solve this, I developed a DIY soldering assistant machine that automates the soldering process using a molten solder pot and a motorized PCB tray—all powered by Arduino with 100% custom code (no external libraries). 🔧 Key Features: ✅ Molten Solder Pot: At the heart of the machine is a heating element that keeps the solder pot at the perfect temperature to ensure reliable and clean solder joints. ✅ Motorized PCB Tray: A tray holds the PCB and is driven by a stepper motor. The tray moves smoothly up and down using acceleration and deceleration control to prevent solder splashes and mechanical stress. ✅ Controlled Dipping Cycle: 1. When activated, the tray gently lowers the PCB into the molten solder. 2. Holds it for 5 seconds to ensure proper soldering. 3. Raises the PCB back up and waits in a holding position. 4. Once the soldered PCB is removed and a new one is placed, a button press restarts the cycle. ✅ Code-Driven Precision: The machine is entirely controlled by an Arduino, with the stepper motor logic (including acceleration & deceleration) written from scratch—no libraries used. This allowed me full control over the motion profile, timing, and responsiveness. 🎯 Why I Built It: 1. To speed up the through-hole soldering process for small-to-medium production batches. 2. To reduce operator fatigue and the risk of inconsistent solder joints. 3. To experiment with motion control and embedded systems in a real-world application. 💬 Let’s Connect! I’m passionate about designing embedded solutions that bridge the gap between manual processes and smart automation. If you're working on similar automation or embedded projects, I’d love to connect and exchange ideas.
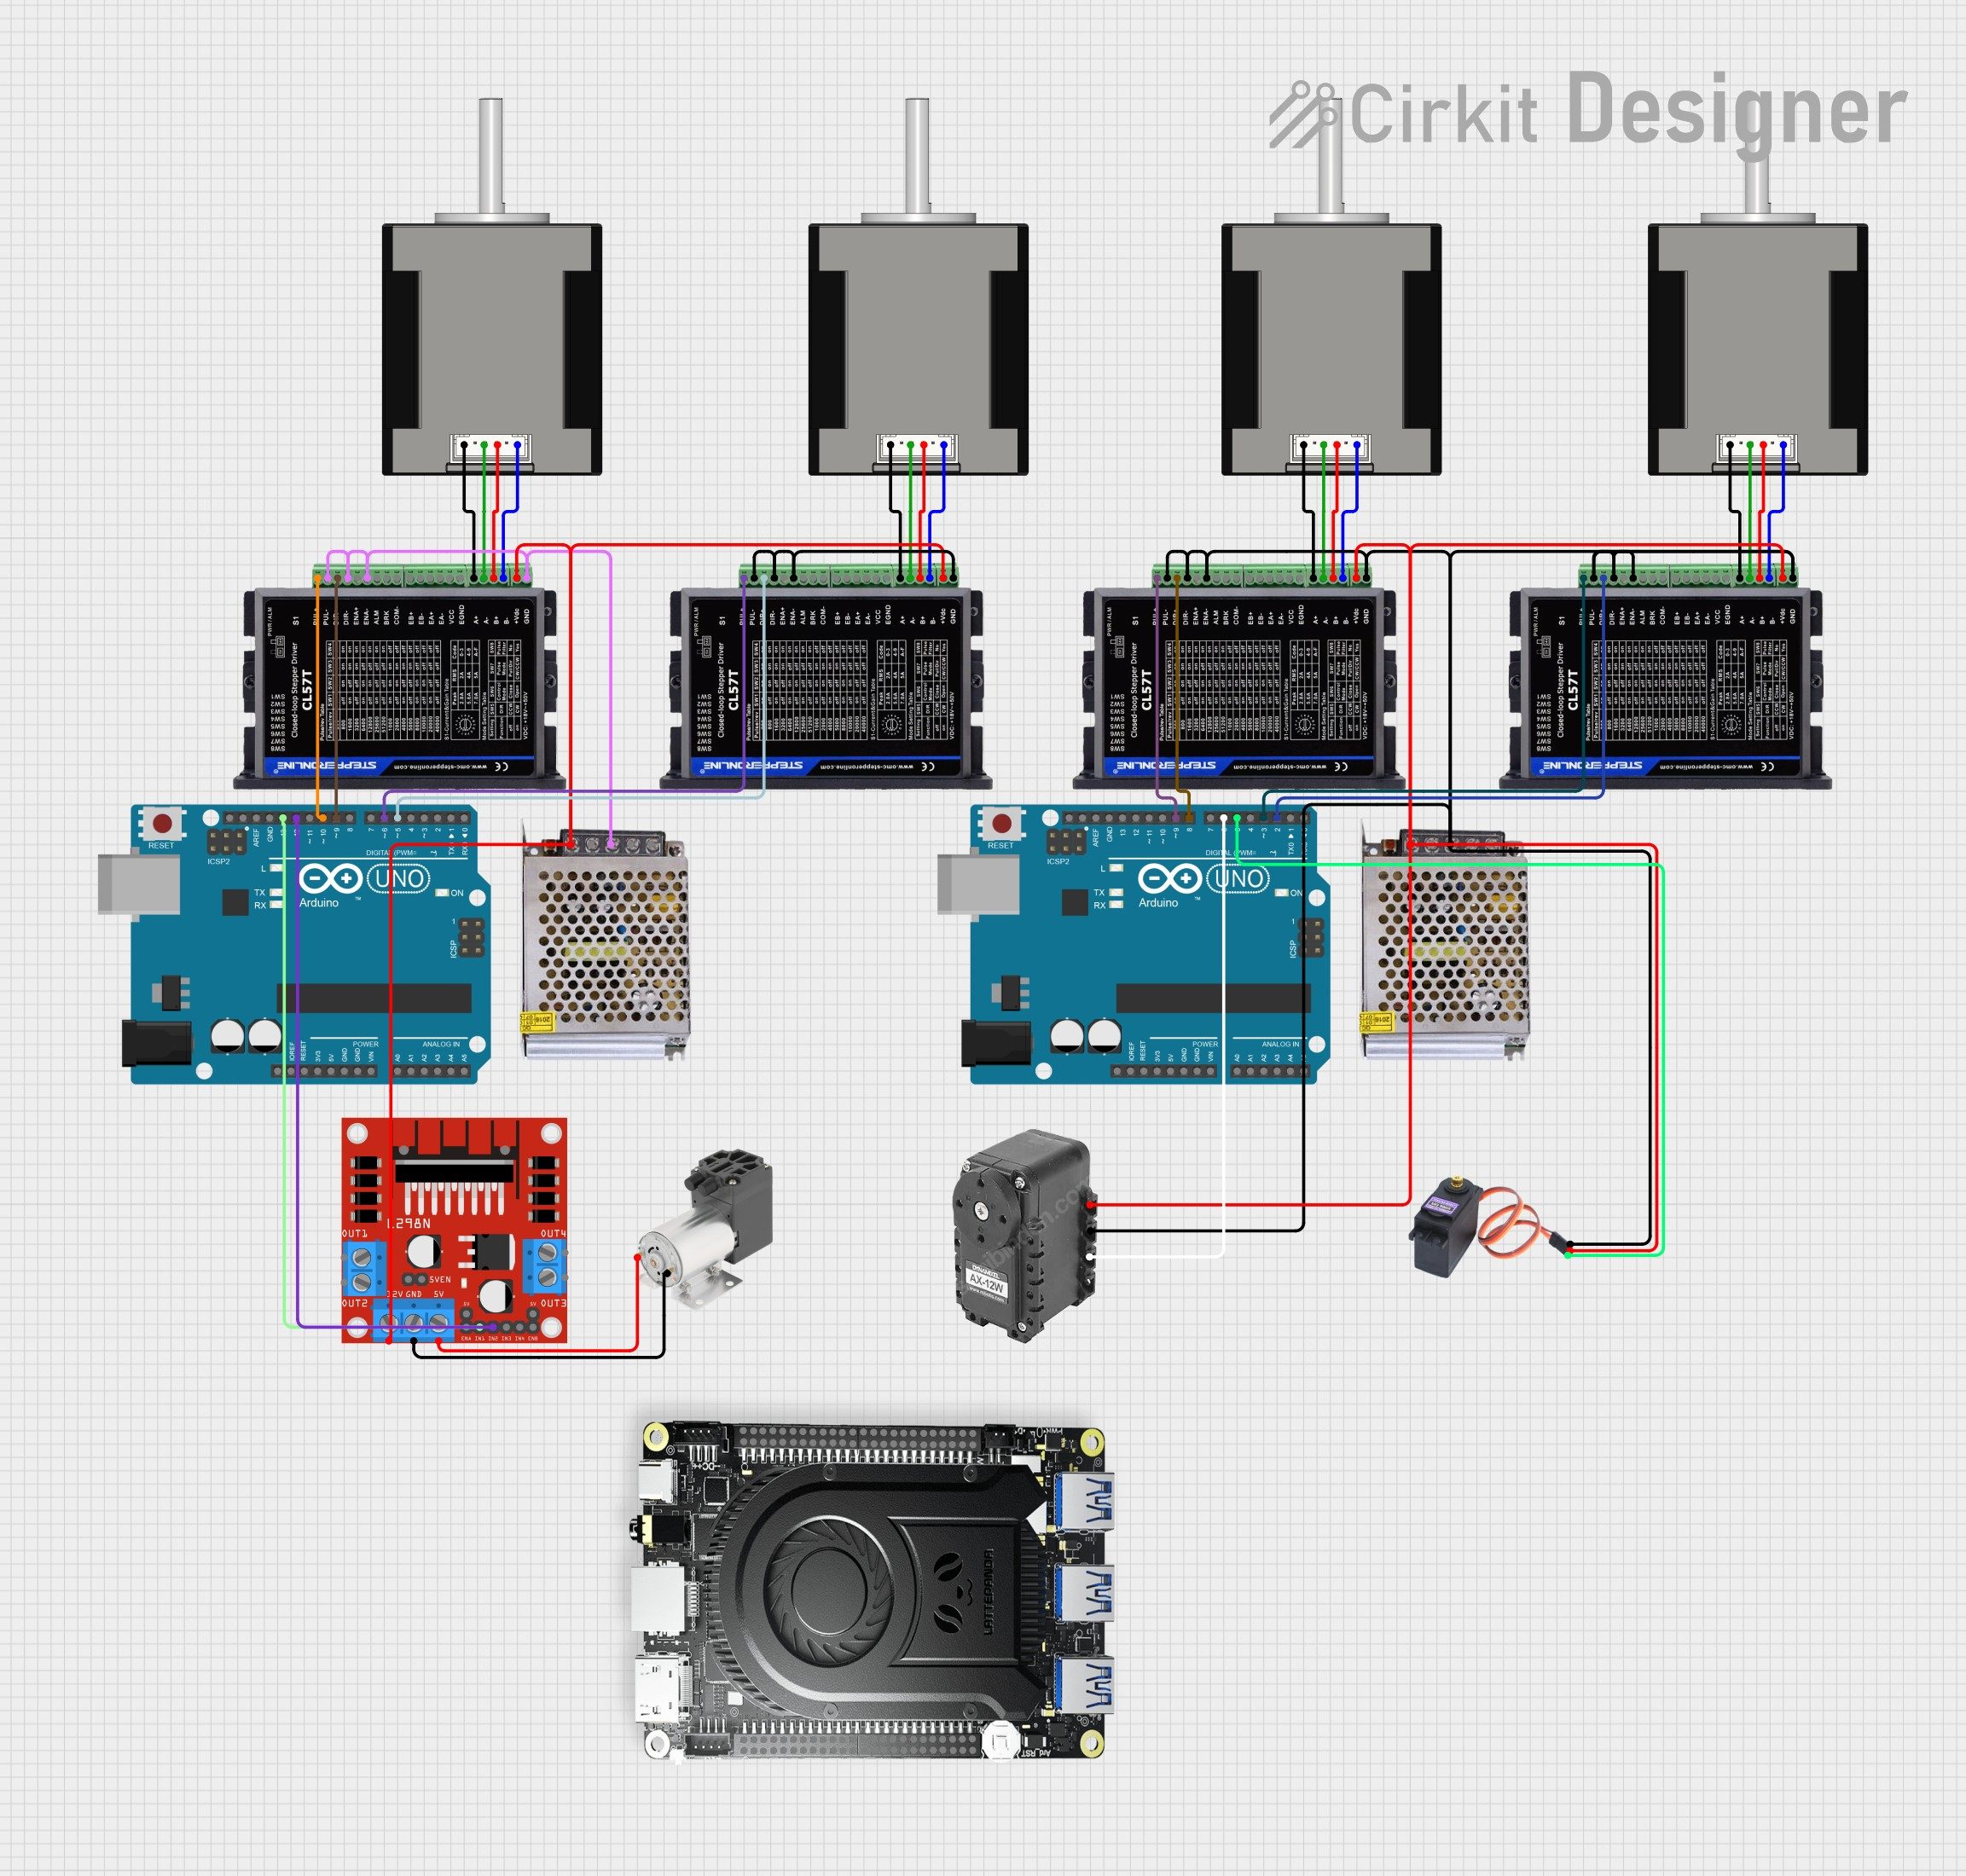
The system is a two-channel solder paste and glue dispenser. The dispenser circuit uses a 220V-to-5V / 1A SMPS as its power supply. It includes an Arduino Pro Mini 328 16MHz / 5V, two stepper motor drivers and an SH1106 / I2C display powered through a 5V-to-3.3V supply.
The MC14490P is used to suppress contact bounce from the rotary encoder and to monitor the dispensing pedal buttons. The circuit draws no more than 170mA from the 5V supply.
The operating principle of the circuit is simple. According to the specified parameters, presets and selected operating modes, the controller generates the signals required for the step count, rotation direction and channel selection.
The two-channel structure allows different materials or syringe sizes to be controlled without changing the main controller. Solder paste, flux and adhesive require different dispensing times because their viscosity and flow characteristics are not identical.
The step count determines the amount delivered, while motor direction can be used to relieve pressure after each dose and reduce dripping. Before production use, each channel should be calibrated with the installed syringe, needle and material.
Hardware Schematics & Pinout Diagrams
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Automated Pcb Solder Paste Thickness Laser Profiling Stage Driven By Arduino Stepper Motors... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |