Atmospheric Inversion Layer Sounder Using Temperature Profile Drone Probe Driven By Arduino
inversiontools is a set of functions for identifying and characterizing temperature inversions from radiosonde profile data. Temperature inversions are defined a variety of ways in meteorology and climate science. The functions here are designed to recreate common methods for quantifying temperature inversions while allowing customization (important especially for analyzing sensitivity of parameter choices).
Although the functions will work on any Pandas dataframe with columns for temperature, pressure, and height, I have designed the code with the Siphon library in mind, which has tools for importing radiosonde profiles from the IGRA2 archive and from the University of Wyoming archive.
Beginning at the surface, each temperature profile is scanned upward to locate the first layer in which the temperature increases with altitude. The bottom of this layer identifies the inversion base. The inversion top is defined as the bottom of the first subsequent layer in which the temperature decreases with altitude. Thin negative-lapse layers (<100 m) are ignored if they are embedded within a deeper inversion layer.
Reference: Kahl, J. D. (1990). Characteristics of the low-level temperature inversion along the Alaskan Arctic coast. International Journal of Climatology, 10, 237–548.
Lower tropospheric stability is a bulk estimate of stability used in tropical stratocumulus cloud research and in Arctic atmospheric boundary layer research. In Arctic ABL research it is often defined as the temperature difference between the 850 mb and 1000 mb pressure levels, although using 925 mb for the upper level and/or using 2-m air temperature for the lower level are not uncommon. Another variant is to use potential temperature rather than dry-bulb temperature; potential temperature differences are more important for potential for buoyant mixing.
Mostly used in studies using ground stations, e.g. paired rooftop and surface station, towers, or paired valley/ridge stations.
Defined by Milionis and Davies as the depth-weighted average difference in potential temperature across all inversion levels in a sounding.
Used in Connoley's analysis of surface inversions in Antarctica. First identify the height of the temperature maximum, then average those heights over a month. That results in the inversion depth, and the difference between average maximum temperature and the average surface temperature is the inversion strength.
Official websites use .gov A .gov website belongs to an official government organization in the United States.
Secure .gov websites use HTTPS A lock ( Lock Locked padlock icon ) or https:// means you've safely connected to the .gov website. Share sensitive information only on official, secure websites.
Received 2024 Jan 2; Revised 2024 Feb 26; Accepted 2024 Mar 4; Collection date 2024 Mar.
Measurements of the vertical structure of the lower atmosphere are important to the understanding of air quality. Unmanned Aerial Systems (UASs, drones) can provide low cost, repeatable measurements of the temperature, pressure, and relative humidity. A set of inexpensive sensors controlled with an Arduino microprocessor board were tested on a UAS against a meteorology grade sensor. Two modes of operation for sampling were tested: a forward moving sampler and a vertical ascent sampler. A small particle sensor (Sensiron SPS30) was integrated and was capable of retrieving vertical aerosol distributions during an inversion event. The thermocouple-based temperature probe and the relative humidity measurement on the Bosch BME280 sensor correlated well with the meteorological sensor. The temperature and relative humidity sensors were then deployed on a rocket sounding platform. The rocket sounding system performed well up to a height of 400 m. The inexpensive sensors were found to perform adequately for low-cost development and uses in education and research.
Keywords: sonde measurements, rocketsonde, UAS, drone, atmospheric measurements, atmospheric chemistry
The horizontal and vertical distribution of pollutants and their evolution in time impact the understanding and risks associated with air quality. Air quality impacts human health as well as visibility [ 1 , 2 ]. Meteorology often impacts the severity of air pollution exposure due to stagnant air masses (inversions) or low horizontal or vertical mixing [ 3 ]. Understanding the boundary layer height and other meteorological variables is valuable in understanding the evolution of the tropospheric boundary layer [ 4 ]. Trace gas and aerosol concentrations may also vary with altitude depending on the extent or lack of vertical mixing. Typical boundary layer evolution includes a shallow limited boundary layer at night, with the boundary layer expanding as the sun rises and heats air near the surface causing the warm air to rise, mixing the air vertically as it does so [ 5 , 6 ]. The cooling warm air parcels rising from the surface are described by the dry adiabatic lapse rate (−0.0065 Km −1 or roughly a drop of 1 °C per 100 m of altitude gained).
A variety of methods exist for sampling meteorological as well as air pollutant variables’ vertical profiles including radiosonde balloons [ 7 ], tall towers [ 8 ], aircraft [ 9 ], small Unmanned Aerial Systems (sUASs, UASs, drones, unmanned aerial vehicles (UAVs)), and rocket-based sounding systems. The most common method of meteorological sounding is radiosondes which are utilized by many national weather forecasting offices as well as airports to gather data that is fed into numerical weather models [ 10 , 11 , 12 ]. There are a number of commercial options for radiosondes including Vaisaila (Vaisaila Corporation, Helsinki, Finland), iMET (International Met Systems, Grand Rapids, MI, USA), and GRAW (GRAW Radiosondes, Germany) [ 13 ]. Radiosonde payloads typically weigh 120 g and are lifted by a helium balloon to altitudes of at least 6000 m (20,000 feet) depending on the size of the balloon and amount of helium added.
Meteorological sounding by rockets (rocketsondes) has been utilized in the past for lower and upper stratospheric atmospheric monitoring [ 14 , 15 , 16 , 17 ]. Most current rocket sounding relates to the probing of the upper atmosphere [ 16 , 18 , 19 ]. Rockets provide a simple way to access higher portions of the atmosphere. Considering flight restrictions and differing rules for rocketry, rocket platforms are a possible area of interest in expanding lower atmosphere sounding technology. While conventional radiosondes use helium balloons for lift, rockets use conventional propellants. Commercial options for rocketsondes for the lower atmosphere appear to no longer be available, though they appear to have been available in the past. Within the United States of America, model rockets (Class 1) are classified as those that use no more than 125 g of slow burning propellant, are made of paper, wood, or breakable plastic, contain no substantial metal parts, and weigh no more than 1500 g completed. Class 1 model rockets require no notification of air traffic control and no height limit (other than that the rocket not become orbital) in the rules, but are limited by the logistical recovery area and other safety concerns specific to the launch [ 20 ].
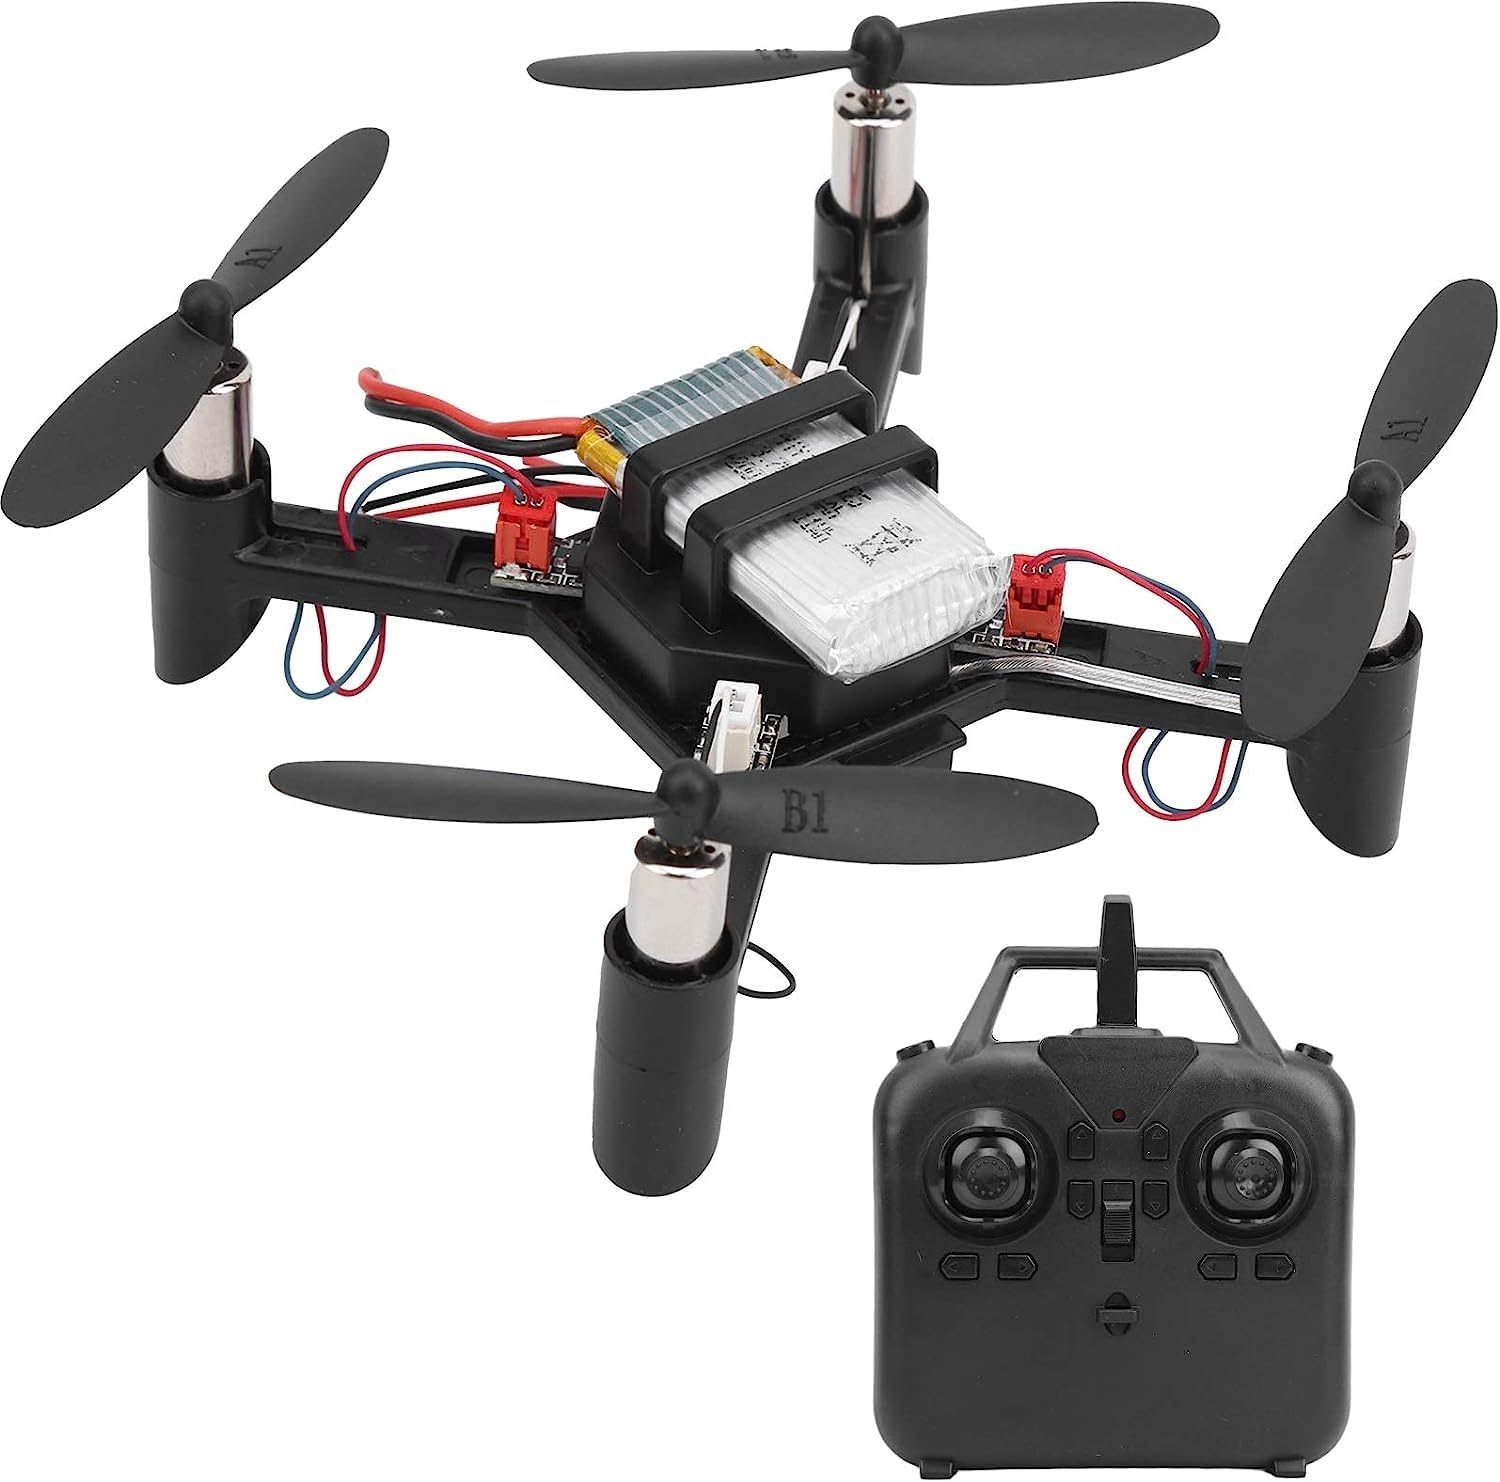
The use of RC aircraft has long been suggested as a way to perform meteorological measurements, dating back to the 1970s [ 21 ]. More recently, UASs have been explored and evaluated as viable platforms for lower atmospheric measurements [ 22 ] including the use of UASs for systematic meteorological sounding [ 23 ]. Several sUAS platforms for meteorological sounding have been reported more recently in the literature [ 24 , 25 , 26 , 27 , 28 , 29 , 30 , 31 , 32 , 33 , 34 , 35 ]. Likely the most developed of these is the CopterSonde [ 27 ] which has a highly integrated measurement system with custom firmware and telemetry for reporting data back to the ground station in real time, as well as integrated software that keeps the sUAS pointed into the wind and reports wind speed and direction based on the inertial measurement unit feedback with an aspirated, shielded set of sensors. It has recently been made available as a commercial system ( https://www.intermetsystems.com/products/coptersonde/ , accessed on 15 December 2023). Other UAS systems have been developed and tested for measuring a variety of other species such as volatile organic carbon compounds [ 36 , 37 , 38 , 39 , 40 , 41 ], nitrogen and sulfur oxides [ 41 , 42 ], particulate matter [ 41 , 43 , 44 , 45 , 46 , 47 , 48 ], and ozone [ 46 , 49 , 50 ]. These systems have varied from lower-end instrumentation to high-end research grade instrumentation. Previous works have utilized the Arduino platform for meteorological measurements on sUASs [ 30 , 51 ]. These platforms include both rotary-wing (helicopters and multi-rotors) and fixed-wing aircraft. For sampling, multi-rotors have the advantage in small flight footprints and the ability to ascend and descend easily, along with more simple, easy to use control systems. Fixed-wing UASs typically have longer flight times and distances, sometimes up to or longer than 2 h, which allows for easier horizontal spatial sampling, as well as a variety of fuel types that allow for even longer flight times [ 44 ]. Another recent report, for example, detailed a fixed-wing sUAS capable of profiling the atmosphere to a 10 km altitude with a battery powered aircraft [ 24 ]. There are also commercial add-on systems for meteorology such as the iMET XQ2 which integrates temperature and relative humidity measurements with pressure and geolocation (GPS) data in an integrated package [ 52 , 53 , 54 , 55 ]. This package provides a bead thermistor, and calibrated temperature and relative humidity measurements in a package that is a standalone system.
Hardware Schematics & Pinout Diagrams
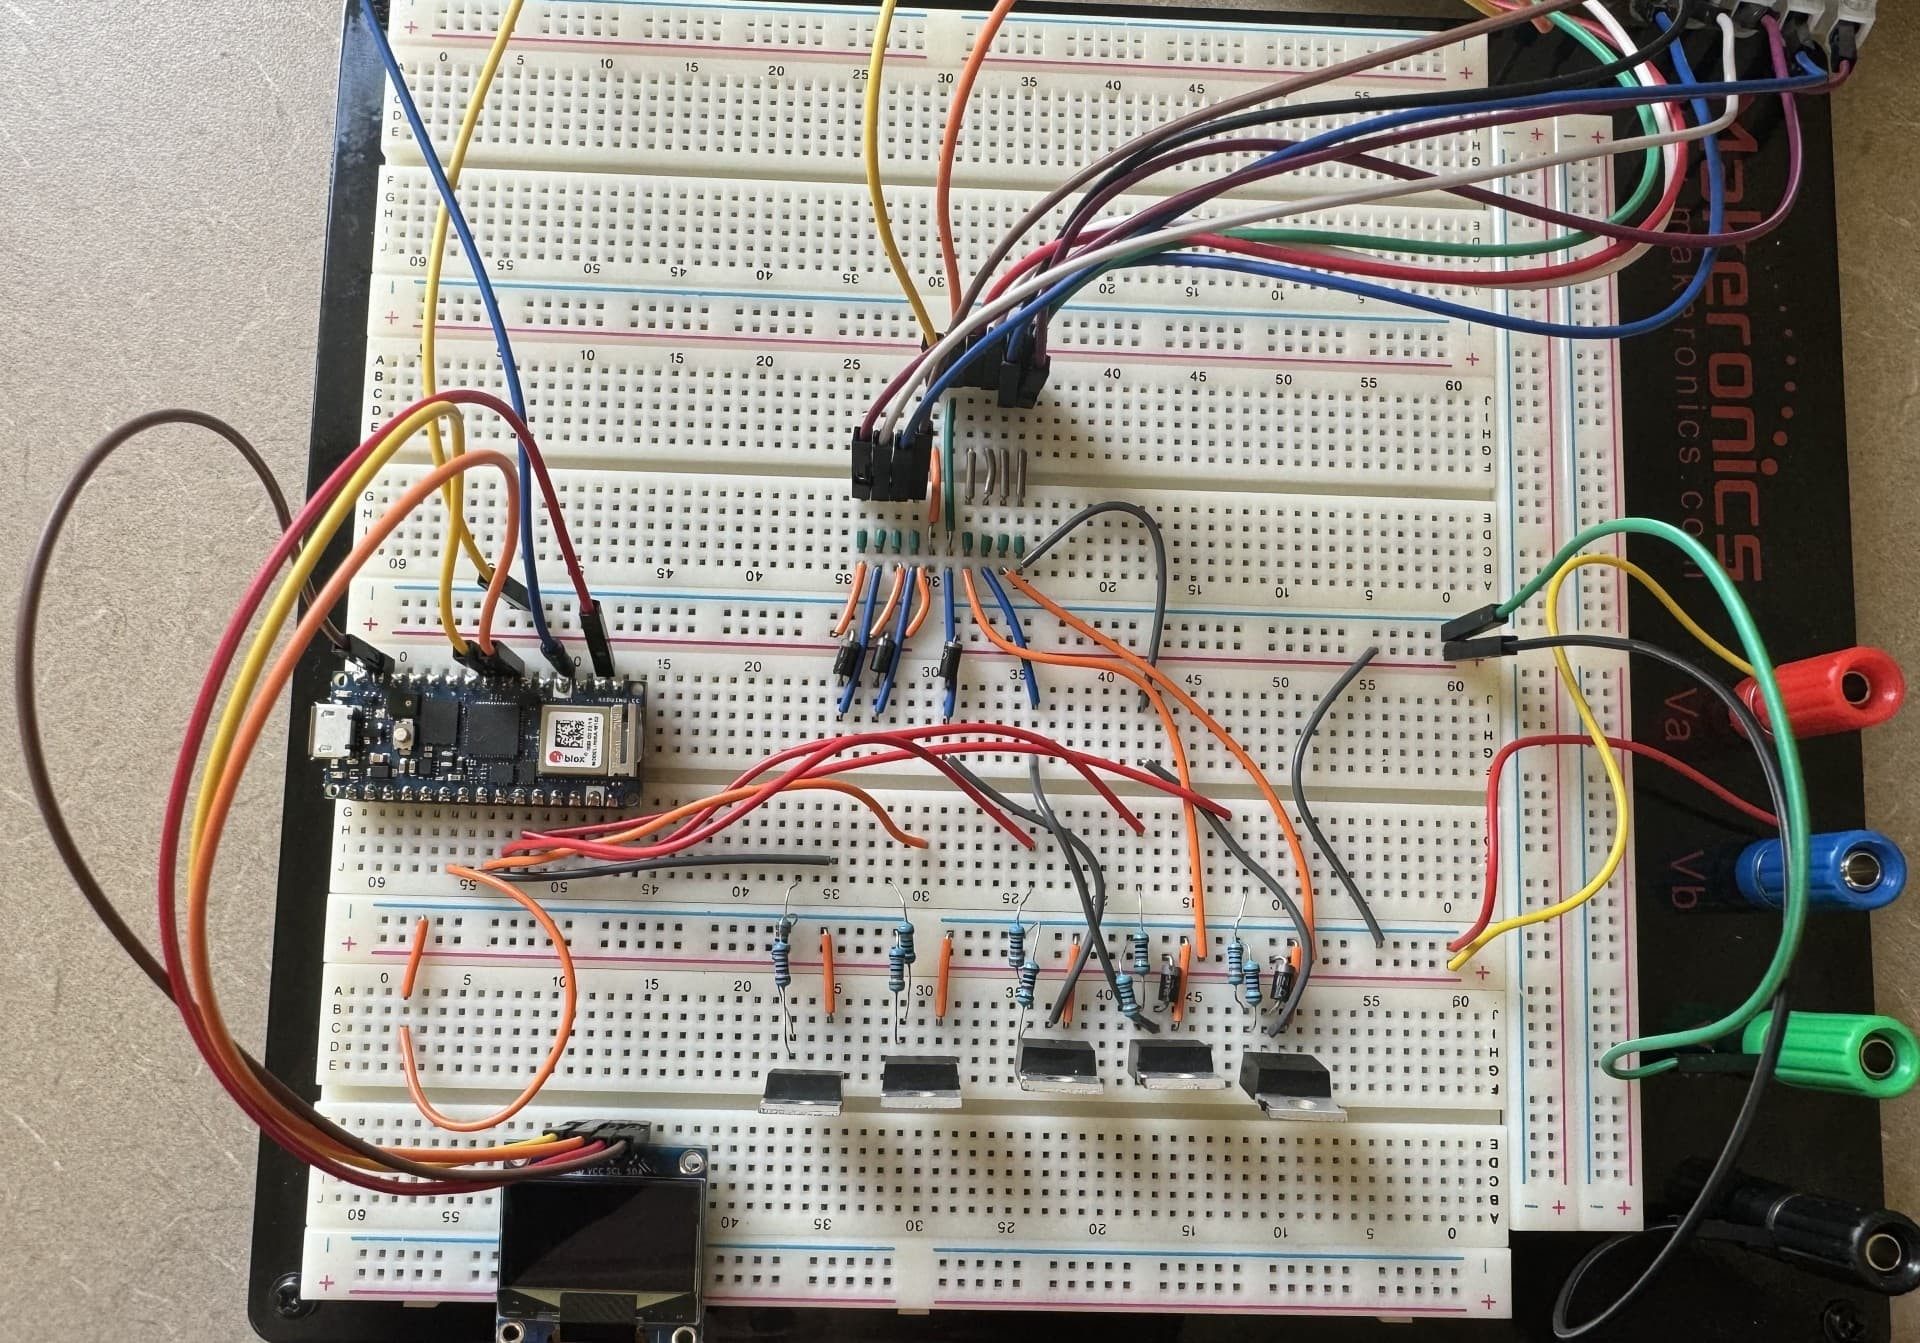
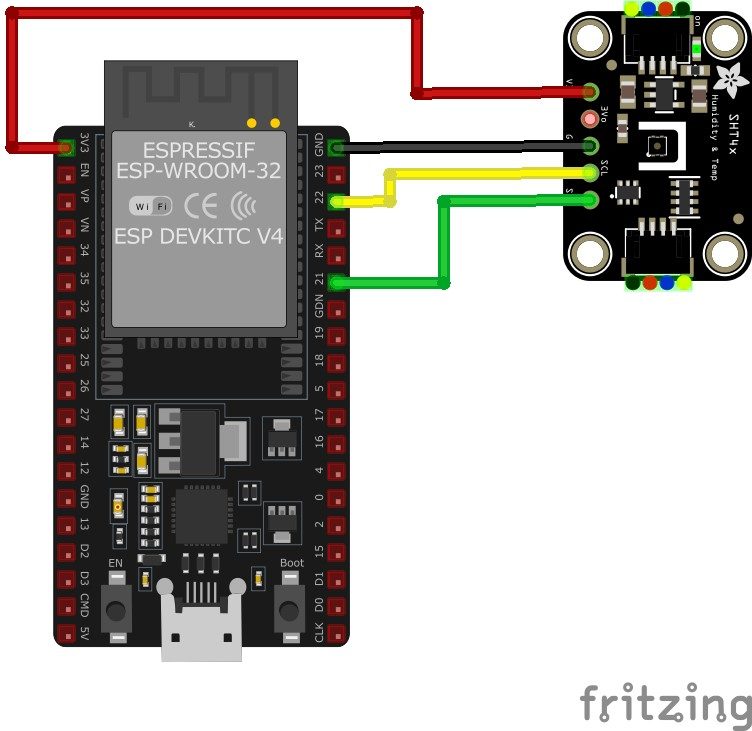
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Atmospheric Inversion Layer Sounder Using Temperature Profile Drone Probe Driven By Arduino... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |