Arduino Controlled Anti Collision Ultrasonic Warning System For High Density Marine Waterways
Arduino is an open-source electronics platform based on easy-to-use hardware and software. Arduino boards can read digital & analog inputs from the sensors and the HR SC-04 Ultrasonic sensor uses sonar to find the distance between objects. It can measure distances ranging from 2cm to 400cm with an accuracy of 0.3cm. Collision detector is a valuable system and finds great application in the automobile industry. It is used to avoid accidents and in self-driving cars.
In this article, We will learn how we can make a Smart Collision Detector using Arduino. When the distance between two objects is less than 20cm Red LED will glow and the buzzer will start. A step-by-step explanation of the project is given with the program to execute this. (Design is also included.)
In this circuit, the HR SC-04 Ultrasonic sensor detects the time the wave takes to hit and reach the sensor again i.e from the trig pin to the echo pin and sends the value to the Arduino, which converts the time into distance using the speed formula. This value is compared to a safe distance; if the distance is between 50cm and 20cm, the blue light will be illuminated. Otherwise, if the distance is below 20cm, the red light will be illuminated and the buzzer starts to ring.
Divide by 2, since the time is recorded for both to and fro i.e, before & after hitting the object
We have used Tinkercad to create this simulation - You can create an account(Google, Autodesk, email) and use Tinkercad for free.
You can also run the simulation using the project. After opening the project hit Simulate button and click Start Simulation to execute this project.
Hardware Schematics & Pinout Diagrams
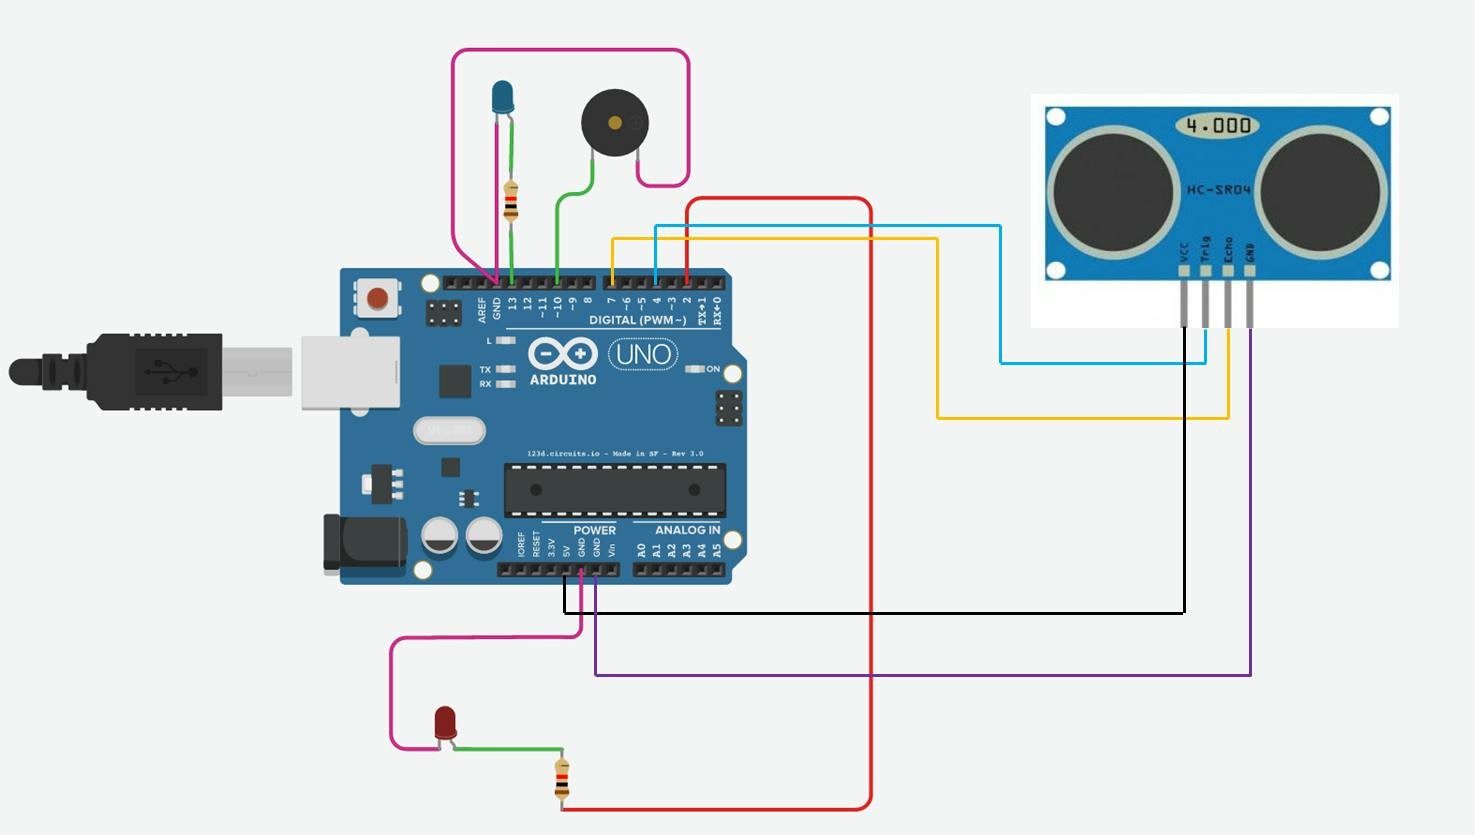
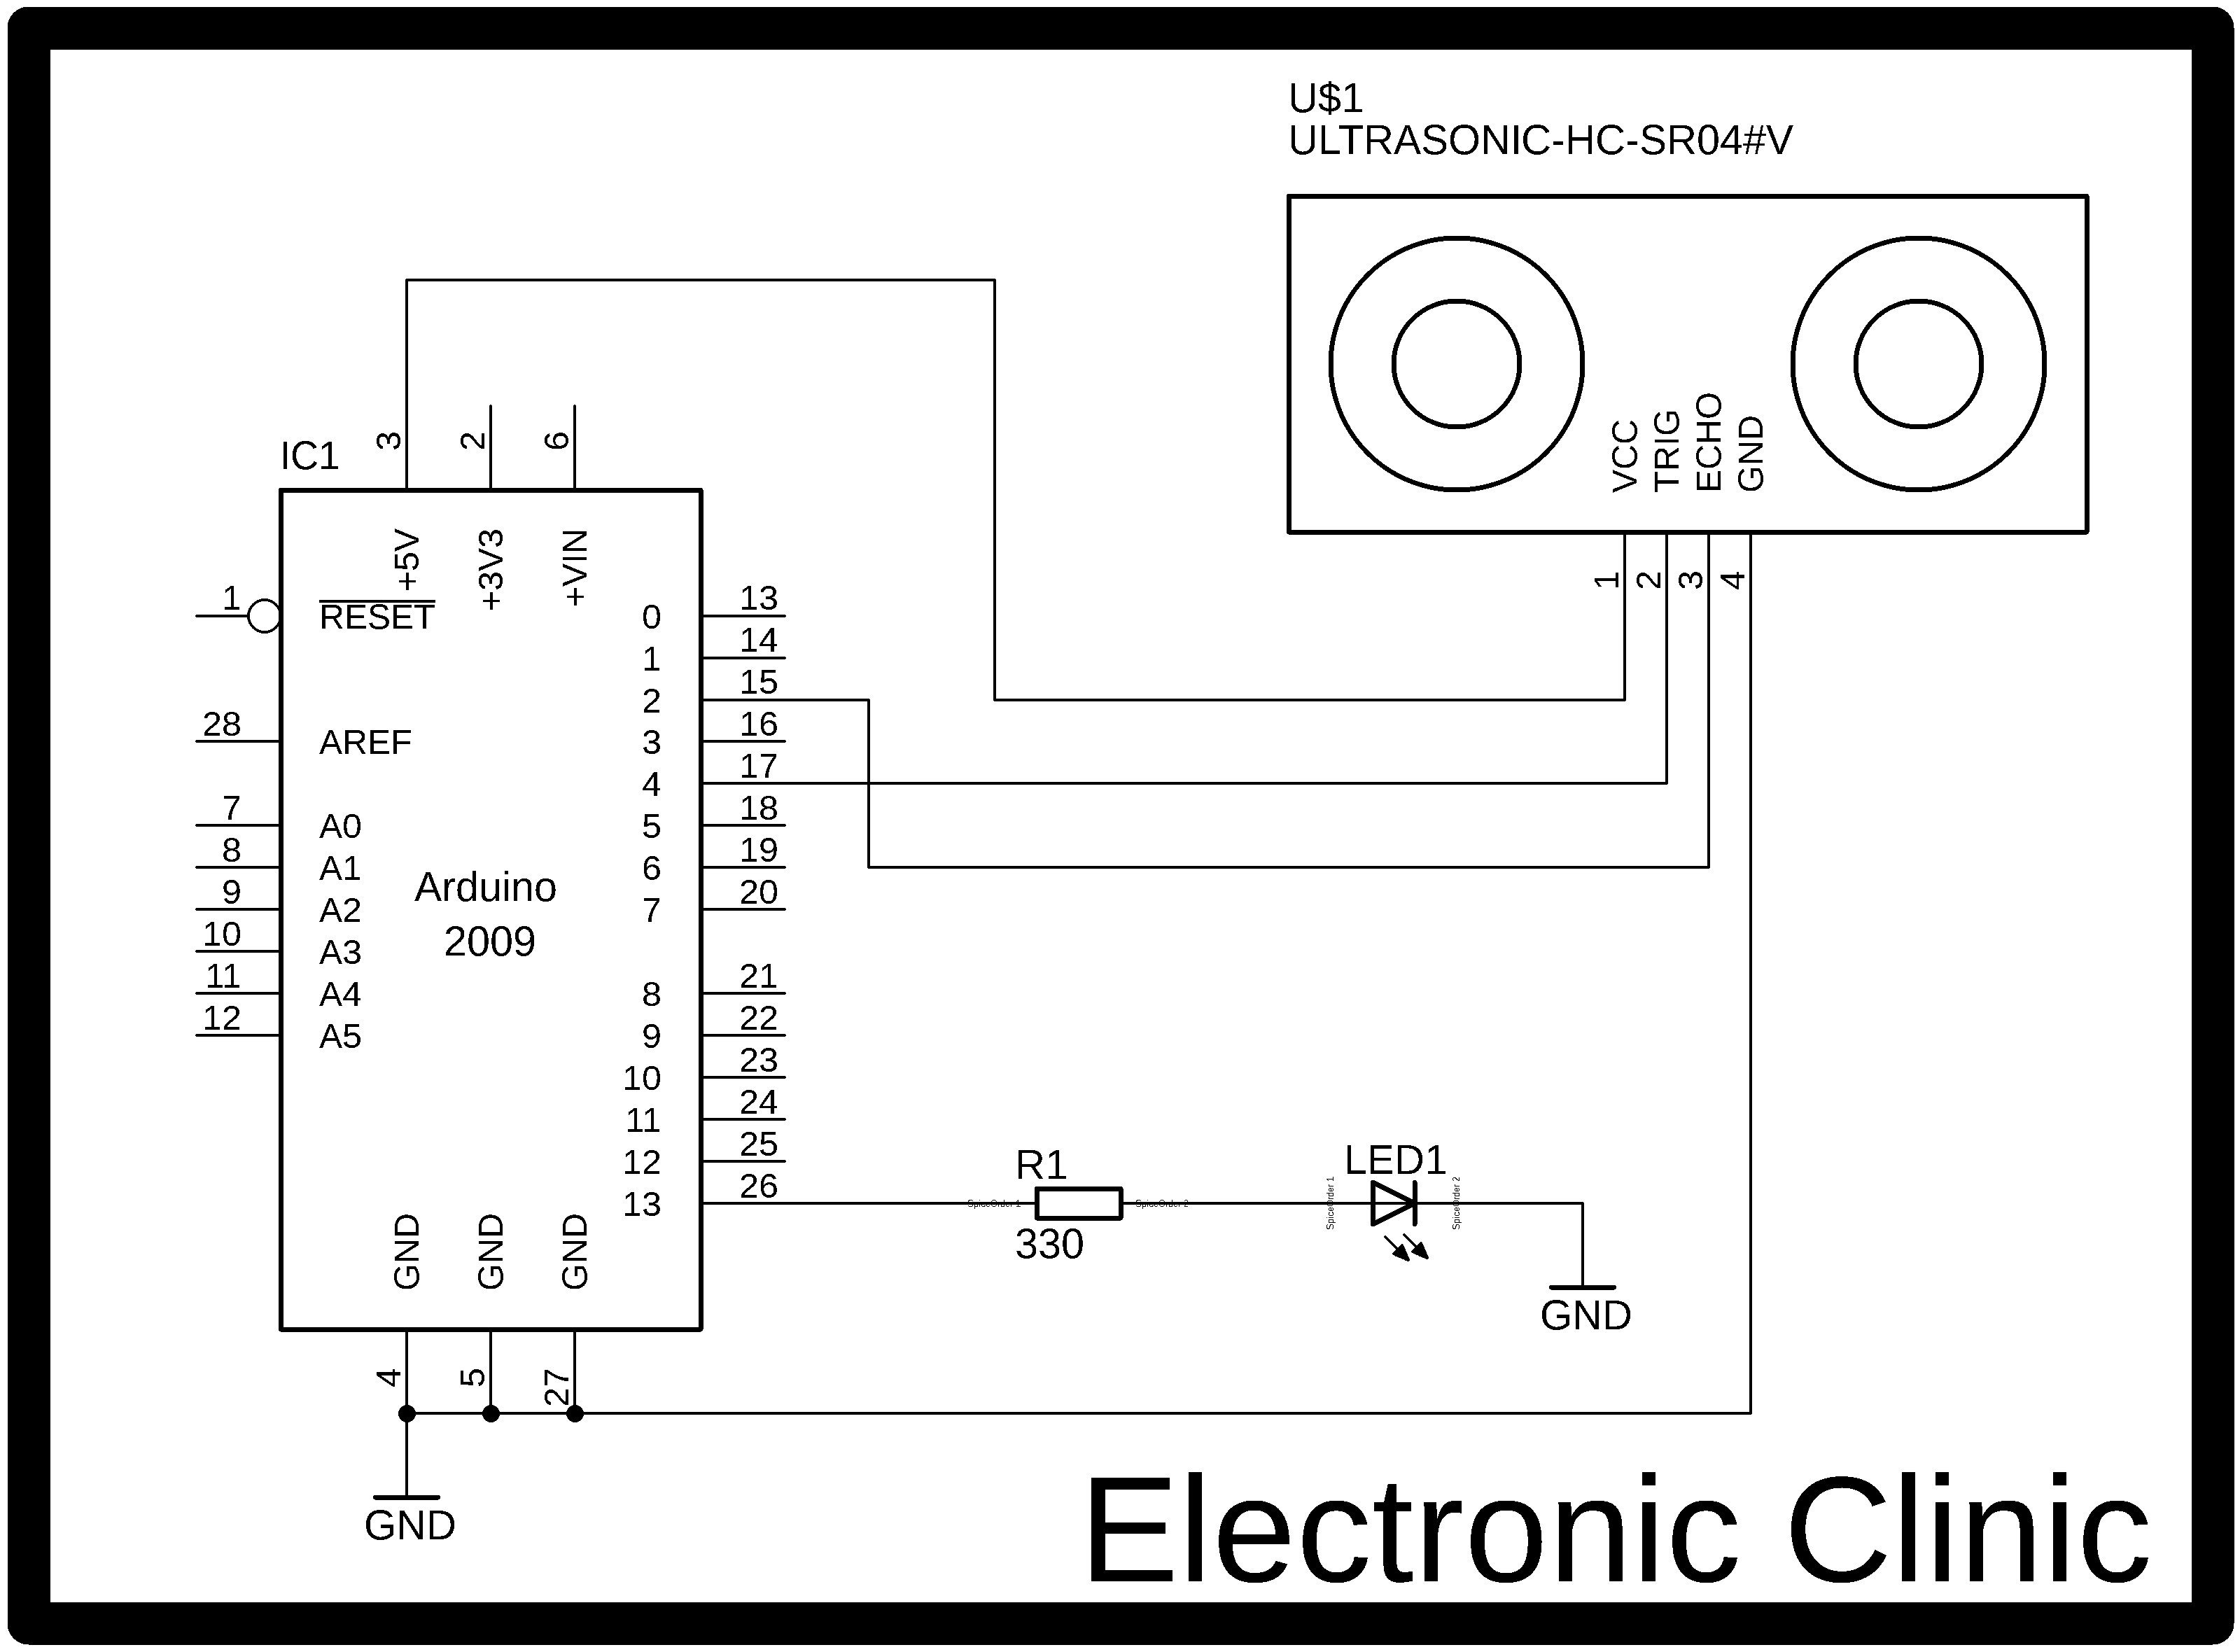
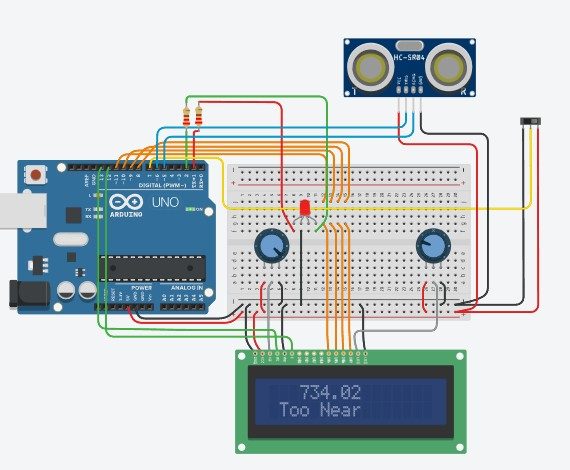
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Arduino Controlled Anti Collision Ultrasonic Warning System For High Density Marine Waterways... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |