Arduino Controlled Active Aerodynamic Tail Spoiler For High Speed Ev Drag Reduction
Sometimes a great hack is great for no other reason than that it’s fun , and [Michael Rechtin]’s DIY Active Aero Spoiler and Air Brake certainly qualifies as a fun hack. This is a mod designed to live in a world where looks are everything, stickers add horsepower, and a good sound system is more important than good wheel alignment. Why is that? Because like the switch that exists only to activate the mechanism that turns it off, the DIY Active Aero Spoiler and Air Brake seen below is almost completely useless. So to understand its allure, we must understand its inspiration.
For a few decades now, luxury sports car manufacturers have been adding active aerodynamic components to their vehicles. For example, several Porsche models feature adaptive spoilers that adjust to driving conditions. Super cars such as the Bugatti Veyron have spoilers that flip up at high angles during braking to increase drag and reduce braking distance. All of these features are sadly missing from the average two or four door family-car-turned-wannabe-track-fiend. Until now!
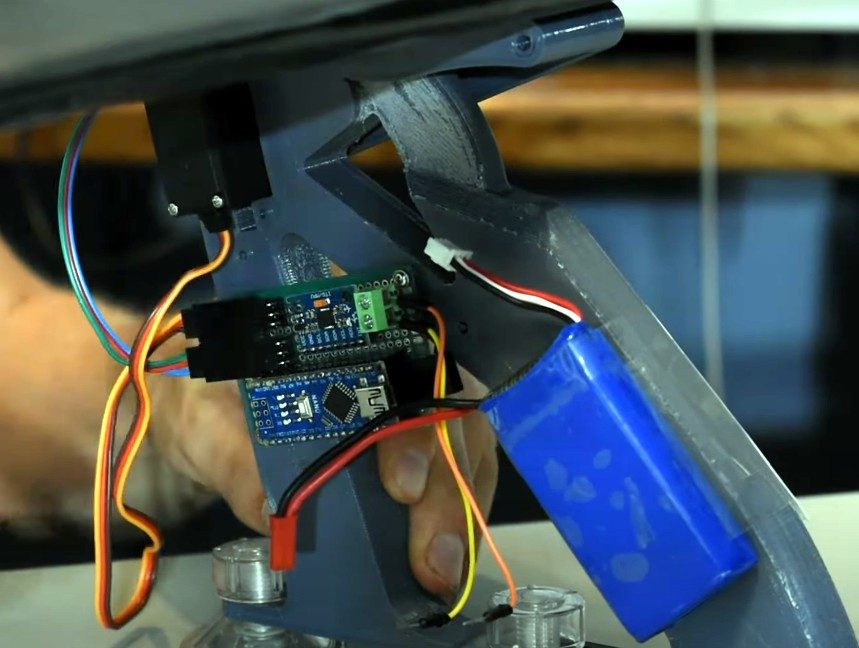
[Michael] has created a new active spoiler for every mall-bound muffler-challenged hand me down. The build starts with a CNC cut foam wing which is covered with fiberglass, Bondo (an automotive necessity ) and some faux carbon fiber for that go-fast feel. An Arduino, IMU, two servos, and a battery pack detect deceleration and automatically increase the spoiler angle just like the big boys, but without needing any integration into the vehicles systems. Or bolts, for that matter.
It’s unlikely that the braking force is enough to slow down the vehicle though, given that it’s not enough to pop the suction cups holding it to the trunk lid. But does it have the “wow” factor that it was designed to induce? Spoiler Alert: It does!
As it turns out, this isn’t the first adjustable spoiler featured here at Hackaday, and this adjustable spoiler on a car that’s made for actual racing is quite interesting.
Suction cups, seriously? Sorry but it’s super unsafe, imagine driving behind him on a motorway and this thing detaches and hits your windshield at 70mph.
Think his demos were a little slower than that and didn’t get the impression he was going to leave it on the car.
And, umm, not convinced many of the guys who make their cars go faster with stickers and an “improved” filter drive as slow as 70. But they would be brave enough to use bolts to ++ruin their cars, so it would all be OK. At least till it rains and the Arduino shorts.
This was a pretty neat project. A few measurements of downforce using some load cells would be interesting.
My car doesn’t need any extra drag. It’s a mini, which to my eyes seems to have all the aero of a mildly rounded brick. Hoping to fix that by getting a Landover which doesn’t go fast enough to suffer drag:)
It will be a reliable vehicle for at least 3 months. 2 minimum before ‘zero drag’ is achieved. Assuming you buy it brand new.
Are their lazy way of mounting toy servos directly on the axis being able to handle the braking force?
I think he’d get better braking performance by painting the calipers red. The acceleration has been taken care of by the Mazda ads that say ‘zoom-zoom’.
This is cool! I made a similar project for my senior design project in college.
Please be kind and respectful to help make the comments section excellent. ( Comment Policy )
Car spoilers can provide downforce for better performance, or simply give the appearance of speed. To take things to another level, Michael Rechtin designed his own custom wing that doesn’t just sit there, but pitches up and down via a pair of servos.
The system utilizes an Arduino Nano along with an MPU-6050 for control, adjusting itself based on his Mazda’s movement, and powered is supplied by a LiPo battery. Suction cups are used to attach the spoiler, so installation appears to require no actual modification of the car whatsoever.
As far as performance goes, Rechtin notes that it’s just for fun — likely wreaking havoc on your gas mileage!
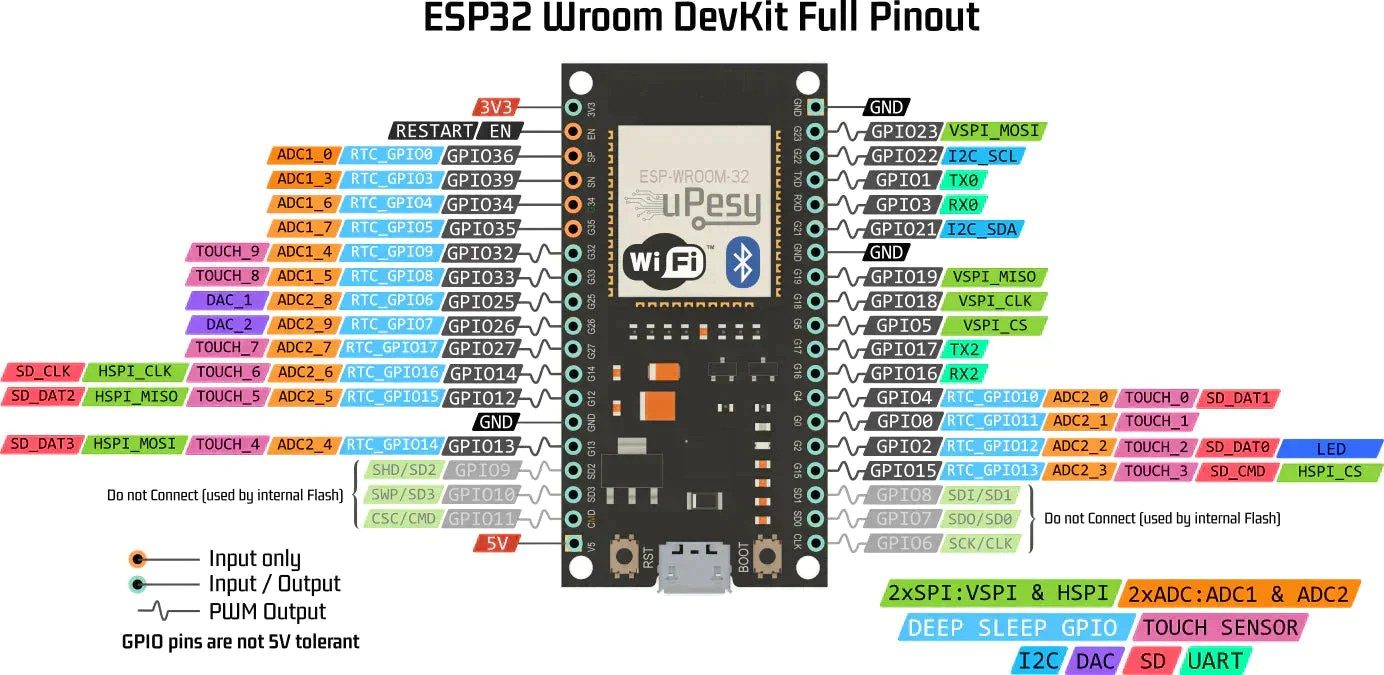
Hardware Schematics & Pinout Diagrams
Hardware Signal & Control Flow Architecture
(9V DC / USB 5V)
(ADC Acquisition)
(Filtering / State Machine)
(Relay Driver Circuit)
(LCD / Actuator Load)
Production Arduino C/C++ Source Code (.ino)
[*] Initializing Hardware Core for Arduino Controlled Active Aerodynamic Tail Spoiler For High Speed Ev Drag Reduction... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
| Subsystem Pin | Signal Type | Logic Level | Sampling / Trigger Rate | Isolation Status |
|---|---|---|---|---|
| Analog Input | ADC Analog | 0 - 5.0V / 3.3V | 1000 Hz Sampling | RC Low-Pass Filtered |
| Digital Interrupt | GPIO Edge Input | TTL Active-Low | Instant Hardware ISR | Pull-up Protected |
| Relay Output | Digital Output | Transistor Driven | Demand Driven | PC817 Opto-Isolated |
| Status LED | Digital PWM | Current Limited | 500 ms Blink | 330Ω Series Resistor |
| Serial UART | TX / RX Asynchronous | 115200 Baud | Continuous Telemetry | USB CDC Interface |