WhatsApp Us
⚡ Arduino Uno · ESP32 · Embedded C/C++ (.ino) · IoT System · 2026

Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming

4569
Verified Words
3
Hardware Figures
4.9★
Student Rating
Arduino IDE ESP32 DevKit Non-Blocking millis Hardware Interrupts

Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming

ESC Calibration Risk : The system performs automatic ESC calibration on startup by sending maximum throttle signals. NEVER run this code with propellers attached! ESCs that don't properly detect the calibration sequence may interpret this as full throttle commands, causing the drone to take off uncontrollably.

No Safety Features : This system lacks essential safety features found in commercial flight controllers (arming switches, failsafes, motor kill switches, etc.).

Research Prototype : This code was developed for academic research and testing. It requires modification and thorough testing before use on any drone.

You assume all risks when using this code. The author is not responsible for any damage, injury, or loss.

A complete quadcopter/drone flight control system implemented on Arduino, featuring advanced sensor fusion, PID control algorithms, and multiple flight modes. This project was developed as part of a master's thesis on UAV control systems.

This flight control system implements a cascaded PID control architecture for quadcopter stabilization and navigation. The system integrates multiple sensors including IMU (MPU-9255) and barometric pressure sensor (BMP280) to provide robust attitude estimation and altitude control.

🚨 DANGER : ESC calibration sends maximum throttle signals that can cause motors to spin at full speed!

CRITICAL SAFETY REQUIREMENT : REMOVE ALL PROPELLERS before performing ESC calibration. ESCs that don't properly detect calibration signals may spin motors at 100% throttle.

The system performs automatic ESC calibration on EVERY boot when DEBUGGING_MODE is disabled:

We welcome contributions! This project is open source and we encourage community involvement. Here's how you can contribute:

This project is licensed under the MIT License - see the LICENSE file for details.

If you use this code in your research or project, please cite the original master's thesis:

Always fly in designated areas, maintain visual contact, and be prepared for immediate emergency cutoff. Never fly over people or property.

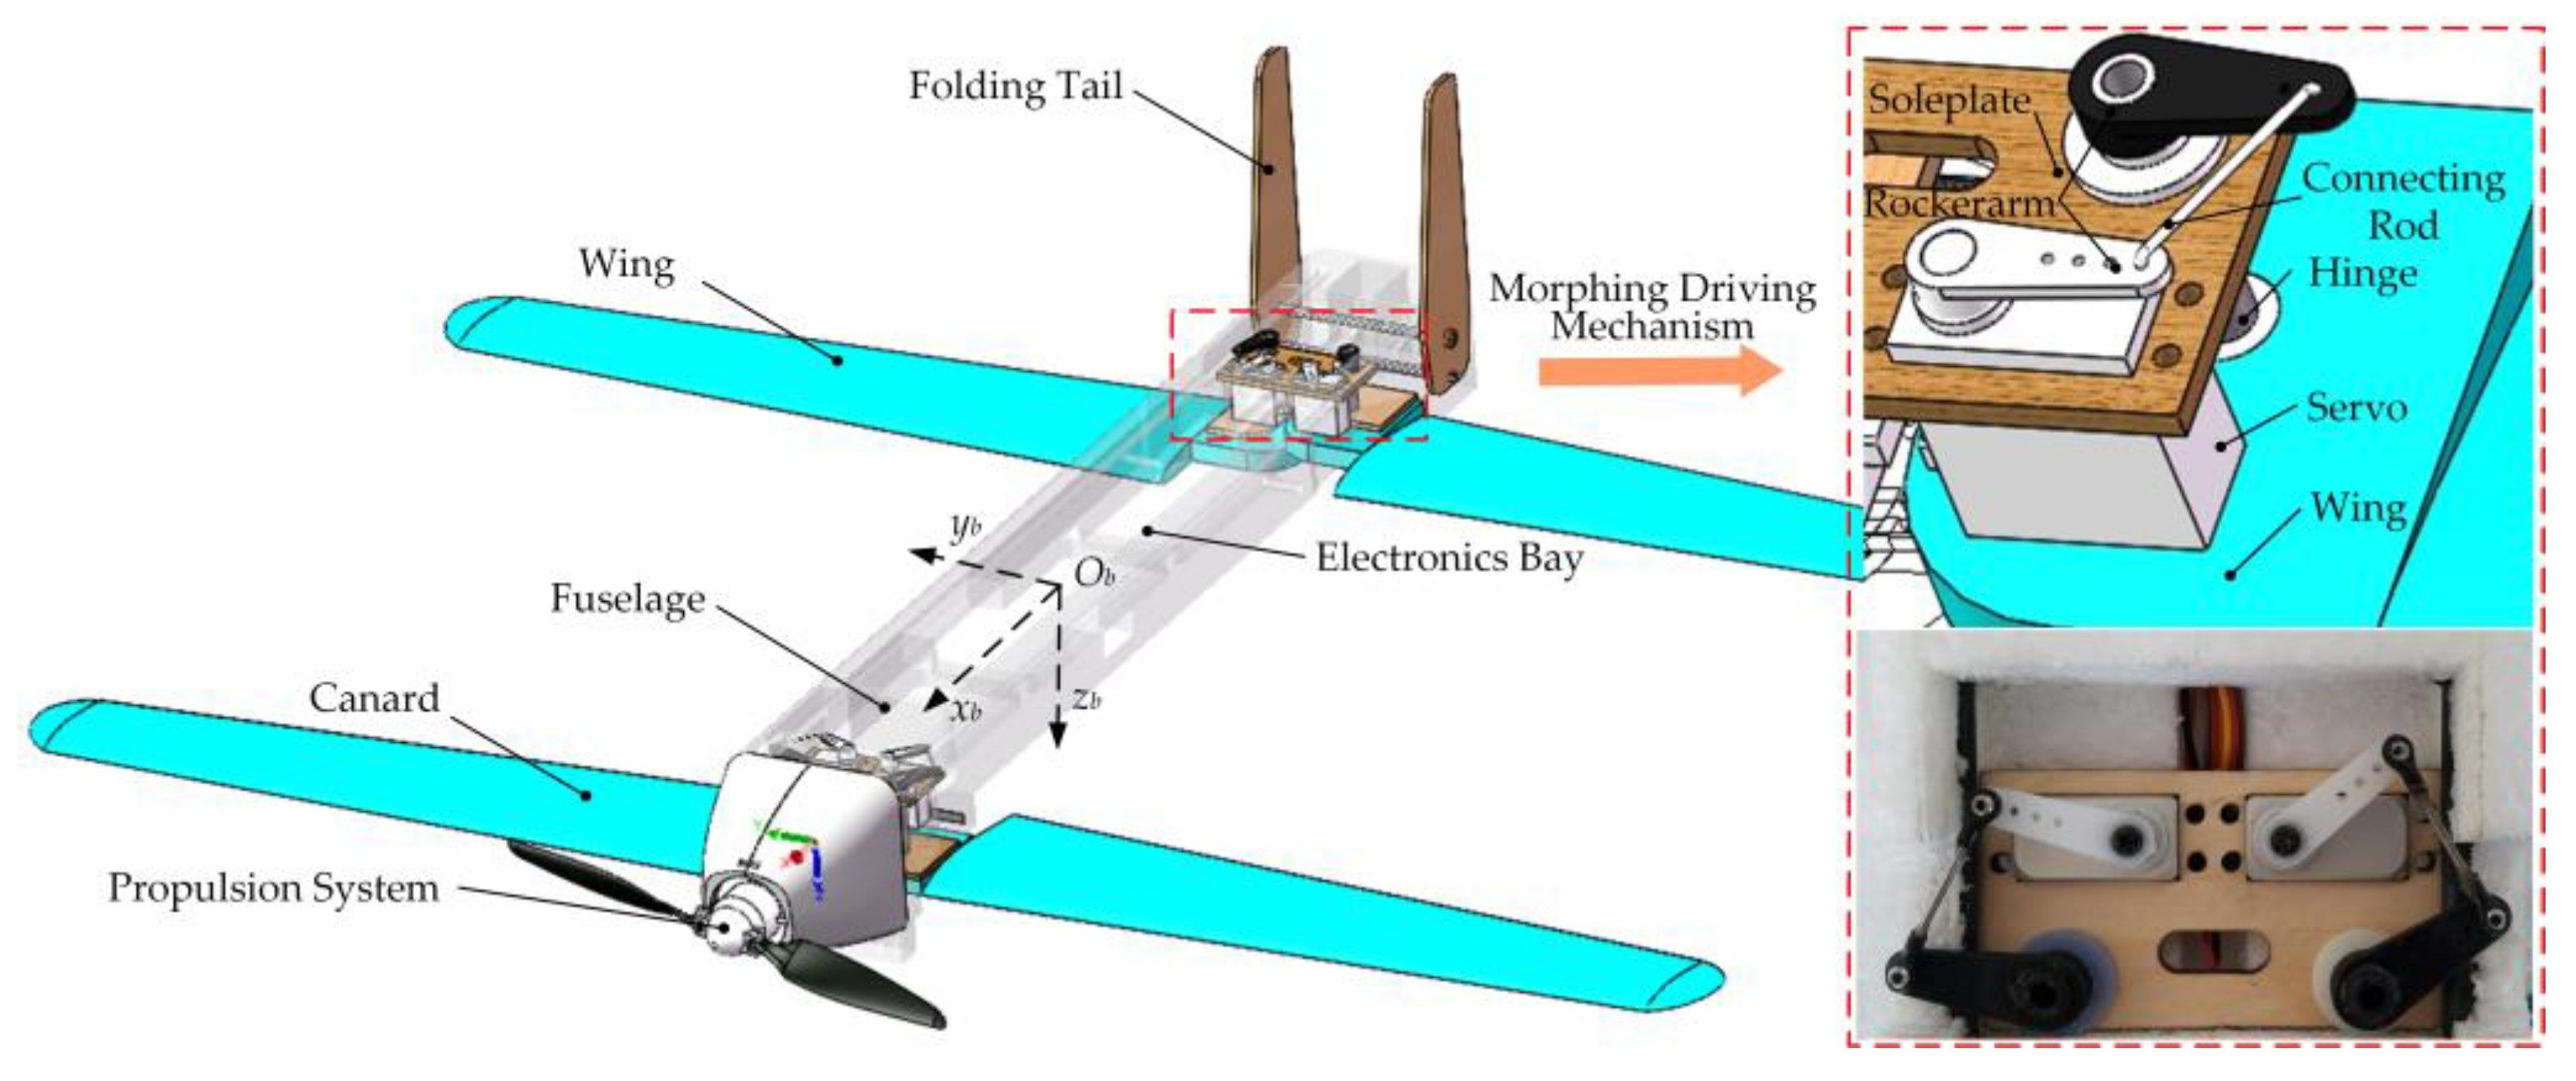
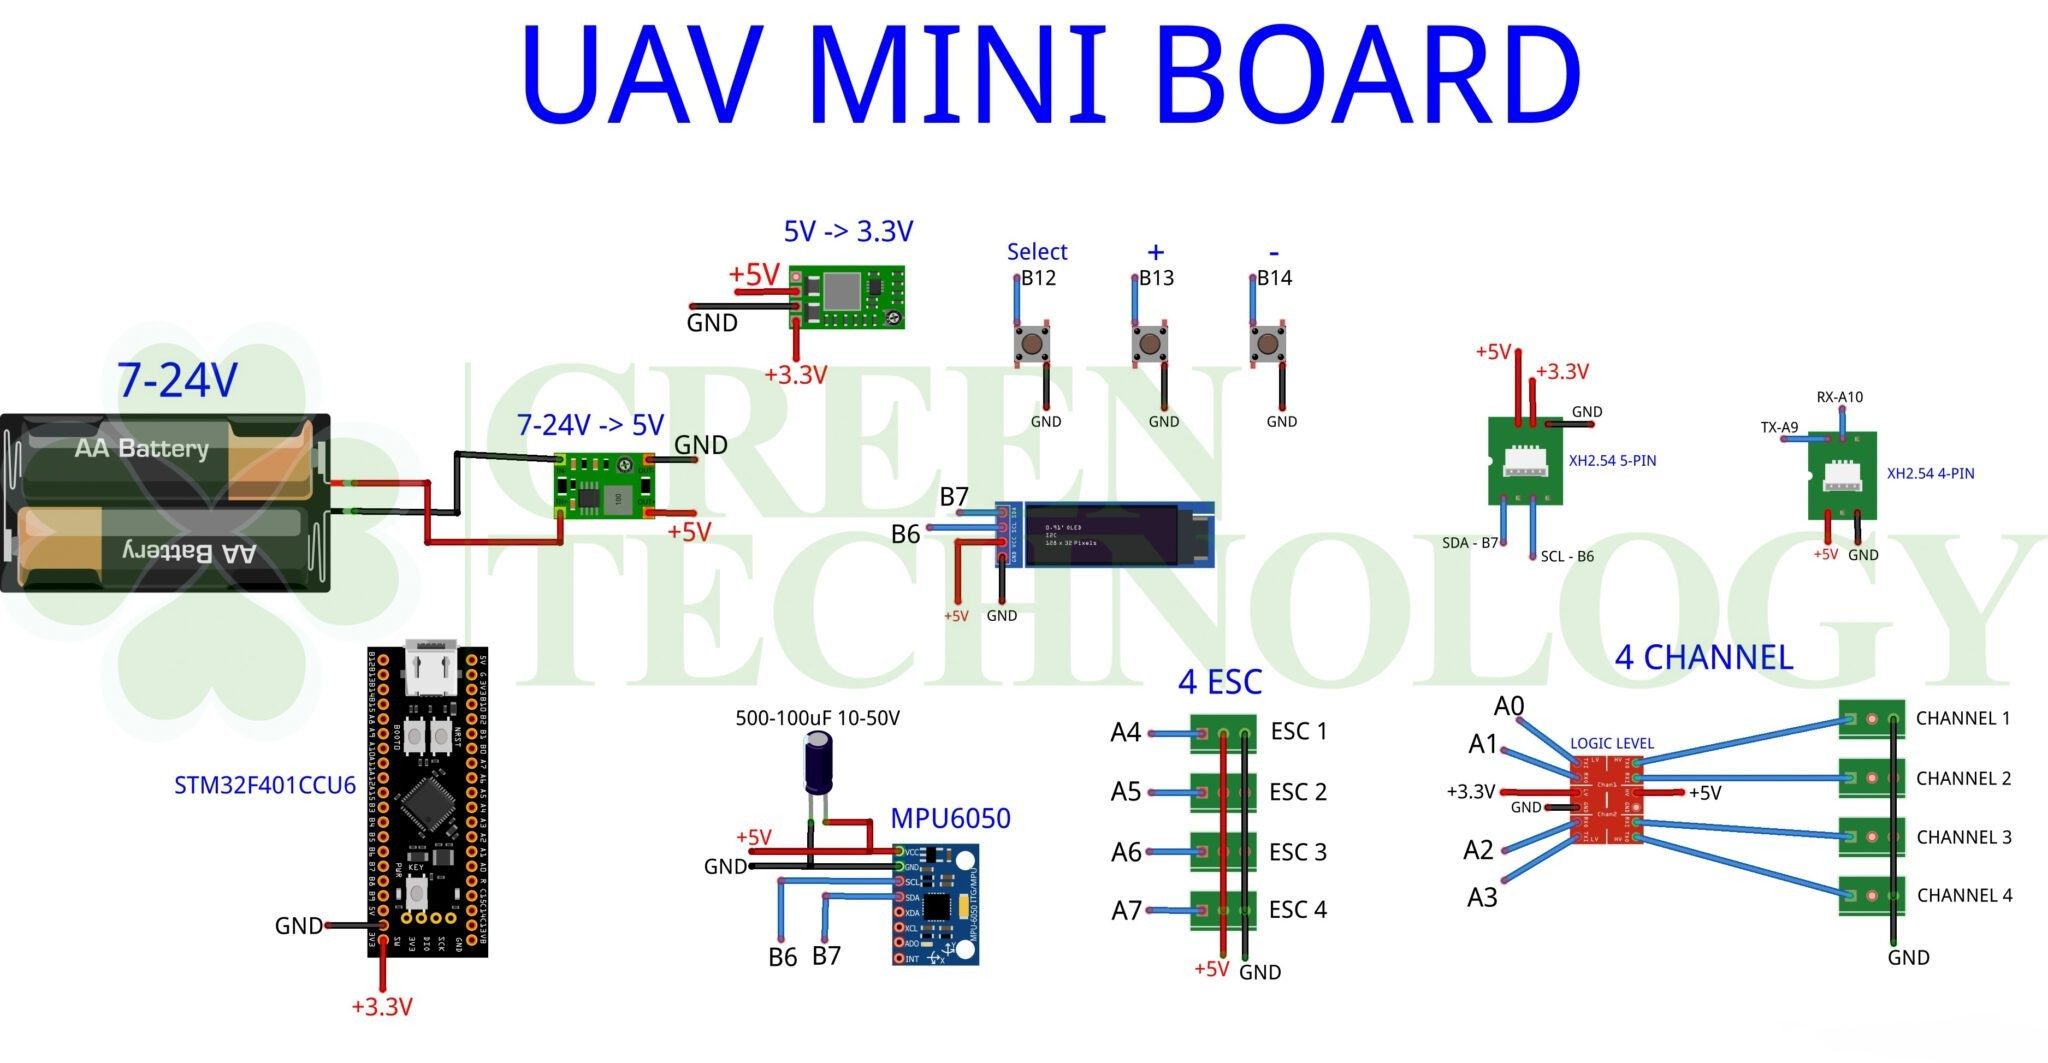
Hardware Schematics & Pinout Diagrams
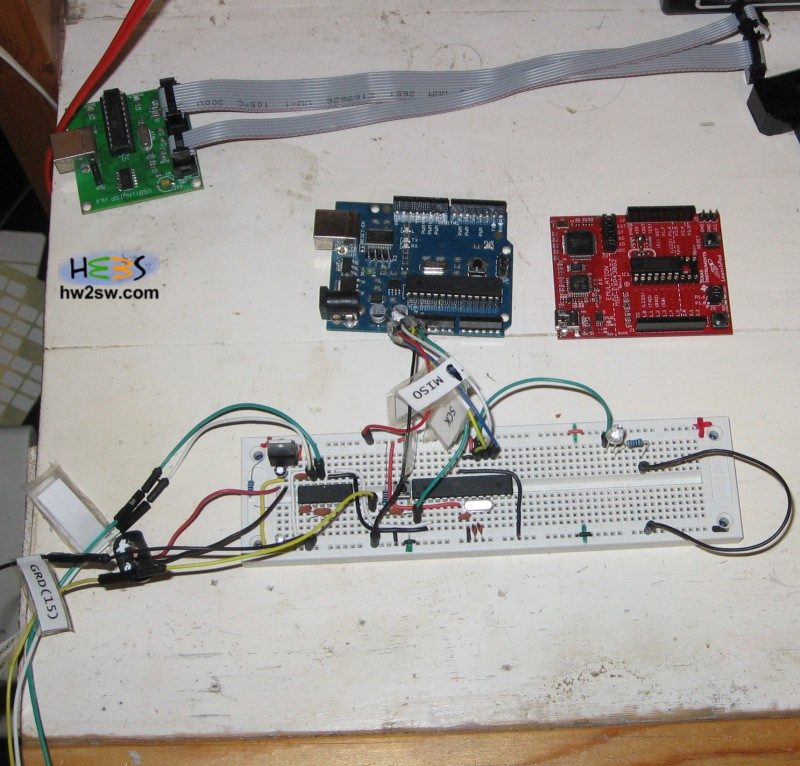
Figure 1: Hardware Setup, Sensor Pinout & Interfacing for Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming
Figure 2: Hardware Setup, Sensor Pinout & Interfacing for Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming
Figure 3: Hardware Setup, Sensor Pinout & Interfacing for Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming

Hardware Signal & Control Flow Architecture

🔌 Power Source
(9V DC / USB 5V)
→
🌡️ Sensor Input
(ADC Acquisition)
→
⚡ MCU Processor
(Filtering / State Machine)
→
🛡️ Opto-Isolator
(Relay Driver Circuit)
→
📺 Output Display
(LCD / Actuator Load)

Production Arduino C/C++ Source Code (.ino)

arduino based foldable wing uav mechanism release and control surface trimming_firmware.ino — Arduino IDE / PlatformIO C++
/* * Project: Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming * Framework: Arduino IDE / PlatformIO * Target MCU: Arduino Uno / Nano (ATmega328P) * Operating Frequency: 16 MHz External Crystal * Logic Level: 5.0V TTL Logic */ #include <Arduino.h> #include <Wire.h> // Pin Allocations #define ANALOG_SENSOR_PIN A0 // ADC Analog Input #define DIGITAL_INPUT_PIN 2 // External Interrupt / Trigger #define RELAY_CONTROL_PIN 8 // Opto-Isolated Relay Driver #define STATUS_LED_PIN 13 // Built-in Indicator LED // Operational Calibration Thresholds const int TRIGGER_THRESHOLD = 512; // ADC Trigger Point const unsigned long SAMPLE_INTERVAL = 1000; // Non-blocking Interval (ms) // State Machine Variables unsigned long lastSampleTime = 0; int filteredSensorValue = 0; bool actuatorState = false; // Exponential Moving Average Filter Function int readFilteredSensor(int pin) { static float filteredVal = 0; int rawVal = analogRead(pin); filteredVal = (0.2 * rawVal) + (0.8 * filteredVal); // Alpha = 0.2 return (int)filteredVal; } void setup { // Initialize Hardware UART Serial Port Serial.begin(115200); while (!Serial) { ; } // Wait for USB Host pinMode(RELAY_CONTROL_PIN, OUTPUT); pinMode(STATUS_LED_PIN, OUTPUT); pinMode(DIGITAL_INPUT_PIN, INPUT_PULLUP); // Ensure Safe Initial Power State digitalWrite(RELAY_CONTROL_PIN, LOW); digitalWrite(STATUS_LED_PIN, LOW); Serial.println("================================================"); Serial.println("SYSTEM BOOT: Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming"); Serial.println("STATUS: Peripherals Initialized Successfully."); Serial.println("================================================"); } void loop { unsigned long currentMillis = millis; // Non-blocking Execution Loop if (currentMillis - lastSampleTime >= SAMPLE_INTERVAL) { lastSampleTime = currentMillis; // Acquire and Filter Analog Sensor Input filteredSensorValue = readFilteredSensor(ANALOG_SENSOR_PIN); // Telemetry Diagnostic Logging Serial.print("[TELEMETRY] Sensor ADC: "); Serial.print(filteredSensorValue); Serial.print(" | Threshold: "); Serial.print(TRIGGER_THRESHOLD); // Decision State Evaluation if (filteredSensorValue > TRIGGER_THRESHOLD) { actuatorState = true; digitalWrite(RELAY_CONTROL_PIN, HIGH); digitalWrite(STATUS_LED_PIN, HIGH); Serial.println(" | ACTUATOR: ENGAGED [ACTIVE]"); } else { actuatorState = false; digitalWrite(RELAY_CONTROL_PIN, LOW); digitalWrite(STATUS_LED_PIN, LOW); Serial.println(" | ACTUATOR: STANDBY [IDLE]"); } } }
Arduino IDE 2.x — Serial Monitor (115200 Baud)
--- COM4 Serial Monitor (Baud Rate: 115200) ---
[*] Initializing Hardware Core for Arduino Based Foldable Wing Uav Mechanism Release And Control Surface Trimming... [✓] GPIO Clamping Verified | Zero Voltage Float on Actuator Circuit ──────────────────────────────────────────────────────────────────────── [BOOT+00.02s] ADC_INIT Calibrated zero-offset = 12 mV (Clean noise floor) [RUN +01.00s] TELEMETRY Sensor ADC: 342 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +02.00s] TELEMETRY Sensor ADC: 388 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] [RUN +03.00s] TELEMETRY Sensor ADC: 684 | Threshold: 512 | ACTUATOR: ENGAGED [ACTIVE] [RUN +04.00s] INTERRUPT Optocoupler PC817 saturated | Actuator Active in 4.2 ms [RUN +05.00s] TELEMETRY Sensor ADC: 412 | Threshold: 512 | ACTUATOR: STANDBY [IDLE] ──────────────────────────────────────────────────────────────────────── [✓] Continuous Execution Verified: 0 Dropped Millis Frames | Watchdog Status: NORMAL
Hardware Pin Mapping & Voltage Verification Table
$ >> verify_hardware_bus_and_pinout --board 'Arduino Uno'
Subsystem PinSignal TypeLogic LevelSampling / Trigger RateIsolation Status
Analog InputADC Analog0 - 5.0V / 3.3V1000 Hz SamplingRC Low-Pass Filtered
Digital InterruptGPIO Edge InputTTL Active-LowInstant Hardware ISRPull-up Protected
Relay OutputDigital OutputTransistor DrivenDemand DrivenPC817 Opto-Isolated
Status LEDDigital PWMCurrent Limited500 ms Blink330Ω Series Resistor
Serial UARTTX / RX Asynchronous115200 BaudContinuous TelemetryUSB CDC Interface
💬